GV

GeezerVison

The World Wide Web, restored to 800 pixels of glory.

Home|About|Gaming cabinet|Archives|How it works|Starter sites

On this site

  • Optimization Engine
  • Docs
  • Blog
  • Rust API
  • Opengen API
  • Chat
  • GitHub
  • Python
  • Additional options
  • C/C++ Bindings
  • Direct interface
  • TCP Sockets
  • ROS2 packages
  • ROS packages

This view

  • Original page
  • New address

GeezerVison is showing alphaville.github.io — Examples | OpEn

Example: Rosenbrock Function Example: Ball and Plate Example: Tanks
Example: Nonlinear Estimation Example: AGV navigation Example: Inverted Pendulum

OpEn+F1TENTH: this complete example on how to use OpEn to build an NMPC controller for autonomous racing cars competitions using the F1TENTH simulator ground vehicle.
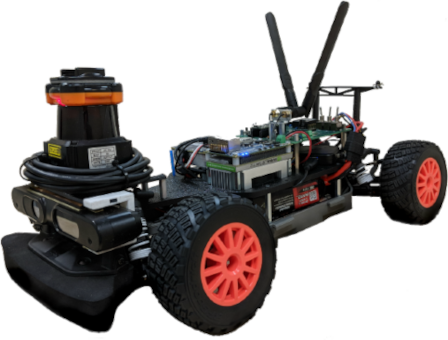
An example of a F1/10 car model

OpEn generates a complete ROS package that can run along with the simulator. To build your own ROS package read the documentation first.

OpEn+ROS: this complete example on how to use OpEn to build an NMPC controller on a Husky ground vehicle.
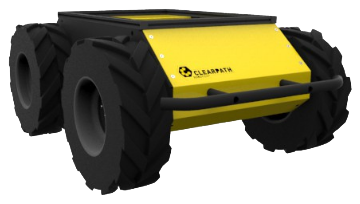
Clearpath Husky unmanned ground vehicle

OpEn generates a complete ROS package that can run on the robot. To build your own ROS package read the documentation first.

You are visitor 01402503 — GeezerVison does not store the pages you look up.
Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required.