GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing arpitrf.github.io — Arpit Bahety 
Arpit Bahety
abahety at utexas dot edu
I am pursuing a Ph.D. in Computer Science at The University of Texas at Austin where I am fortunate to be advised by Prof. Roberto Martín-Martín and am part of the Robot Interactive Intelligence (RobIn) lab. I am passionate about developing general-purpose, deployable robots in the wild. My research focuses on failure-aware and safe robot learning, enabling robots to act reliably in the real world. I did a Research Internship at the Robotics and AI Institute (RAI) in Summer 2025. I previously finished my MS in Computer Science from Columbia University, advised by Prof. Shuran Song, and my undergraduate from the Indian Institute of Information Technology - Allahabad (IIIT-A), advised by Prof. G. C. Nandi. I also love to play tennis, basketball, music and to snowboard. Research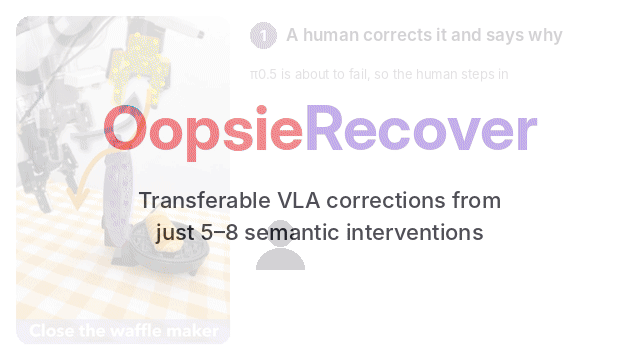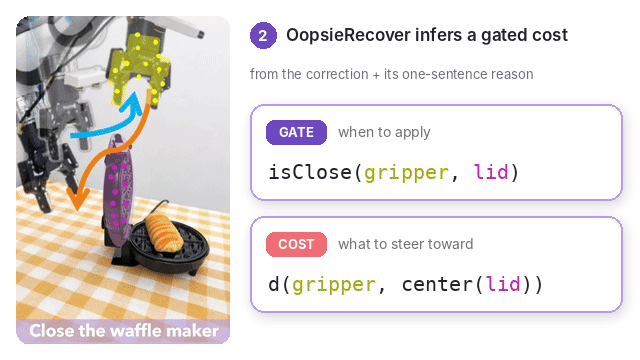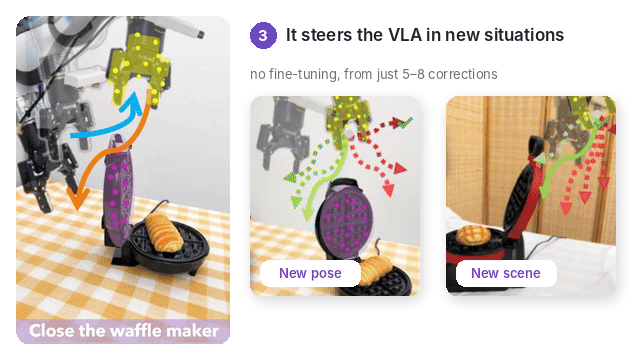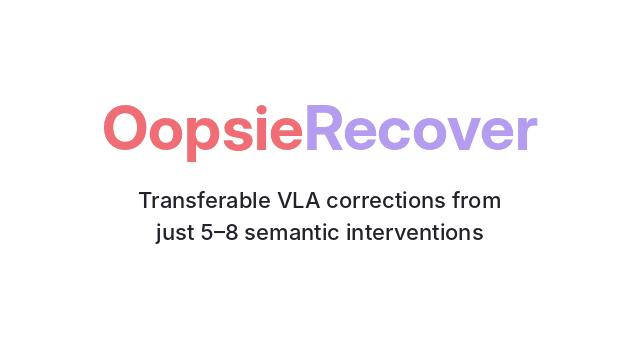 OopsieRecover: Learning Transferable VLA Corrections from Semantic Interventions
Arpit Bahety*,
Skand Peri*,
Sriniket Ambatipudi,
Chen Xu,
Haruki Nishimura,
Masha Itkina,
Roberto Martín-Martín
TL;DR: Enables robots to learn to recover from failures using very few corrections by levaraging semantics.
OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation
Arnav Balaji*,
Arpit Bahety*,
Sriniket Ambatipudi,
Daniel Lam,
Junhong Xu,
Roberto Martín-Martín,
TL;DR: A damage-aware, simulator-agnostic framework and benchmark for evaluating and learning safer policies.  MoMaGen: Generating Demonstrations under Soft and Hard Constraints for Multi-Step Bimanual Mobile Manipulation
Chengshu Li*,
Mengdi Xu*,
Arpit Bahety*,
Hang Yi*,
Yunfan Jiang,
Huang Huang,
Josiah Wong,
Sujay Garlanka,
Cem Gokmen,
Ruohan Zhang,
Weiyu Liu,
Jiajun Wu,
Roberto Martín-Martín,
Fei-Fei Li
TL;DR: An automated data generation method for multi-step bimanual mobile manipulation that satisfies hard constraints (e.g., reachability) while balancing soft constraints (e.g., visibility).
SafeMimic: Towards Safe and Autonomous Human-to-Robot Imitation for Mobile Manipulation
Arpit Bahety,
Arnav Balaji,
Ben Abbatematteo,
Roberto Martín-Martín
TL;DR: A frameowrkd that enables robots to safely and autonomously learn multi-step mobile manipulation tasks from a single human video by segmenting, translating, and adapting the demonstrated actions to their own morphology.
ScrewMimic: Bimanual Imitation from Human Videos with Screw Space Projection
Arpit Bahety,
Priyanka Mandikal,
Ben Abbatematteo,
Roberto Martín-Martín
TL;DR: A method to teach robots bimanual manipulation using human video demonstrations, by leveraging a novel, psychology- and biomechanics-inspired action space to learn effectively from failures in the real world.
BaRiFlex: A Robotic Gripper with Versatility and Collision Robustness for Robot Learning
Gu-Cheol Jeong,
Arpit Bahety,
Gabriel Pedraza,
Ashish D. Deshpande,
Roberto Martín-Martín
TL;DR: A novel hybrid rigid–flexible robotic gripper that enhances versatility (e.g. compliant grasping and precise pinching) and collision-tolerance, enabling safer and robust robot learning in everyday environments.
REFLECT: Summarizing Robot Experiences for FaiLure Explanation and CorrecTion
Zeyi Liu*,
Arpit Bahety*,
Shuran Song
TL;DR: A framework that leverages LLM for robot failure explanation and correction, based on a hierarchical summary of robot past experiences generated from multisensory data.
Bag All You Need: Learning a Generalizable Bagging Strategy for Heterogeneous Objects
Arpit Bahety*,
Shreeya Jain*,
Huy Ha,
Nathalie Hager,
Benjamin Burchfiel,
Eric Cousineau,
Siyuan Feng,
Shuran Song
TL;DR: A robotic system that learns to pack rigid and deformable objects into deformable bags using two learned policies for object rearrangement and bi-manual bag lifting.
Automatic quantification and visualization of street trees
Arpit Bahety,
Rohit Saluja,
Ravi Kiran Sarvadevabhatla,
Anbumani Subramanian,
C. V. Jawahar
 An approach to computational creation of insight problems using CreaCogs principles
Arpit Bahety, Ana-Maria Olteteanu
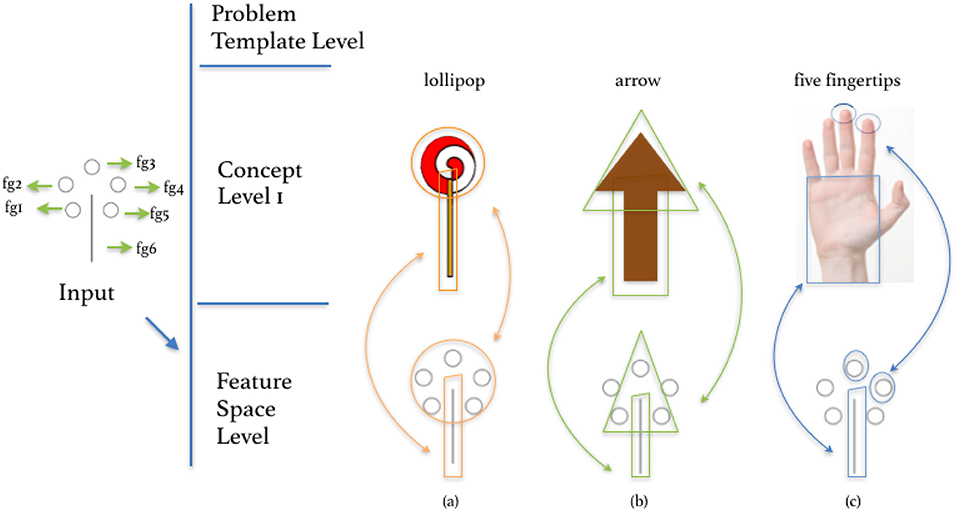 Towards a Multi-level Exploration of Human and Computational Re-representation in Unified Cognitive Frameworks
Ana-Maria Olteteanu, Mikkel Schöttner, Arpit Bahety
* indicates equal contribution Service
|
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |