GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing lauramsmith.github.io — Laura Smith Laura Smith
Hello! I'm a Research Scientist at Physical Intelligence,
working on bringing generalist robots to the real world. I recently received my PhD from UC Berkeley,
where I was fortunate to be able to work on real-world RL for robots in the wild with Sergey Levine.


NewScientist article "Robot dog learns to walk on tough terrain in just 20 minutes"
Berkeley Engineering article "Step by Step"
TechXplore article "A technique that allows legged robots to continuously learn from their environment"
TechXplore article "AVID: a framework to enhance imitation learning in robots"
The following are most representative of my personal work.
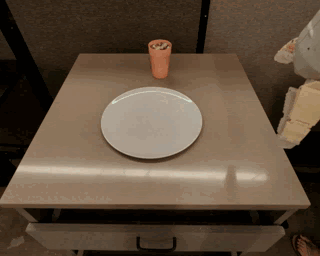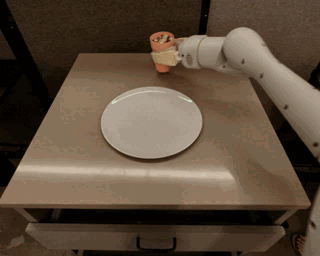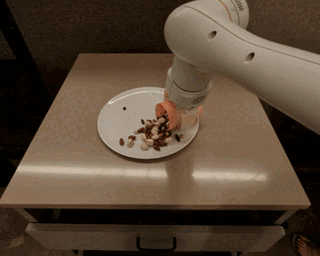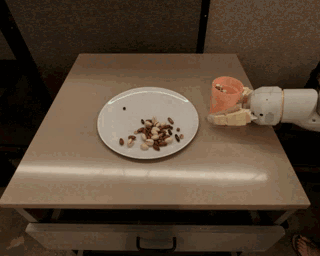
STEER: Flexible Robotic Manipulation via Dense Language Grounding
Laura Smith, Alex Irpan, Montserrat Gonzalez Arenas, Sean Kirmani, Dmitry Kalashnikov, Dhruv Shah, Ted Xiao Grow Your Limits: Continuous Improvement with Real-World RL for Robotic Locomotion
Laura Smith*, Yunhao Cao*, Sergey Levine
Learning and Adapting Agile Locomotion Skills by Transferring Experience
Laura Smith, J. Chase Kew, Tianyu Li, Linda Luu, Xue Bin Peng, Sehoon Ha, Jie Tan, Sergey Levine RLPD: Efficient Online Reinforcement Learning with Offline Data
Philip J. Ball*, Laura Smith*, Ilya Kostrikov*, Sergey Levine
A Walk in the Park: Learning to Walk in 20 Minutes With Model-Free Reinforcement Learning
Laura Smith*, Ilya Kostrikov*, Sergey Levine 
Legged Robots that Keep on Learning: Fine-Tuning Locomotion Policies in the Real World
Laura Smith, J. Chase Kew, Xue Bin Peng, Sehoon Ha, Jie Tan, Sergey Levine 
PEBBLE: Feedback-Efficient Interactive Reinforcement Learning via Relabeling Experience and Unsupervised Pre-Training
Kimin Lee*, Laura Smith*, Pieter Abbeel 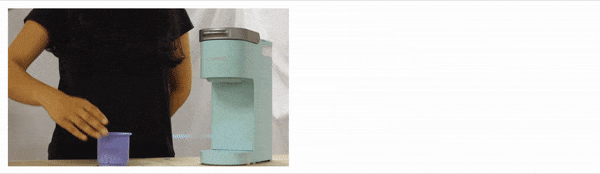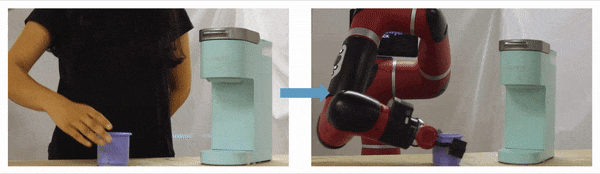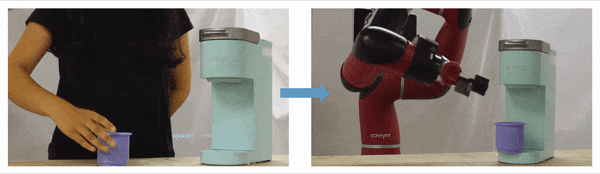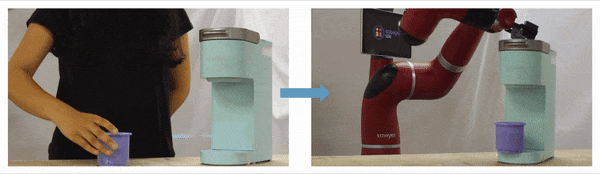
AVID: Learning Multi-Stage Tasks via Pixel-Level Translation of Human Videos
Laura Smith, Nikita Dhawan, Marvin Zhang, Pieter Abbeel, Sergey Levine 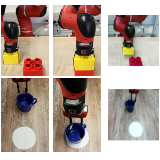
SOLAR: Deep Structured Latent Representations for Model-Based Reinforcement Learning
Marvin Zhang*, Sharad Vikram*, Laura Smith, Pieter Abbeel, Matthew Johnson, Sergey Levine 2022 Co-Organizer, CoRL Workshop on Learning to Adapt and Improve in the Real World2022+ Reviewer, CoRL, RA-L, ICRA, NeurIPS, IROS, ICLR.
Board Member, UC Berkeley Women in EECS
2020+ Co-Organizer, Berkeley AI Research Mentoring Program2018-2020 Co-Organizer, Robot Learning Lab Outreach2018 Guest Lecture at UC Berkeley CS10: The Beauty and Joy of Computing (video) |
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |
