GeezerVisonThe World Wide Web, restored to 800 pixels of glory. | ||||||||||||||||||||
| Home|About|Gaming cabinet|Archives|How it works|Starter sites | ||||||||||||||||||||
GeezerVison is showing leap-workshop.github.io — LEAP Workshop — CoRL 2026 
4th Workshop on
Learning Effective Abstractions for Planning (LEAP)
CoRL 2026 · Nov 12, 2026 · Austin, TX, USA
Email: [email protected] OverviewComplex long-horizon and sparse reward robotics tasks are challenging for scaling end-to-end learning methods. By contrast, planning approaches have shown great potential to handle such complex tasks effectively. One of the major criticisms of planning-based approaches has been the lack of availability of accurate world models (aka abstractions) to utilize. There has been a renewed interest in using learning-based approaches to learn symbolic representations that support planning. However, this research is often fragmented into disjoint sub-communities such as task and motion planning, reinforcement learning (hierarchical, model-based), planning with formal logic, planning with natural language (language models), and neuro-symbolic AI. As in previous years, LEAP will bring together researchers from disparate subfields to discuss how we can combine learning, planning, and abstractions to solve increasingly complex long-horizon and sparse-reward robotics tasks. As in prior editions, the workshop continues to engage with the foundational questions that have defined LEAP since its inception:
Focal Themes of LEAP 2026While the questions above ground the workshop, our key attention this year is deliberately focused on two specific, concrete, and timely challenges in learning abstractions for planning. 💻 Theme #1: Code as AbstractionsPrograms and code offer a uniquely powerful substrate for abstraction in robot planning. They are compositional, verifiable, reusable, and directly executable, and they interface naturally with modern foundation models that can read, write, and edit code. We are eager to explore and discuss when and how code is the right abstraction for robot decision-making, as well as to identify its limitations:
🌐 Theme #2: World Models as AbstractionsLearned world models promise abstractions of environment dynamics that can be searched, simulated, and planned over. We want to examine what makes a world model a good abstraction for planning (rather than merely for prediction), and how planning can be performed in, on top of, or adjacent to such models:
Areas of InterestWe solicit papers on the following topics:
Submission GuidelinesWe solicit workshop paper submissions relevant to the above call of the following types:
Please format submissions in CoRL or IEEE conference (ICRA or IROS) styles. Submissions do not need to be anonymized. To authors submitting papers rejected from other conferences: please ensure that comments given by the reviewers are addressed prior to submission. Note: Please feel free to submit work under review or accepted for presentation at other workshops and/or conferences as we will not require copyright transfer.
Note: The CoRL workshop organizers have requested that we do not accept submissions
that are already accepted at the main CoRL conference. We kindly ask authors to respect this policy when
submitting to our workshop.
Important Dates
Schedule
Invited Speakers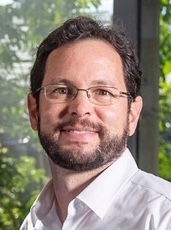
Fabio RamosNvidia & U. Sydney · USA/AUS
Talk Title
“Generalizing Task and Motion Planning for Agentic Systems”
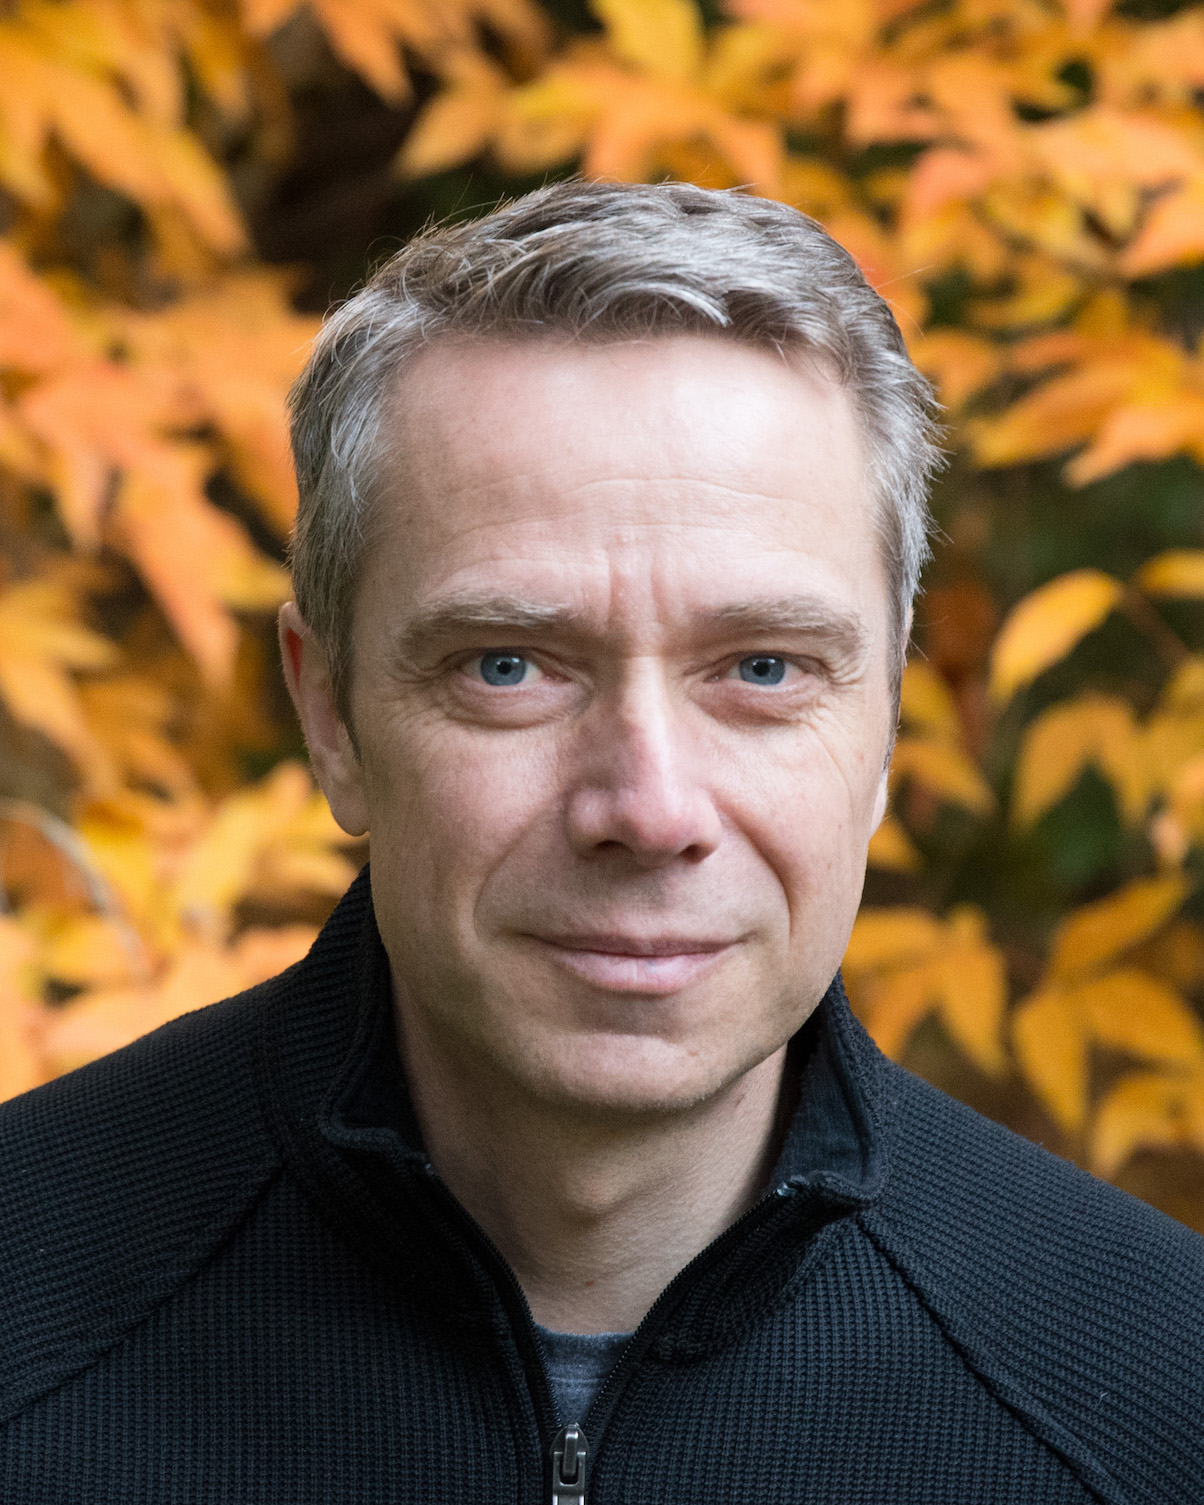
Dieter FoxAi2 & UW · USA
Talk Title
“ToyBlocks: Enabling Controlled Experiments on Robot Foundation Models”
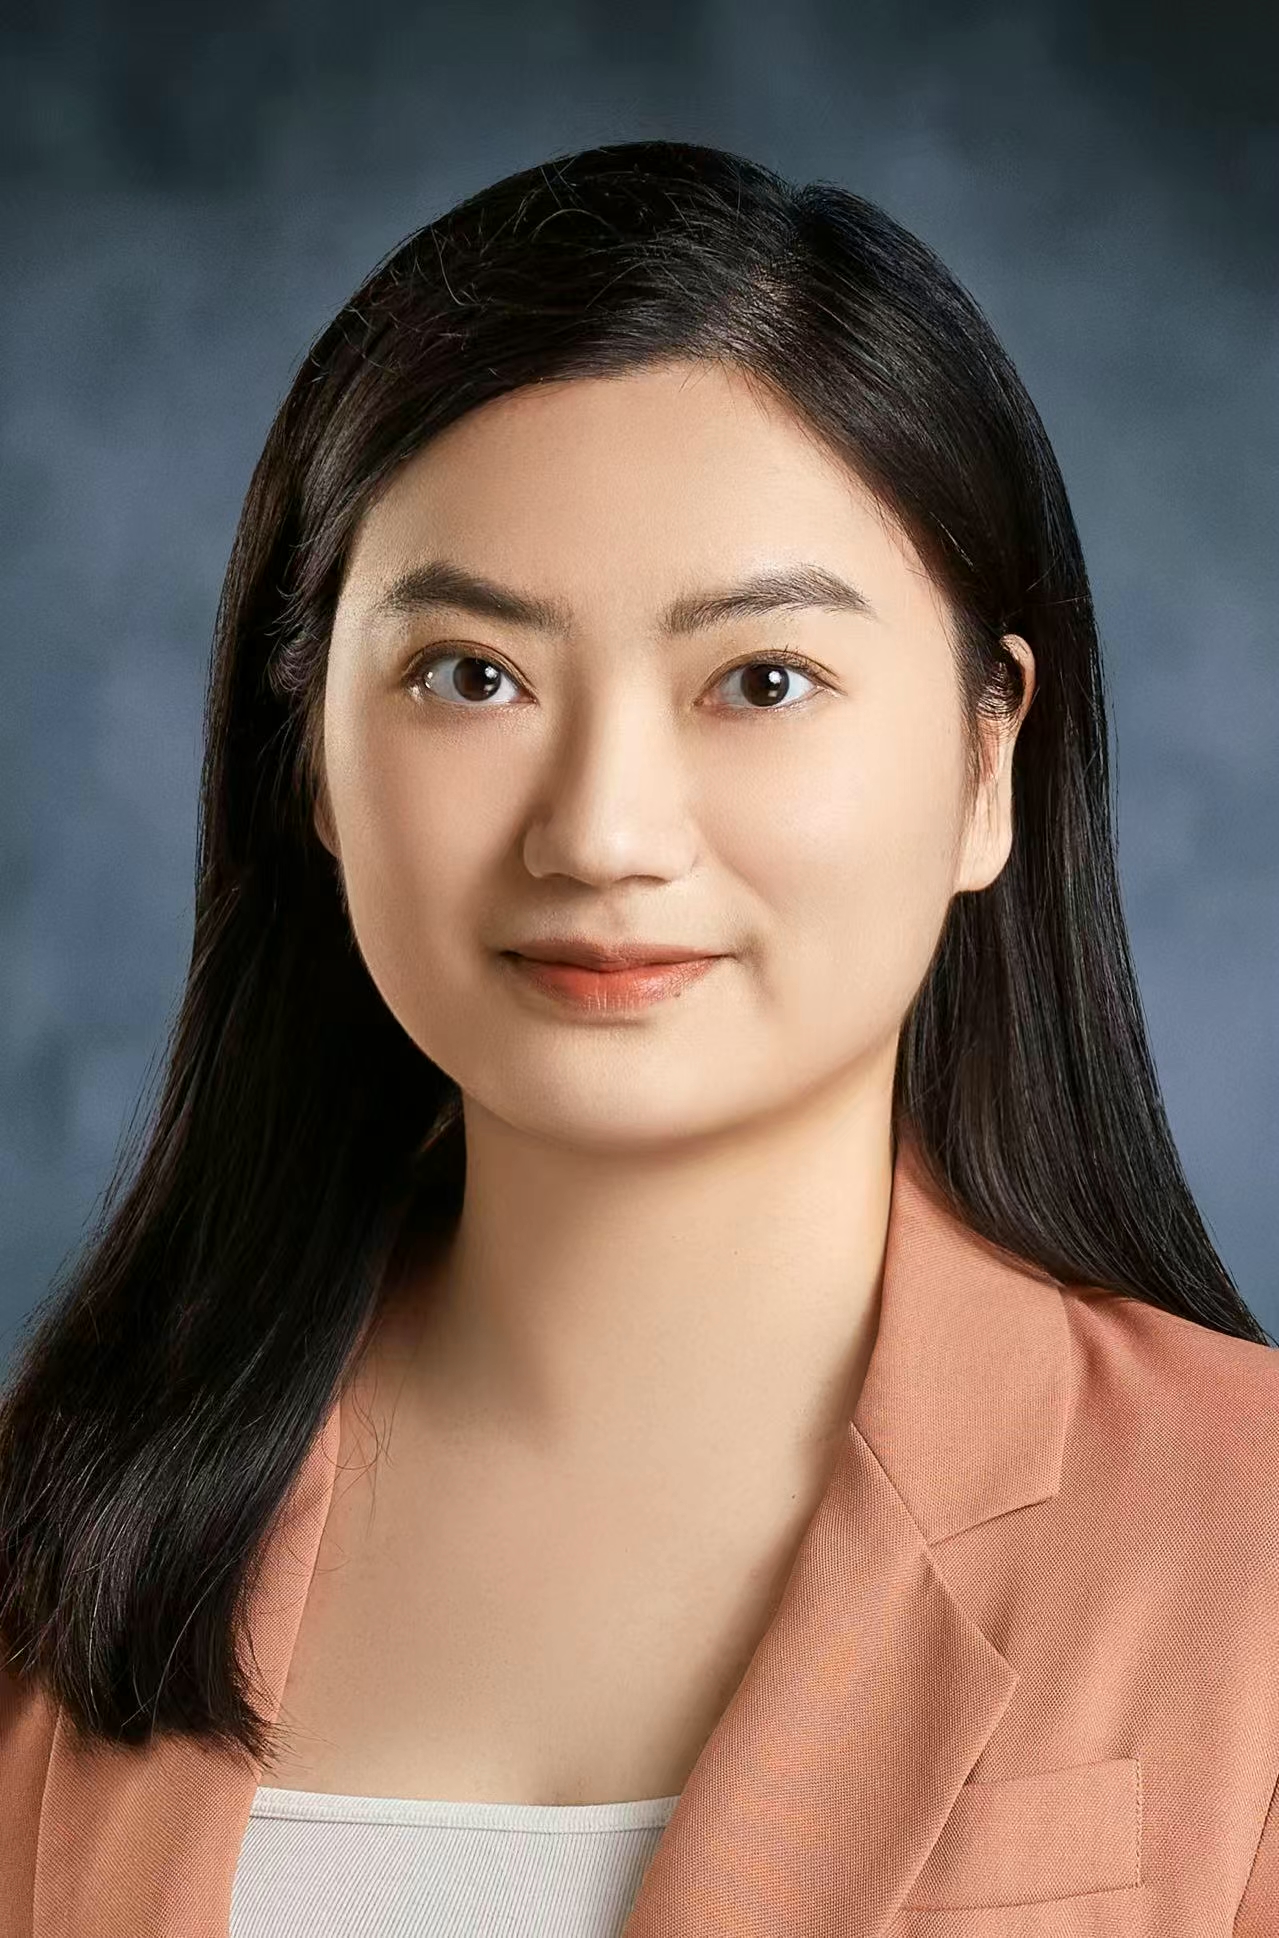
Panpan CaiShanghai Jiao Tong U. · China
Talk Title
“Learning Abstractions for Robot Planning in a Big World”
Organizing Committees | ||||||||||||||||||||
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |