GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing microsoft.github.io — Code Structure - AirSim Code Structure#AirLib#Majority of the code is located in AirLib. This is a self-contained library that you should be able to compile with any C++11 compiler. AirLib consists of the following components:
Apart from these, all common utilities are defined in AirSim supports different firmwares for Multirotor such as its own SimpleFlight, PX4 and ArduPilot, files for communicating with each firmware are placed in their respective subfolders in The vehicle-specific APIs are defined in the Unreal/Plugins/AirSim#This is the only portion of project which is dependent on Unreal engine. We have kept it isolated so we can implement simulator for other platforms as well, as has been done for Unity. The Unreal code takes advantage of its UObject based classes including Blueprints. The
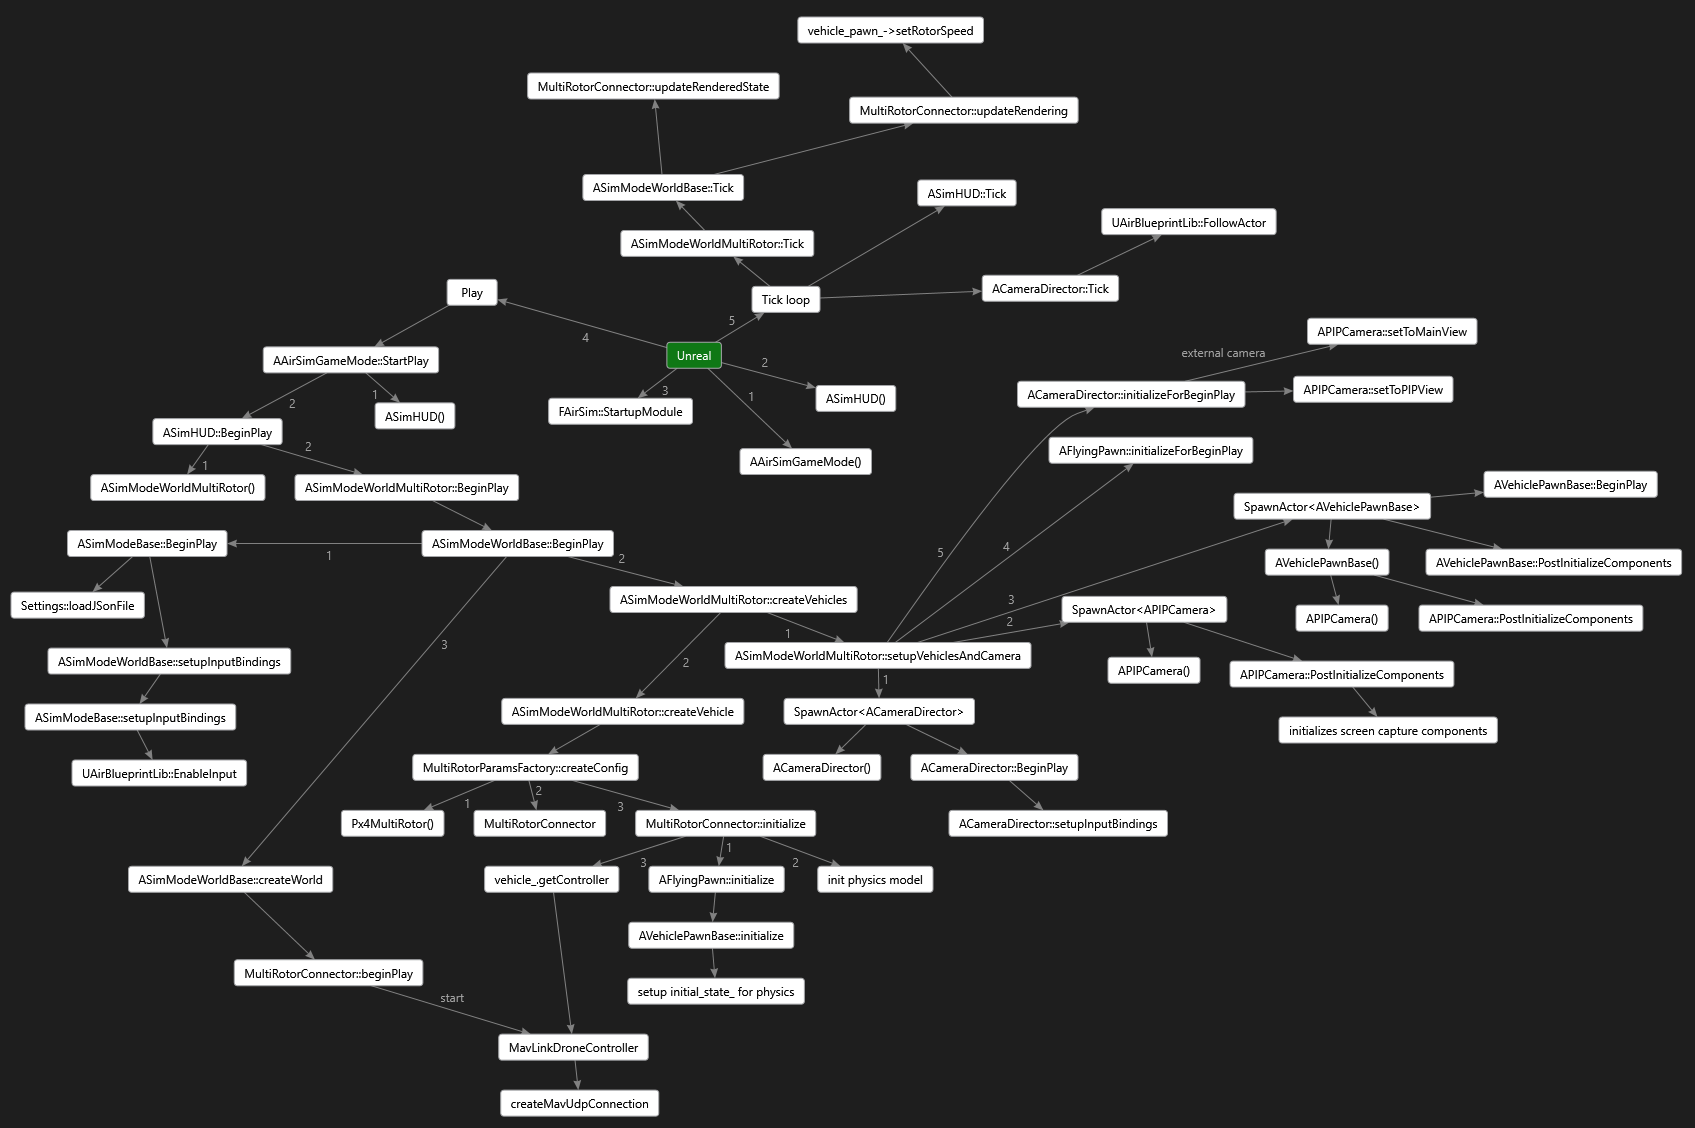
Apart from these, MavLinkCom#This is the library developed by our own team member Chris Lovett that provides C++ classes to talk to the MavLink devices. This library is stand alone and can be used in any project. See MavLinkCom for more info. Sample Programs#We have created a few sample programs to demonstrate how to use the API. See HelloDrone and DroneShell. DroneShell demonstrates how to connect to the simulator using UDP. The simulator is running a server (similar to DroneServer). PythonClient#PythonClient contains Python API wrapper files and sample programs demonstrating their uses. Contributing#Unreal Framework#The following picture illustrates how AirSim is loaded and invoked by the Unreal Game Engine:
|
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |