GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing object-adaptation.github.io — Learning to Design 3D Printable Adaptations on Everyday Objects for Robot Manipulation Learning to Design 3D Printable Adaptations on Everyday Objects for Robot Manipulation
Stanford University
ICRA 2024
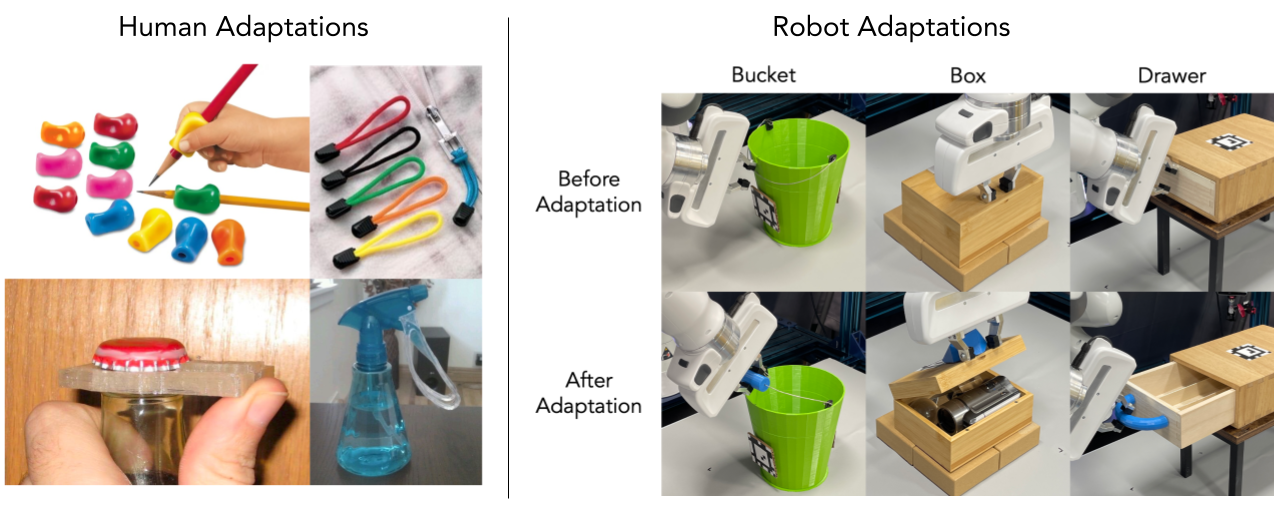 Inspired by human examples of adaptation, we focus on adapting objects for robots to use in an automated way via learning.AbstractAdvancements in robot learning for object manipulation have shown promising results, yet certain everyday objects remain challenging for robots to effectively interact with. This discrepancy arises from the fact that human-designed objects are optimized for human use rather than robot manipulation. To address this gap, we propose a framework to automatically design 3D printable adaptations that can be attached to hard-to-use objects, thus improving "robot ergonomics". Our learning-based framework formulates the adaptation design and control as a dual Markov decision process and is able to improve robot-object interactions for various robot end effectors and objects. We further validate our designs in the real world with a Franka Panda robot. Framework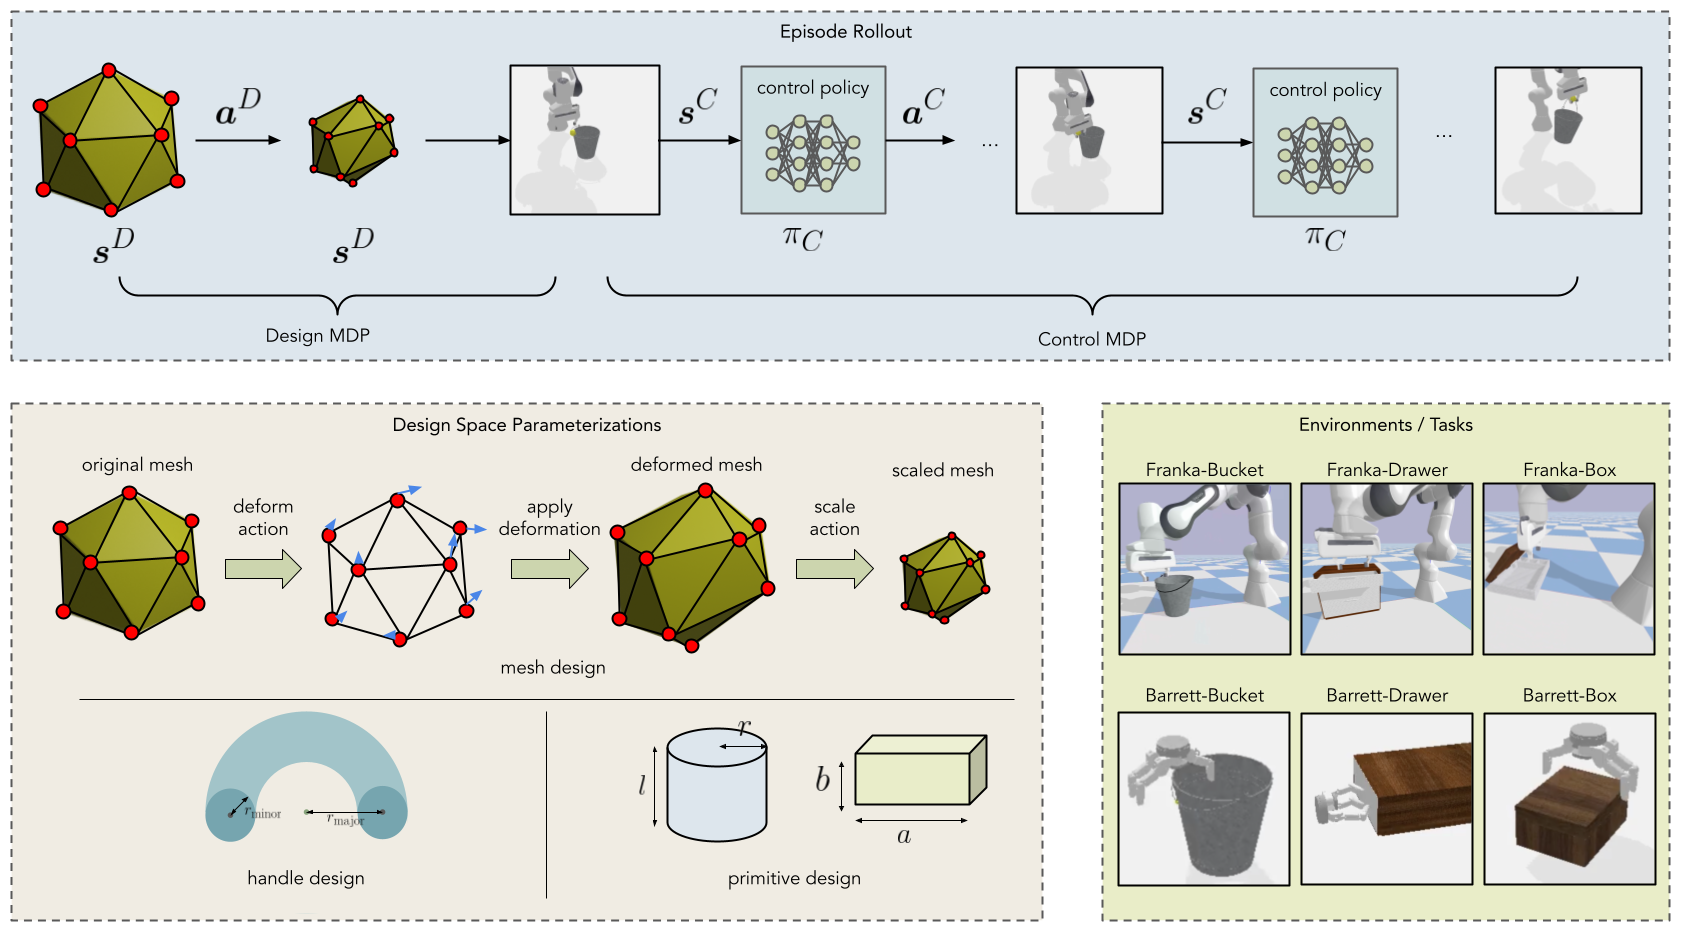
Overview of our framework. We formulate the design and control as a dual Markov decision process and adopt a reinforcement learning framework to jointly optimize them.Comparison of Design Strategies
Learning curves for varying design strategies. Random designs outperform trying to use the original object with no design, but the learned designs are the best. Shaded regions indicate standard error across a minimum of three random seeds.Supplementary VideoBibTeX |
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |