GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing si-lynnn.github.io — Zilin Si 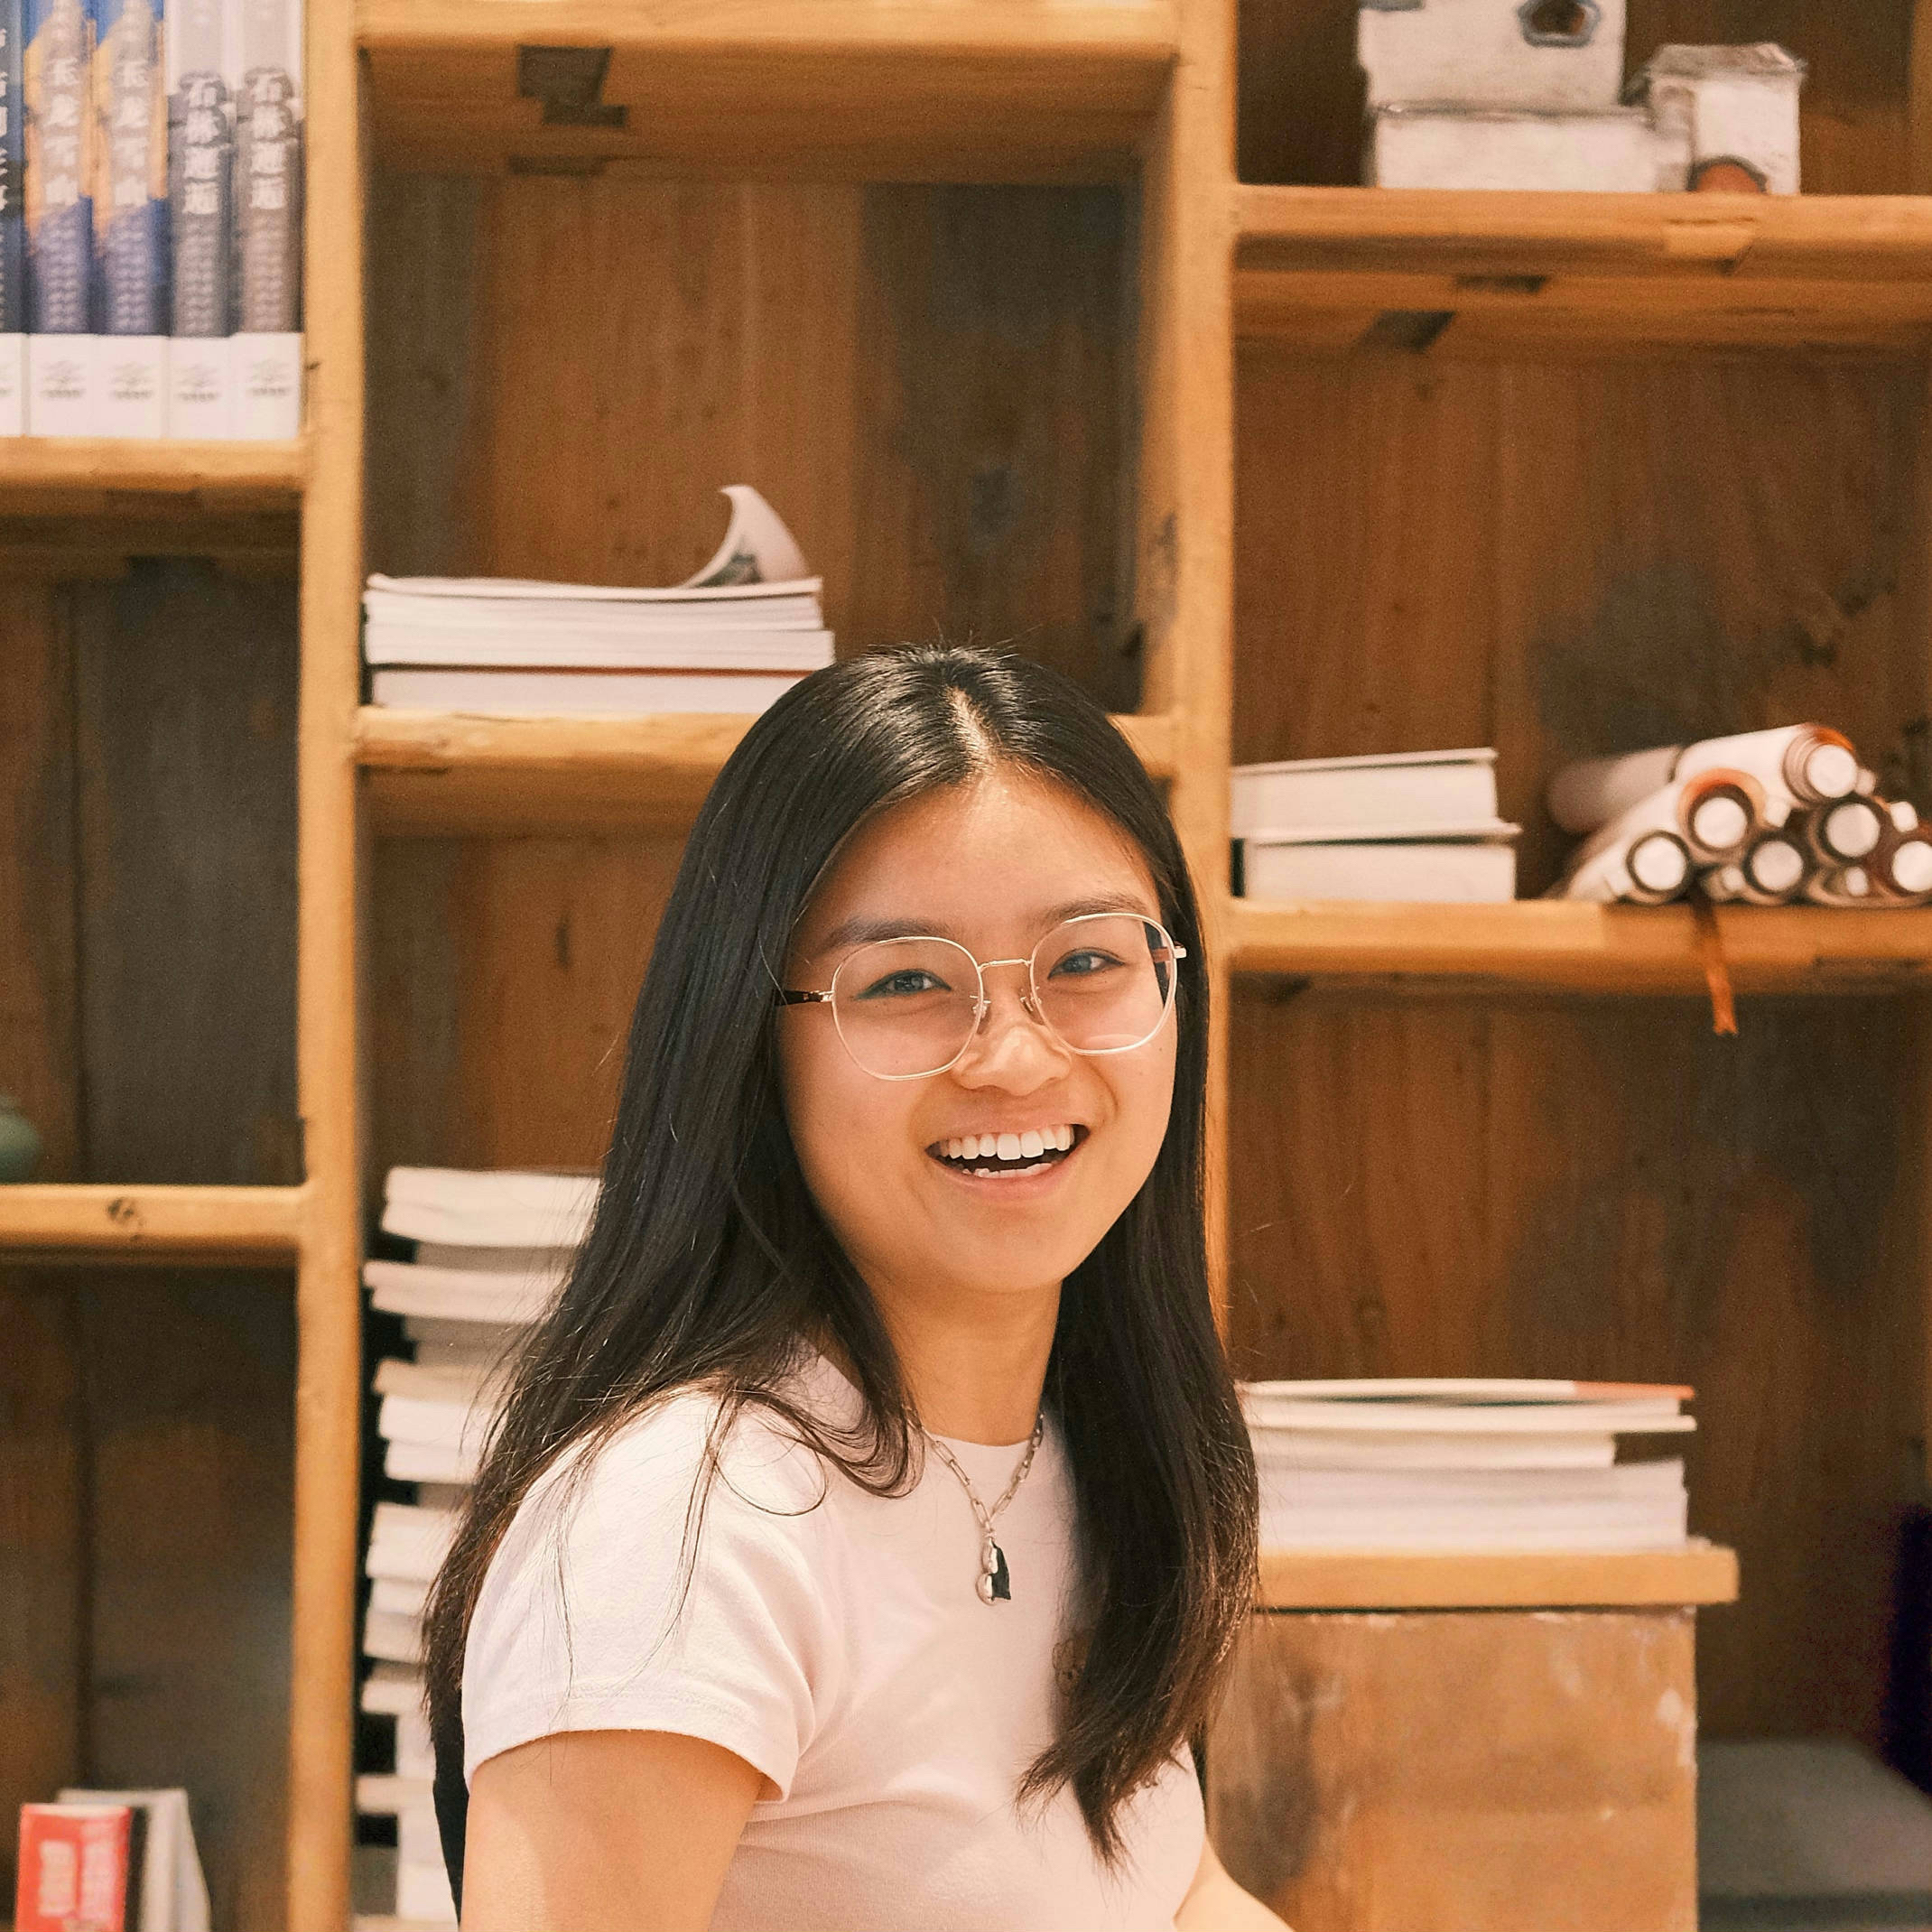
Zilin Si
Research Scientist,
Google DeepMind
zsi[at]andrew[dot]cmu[dot]edu
Hello there! I am Zilin, a researcher at Google DeepMind. I completed my PhD at the Robotics Institute, Carnegie Mellon University, where I was co-advised by Prof. Zeynep Temel and Prof. Oliver Kroemer. During my PhD, I worked on developing robotic hands and learning systems for dexterous manipulation. I was also passionate about designing and deploying tactile sensors to advance manipulation. Previously, I interned with Google DeepMind in London as a student researcher. Before that, I spent a summer as a research intern working with Dr. Chuang Gan at MIT-IBM Watson AI Lab. I earned my Master’s degree in Robotics from Carnegie Mellon University, where I had a wonderful time working in the RoboTouch Lab (now affiliated with UIUC), advised by Prof. Wenzhen Yuan. My research there focused on example-based tactile simulation and its sim-to-real applications. I completed my Bachelor’s degree in Computer Science at ShanghaiTech University. As an undergraduate researcher, I worked with Prof. Laurent Kneip in Mobile Perception Lab; I also interned with Robot Perception Lab as part of the RISS program, advised by Prof. Michael Kaess. Outside of work, I love dancing ballet, rock climbing, and spending time with my cat, Bobo. Interests
Academia
Carnegie Mellon University
2022
- 2026
Ph.D. Robotics
RI Presidential Fellowship (2023-2024)
Carnegie Mellon University
2020
- 2022
M.S. Robotics
ShanghaiTech University
2016
- 2020
B.Eng. Computer Science
Graduated with honor!
Publications
Learning with Object-centric Representations of Tactile Interactive Perception for Robot Manipulation,
2026,
The Conference on Robot Learning (CoRL)
Xinyi Yang*
,
Zilin Si*
,
Zhuowei Xu
,
Zeynep Temel
,
Oliver Kroemer
Inference-time Policy Steering via Vision and Touch,
2026,
The Conference on Robot Learning (CoRL)
Yilin Wu
,
Zilin Si
,
Zeynep Temel
,
Oliver Kroemer
,
Andrea Bajcsy
TacO: Benchmarking Tactile Sensors for Object Manipulation,
2026,
Anya Zorin
,
Zilin Si
,
Myungsun Park
,
Junsung Park
,
Alexiy Buynitsky
,
Sachin Bhadang
,
Taejun Park
,
Sohee John Yoon
,
Yong-Lae Park
,
Oliver Kroemer
,
Zeynep Temel
,
Michael T. Tolley
,
Sha Yi
,
Xiaolong Wang
A multi-modal tactile fingertip design for robotic hands to enhance dexterous manipulation,
2026,
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Zhuowei Xu*
,
Zilin Si*
,
Oliver Kroemer
,
Zeynep Temel
ExoStart: Efficient learning for dexterous manipulation with sensorized exoskeleton demonstrations,
2025,
Z Si*
,
JE Chen*
,
ME Karagozler*
,
A Bronars
,
J Hutchinson
,
T Lampe
,
N Gileadi
,
T Howell
,
S Saliceti
,
L Barczyk
,
IO Correa
,
T Erez
,
M Shridhar
,
MF Martins
,
K Bousmalis
,
N Heess
,
F Nori
,
M Bauza
Tilde: Teleoperation for Dexterous In-Hand Manipulation Learning with a DeltaHand,
2024,
Robotics: Science and Systems (RSS)
Zilin Si*
,
Kevin Zhang*
,
Zeynep Temel
,
Oliver Kroemer
DIFFTACTILE: A Physics-based Differentiable Tactile Simulator for Contact-rich Robotic Manipulation,
2024,
The Twelfth International Conference on Learning Representations (ICLR)
Zilin Si*
,
Gu Zhang*
,
Qingwei Ben*
,
Branden Romero
,
Zhou Xian
,
Chao Liu
,
Chuang Gan
DELTAHANDS: A Synergistic Dexterous Hand Framework Based on Delta Robots,
2023,
IEEE Robotics and Automation Letters (RA-L)
Zilin Si
,
Kevin Zhang
,
Oliver Kroemer
,
F. Zeynep Temel
RobotSweater: Scalable, Generalizable, and Customizable Machine-Knitted Tactile Skins for Robots,
2023,
IEEE International Conference on Robotics and Automation (ICRA)
Zilin Si*
,
Tianhong Catherine Yu*
,
Katrene Morozov
,
James McCann
,
Wenzhen Yuan
MidasTouch: Monte-Carlo inference over distributions across sliding,
2022,
The Conference on Robot Learning (CoRL)
Sudharshan Suresh
,
Zilin Si
,
Stuart Anderson
,
Michael Kaess
,
Mustafa Mukadam
Grasp Stability Prediction with Sim-to-Real Transfer from Tactile Sensing,
2022,
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Zilin Si
,
Zirui Zhu
,
Arpit Agarwal
,
Stuart Anderson
,
Wenzhen Yuan
ObjectFolder 2.0: A Multisensory Object Dataset for Sim2Real Transfer,
2022,
Conference on Computer Vision and Pattern Recognition (CVPR)
Ruohan Gao*
,
Zilin Si*
,
Yen-Yu Chang*
,
Samuel Clarke
,
Jeannette Bohg
,
Li Fei-Fei
,
Wenzhen Yuan
,
Jiajun Wu
Efficient shape mapping through dense touch and vision,
2022,
IEEE International Conference on Robotics and Automation (ICRA)
Sudharshan Suresh*
,
Zilin Si*
,
Joshua G. Mangelson
,
Wenzhen Yuan
,
Michael Kaess
Taxim: An Example-based Simulation Model for GelSight Tactile Sensors,
2022,
IEEE Robotics and Automation Letters (RA-L) with ICRA
Zilin Si
,
Wenzhen Yuan
Improving Grasp Stability with Rotation Measurement from Tactile Sensing,
2021,
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Raj Kolamuri*
,
Zilin Si*
,
Yufan Zhang
,
Arpit Agarwal
,
Wenzhen Yuan
Maximal Information Propagation with Budgets,
2020,
European Conference on Artificial Intelligence (ECAI)
Haomin Shi
,
Yao Zhang
,
Zilin Si
,
Letong Wang
,
Dengji Zhao
Degeneracy Detection for RGB-D Odometry,
2019,
Robotics Institute Summer Scholars Working Papers Journal
Zilin Si
,
Ming Hsiao
,
Michael Kaess
|
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |