GV

GeezerVison

The World Wide Web, restored to 800 pixels of glory.

Home|About|Gaming cabinet|Archives|How it works|Starter sites

On this site

  • Highlights
  • Impacts
  • Publications
  • Thesis
  • CV / Bio
  • About me
  • Jenelia Research Campus
  • see website ↗
  • CoRL 2024, Munich
  • watch recording ↗
  • IIT Kharagpur
  • see post ↗
  • Next-Gen Robot Learning Symposium, TU Darmstadt
  • Whole-Body Control & Motion Workshop (WCBM)

This view

  • Original page
  • New address

GeezerVison is showing vikashplus.github.io — Vikash Kumar — Embodied AI & Robotics

Vikash Kumar Twitter YouTube GitHub Google Scholar

  • Highlights
  • Impacts
  • Publications
  • Thesis
  • CV / Bio
  • About me
↗ Project Page

Embodied AI  ·  Machine Learning  · Dexterous Robotics

Building Artificial Beings
Indistinguishable from Humans

Co-Foudner, CEO Myolab.ai ↗  ·  Adjunct Professor, CMU Robotics Institute  ·  Previously Sr. Research Scientist at FAIR–Meta AI, Google Brain, OpenAI

CoRL '24
Early Career Keynote
MuJoCo, TorchRL
Founding Member
MyoSuite, Robohive
Lead Creator
ICRA '16, '24
Best Paper Award
NYT · Wired · IEEE
Media Coverage
⌄

Recent Highlights

  • Chair Co-Organizer, Simulated Bodies Conference at Jenelia Research Campus — see website ↗
  • Keynote Honored with Early Career Keynote at CoRL 2024, Munich — watch recording ↗
  • Award Young Alumni Achiever's Award from IIT Kharagpur — see post ↗
  • Talk Invited talk at Next-Gen Robot Learning Symposium, TU Darmstadt
  • Talk Invited talk at Whole-Body Control & Motion Workshop (WCBM)
Research Vision

My research focuses on understanding the fundamentals of embodied movement across biological, digital, and electromechanical systems. I am interested in building artificial beings—both digital and physical—that are indistinguishable from humans in their appearance, spatial reasoning, and behavioral intelligence.

I leverage tools from Machine Learning, Biomechanics, Robotics, and Optimal Control to design sample-efficient algorithms that scale to deliver embodied abilities surpassing human-level dexterity and agility. I strongly believe it's possible to realize artificial agents indistinguishable from humans in our lifetime.

Video Highlights (see publications ↗ for full list)


Human-Embodied Intelligence

MyoSuite
▶

MyoSuite: Contact-Rich Musculoskeletal Motor Control

MyoDex
▶

MyoDex: Generalizable Representations for Dexterous Physiological Manipulation

SAR
▶

SAR: Generalization of Dexterity via Synergistic Action Representation

MyoChallenge 2022
▶

MyoChallenge 2022: Contact-Rich Manipulation via Musculoskeletal Hand

Dexterous Manipulation

ALOHA
▶

Fine-Grained Bimanual Manipulation with Low-Cost Hardware

Visual Dexterity
▶

Visual Dexterity: In-Hand Manipulation from Depth

AVAIL
▶

Dexterous Manipulation from Images: Autonomous Real-World RL

MTRF
▶

Reset-Free Reinforcement Learning via Multi-Task Learning

PDDM
▶

Planning with Deep Dynamics Models (PDDM)

Dexterous Manipulation via Optimal Control
▶

Optimal Control with Learned Local Models: Dexterous Manipulation

Foundation Models for Robot Learning

R3M
▶

R3M: A Universal Visual Representation for Robot Manipulation

LIV
▶

LIV: Language-Image Representations & Rewards for Robotic Control

GenAug
▶

GenAug: Retargeting Behaviors via Generative Augmentation

VIP
▶

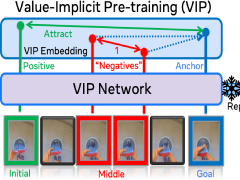
VIP: Towards Universal Visual Reward & Representation

ZEST
▶

Foundation Models for Zero-Shot Task Specification

RRL
▶

RRL: ResNet as Representation for Reinforcement Learning

Multi-Task / Hierarchical Learning

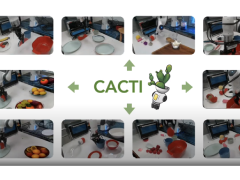
CACTI
▶

CACTI: Scalable Multi-Task Multi-Scene Imitation Learning

Relay Policy Learning
▶

Relay Policy Learning

Learning From Play
▶

Learning From Play

Multi-Task Manipulation
▶

Manipulation via Multi-Task Learning

Model-Based Learning

PDDM
▶

Planning with Deep Dynamics Models (PDDM)

DADS
▶

Dynamics Aware Discovery of Skills (DADS)

TRASS
▶

Time Reversal as Self-Supervision

Dexterous Manipulation from Experience
▶

Learning Dexterous Manipulation from Experience & Imitation

Model-Free Learning

Demo Augmented Policy Gradients
▶

Demo Augmented Policy Gradients

DClaw RL
▶

RL: Efficient, General & Low-Cost

R3L
▶

Ingredients of Real-World Reinforcement Learning

ROBEL
▶

Robotics Benchmarks for Learning (ROBEL)

Manipulation via Locomotion
▶

Manipulation via Locomotion

Divide-and-Conquer RL
▶

Divide-and-Conquer Reinforcement Learning

Trajectory Optimization

Hand Manipulation
▶

Real-Time Behaviour Synthesis for Dynamic Hand-Manipulation

DRC MPC
▶

Real-Time MPC for Humanoid Robots (DRC)

Behavior Synthesis
▶

Synthesis of Complex Behaviors with Optimal Control

Platforms & Hardware

ADROIT
▶

ADROIT: Anthropomorphic Dexterous Manipulation Platform

D-Manus
▶

D-Manus: Dexterous Hand with Large-Area Tactile Sensing

20-DOF Robotic Hand
▶

Low-Cost Modular 20-DOF Anthropomorphic Robotic Hand

Haptic VR
▶

Physically Realistic VR: Hand Manipulation

DARPA DRC
▶

DARPA Robotics Challenge: Humanoid MPC System

Pneumatic Actuation
▶

Fast & Compliant Pneumatic Actuation for Tendon-Driven Systems

Benchmarking

RoboHive
▶

RoboHive: A Unified Framework for Robot Learning

MyoChallenge
▶

MyoChallenge 2022: Musculoskeletal Manipulation Benchmark

ROBEL
▶

Robotics Benchmarks for Learning (ROBEL)

Multi-Goal RL Environments
▶

Multi-Goal RL: Challenging Robotics Environments

Benchmarking In-Hand Manipulation
▶

Benchmarking In-Hand Manipulation

Brain-Machine Interface

BMI Hand Reconstruction
▶

Hand Reconstruction from Motor Cortex Recordings

GMI
▶

Object Repositioning via Gesture Machine Interface

Eye Gesture Control
▶

Closed-Loop Control with Gesture Machine Interface

Tracking & Calibration

Kinematic Calibration
▶

Precise Robot Calibration via Kinematic Extensions

STAC
▶

STAC: Simultaneous Tracking and Calibration

You are visitor 01402503 — GeezerVison does not store the pages you look up.
Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required.