GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing ericcsr.github.io — About me Hi, I am Sirui (Eric) Chen (陈思睿), a final-year CS PhD student at Stanford advised by Professor Karen Liu. I am interested in designing robot control and planning algorithms for contact-rich tasks such as dexterous manipulation and humanoid whole-body loco-manipulation. I also work on solving complex control problems on real robots by combining human demonstrations from different sources with analytical modeling. I interned at Honda Research Institute in summer 2024, advised by Rana Soltani Zarrin; at NVIDIA GEAR Lab in summer and fall 2025, advised by Yuke Zhu and Zhengyi Luo; and at Amazon FAR in 2026, advised by Karen Liu and Guanya Shi. In my free time, I enjoy photography and hiking; here are some photos I have taken. Feel free to reach out about full-time opportunities or to discuss research ideas. Selected research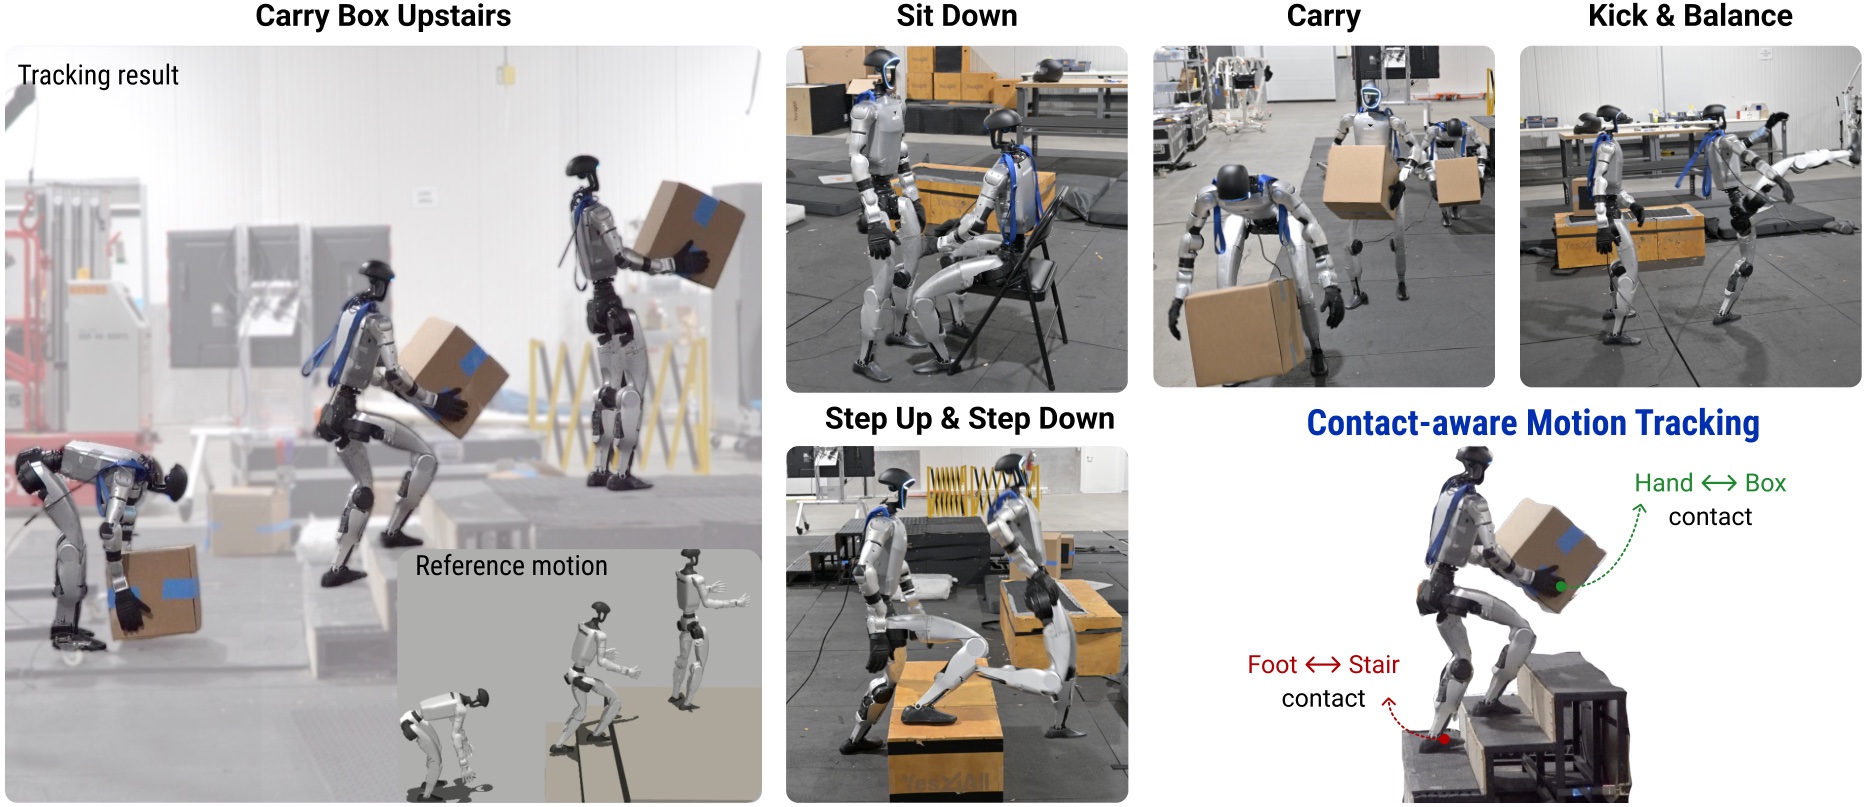 SceneBot: Contact-Prompted General Humanoid Whole Body Tracking with Scene-InteractionArxiv, 2026 A unified contact-conditioned humanoid tracker for free-space motion, terrain, and object interaction 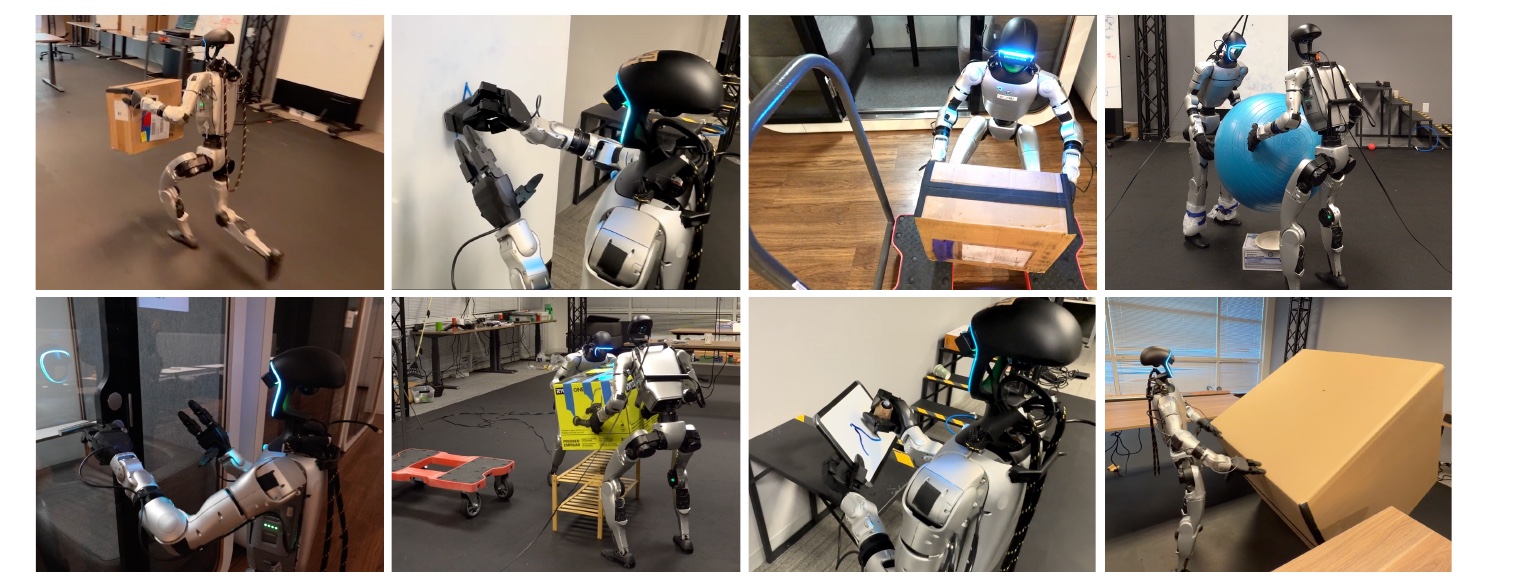 CHIP: Adaptive Compliance for Humanoid Control through Hindsight PerturbationConference on Robot Learning, 2026 A plug-and-play module for controllable humanoid end-effector compliance  SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body ControlScience Robotics, 2026 Scaling up humanoid robot control via motion tracking |
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |