GV

GeezerVison

The World Wide Web, restored to 800 pixels of glory.

Home|About|Gaming cabinet|Archives|How it works|Starter sites

On this site

  • Sign in
  • ActionsCI/CD and automation
  • CodespacesCloud development environments
  • All Features
  • Documentation
  • Training
  • Certifications
  • Build with Copilot
  • Customize Copilot
  • Integrations
  • Trending repos
  • GitHub Sponsors
  • Developer articles
  • Enterprises

This view

  • Original page
  • New address

GeezerVison is showing github.com — GitHub - uos/ros2_tutorial: Tutorials for the KBS robotics labs

BranchesTags
Open more actions menu

Latest commit


History

19 Commits
19 Commits

Folders and files

NameName
Last commit message
Last commit date
ex01_first_package
ex01_first_package
 
 
ex02_gazebo_simulation
 
 
ex03_state_estimation
 
 
ex04_navigation
ex04_navigation
 
 
ex05_behavior_trees
ex05_behavior_trees
 
 
media
media
 
 
README.md
README.md
 
 
TEACHERS.md
TEACHERS.md


Repository files navigation

ros2_tutorial

ROS2 humble - Tutorials for the KBS robotics labs in wintersemester 2023/24; Osnabrück University. A computer is needed with:

  • Ubuntu 22. Only native! Dual-boot is OK.
  • ROS2 humble (see first tutorial)

All examples are implemented using C++ programming language. The course is at a very beginner level. In the end you will be able to let a robot autonomously drive from A to B as shown here:
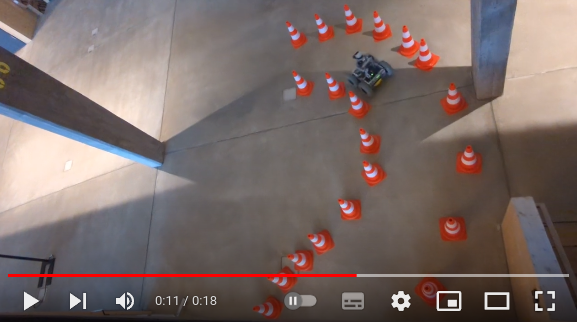
Ceres Robot Nav

ex01_first_package

  • Learning ROS concepts
  • Writing a simple subscriber and publisher
  • Learning C++ and CMake by implementing subscribers and publishers in different ways
  • Learn to use vim
  • Environment variables, .bashrc

ex02_gazebo_simulation

  • Start a robot! Virtually
  • More ROS packaging
  • RViz2
  • New message: LaserScan
  • Transformations: Concept, Implementation
  • New message: PointCloud2
  • ROS2 parameters + remapping
  • XML launch files
  • Fun: Steer the robot
  • New message: Twist

ex03_state_estimation

  • Concept: State Estimation via
    • Wheel Odometry
    • IMU
    • LiDAR
    • Camera
  • Fusion
    • Kalman-Filter
    • robot_localization-package
  • Start a robot! In reality.
  • Tool: tmux
  • Mapping
    • Maps
    • SLAM

ex04_navigation

  • Localization in given maps
  • Nav2
  • Actions: Interfaces, Servers, Clients
  • Trigger Nav2 action servers via C++-Nodes

ex05_behavior_trees

!! Unfinished !!

  • Overview: Deliberation Layer
  • BehaviorTree.CPP
  • Simple Behavior Tree
  • Simple Behavior Tree with Groot monitor
  • Writing Behavior Tree Plugins

TODOs:

  • Editing/creating trees using Groot
  • Using the Blackboard

More TODOs in ex05 README.

Information for Teachers

Further information for teachers: Click here.

About

Tutorials for the KBS robotics labs

Resources

Readme
Activity
Custom properties

Stars

68 stars

Watchers

6 watching

Forks

16 forks
Report repository

Releases

Contributors

Languages

You are visitor 01402503 — GeezerVison does not store the pages you look up.
Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required.