GeezerVisonThe World Wide Web, restored to 800 pixels of glory. |
| Home|About|Gaming cabinet|Archives|How it works|Starter sites |
GeezerVison is showing xbpeng.github.io — Xue Bin (Jason) Peng 
Xue Bin (Jason) PengI'm an Assistant Professor at Simon Fraser University (SFU) and a Research Scientist at NVIDIA. I hold a Canada CIFAR AI Chair through Amii. I will be moving to the University of British Columbia (UBC) in 2027. I received a Ph.D. from UC Berkeley, advised by Professor Sergey Levine and Professor Pieter Abbeel. Prior to that, I received an M.Sc from the University of British Columbia, advised by Professor Michiel van de Panne. My work lies in the intersection between computer graphics and machine learning, with a focus on reinforcement learning for motion control of simulated characters. I have previously worked for Google, OpenAI, Adobe Research, Disney Research, Microsoft (343 Industries), and Capcom. CodebasePublications2026
Learning Whole-Body Humanoid Locomotion via Motion Generation and Motion Tracking
Zewei Zhang, Kehan Wen, Michael Xu, Junzhe He, Chenhao Li, Takahiro Miki, Clemens Schwarke, Chong Zhang, Xue Bin Peng, Marco Hutter
IEEE Robotics and Automation Letters (RA-L 2026)
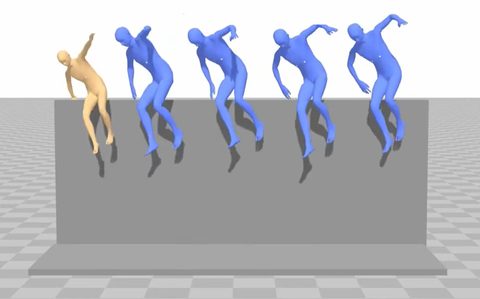
DMP: Directable Motion Retargeting through Motion Paraphrasing
Sunmin Lee, Davis Rempe, Yifeng Jiang, Haotian Zhang, Tingwu Wang, Jungdam Won, Xue Bin Peng
ACM Transactions on Graphics (TOG 2026)
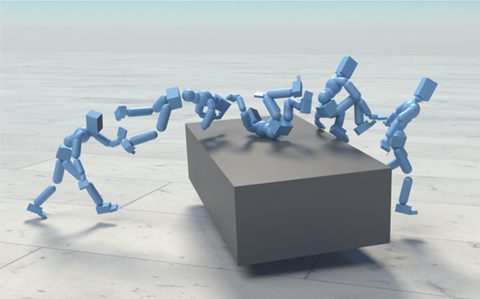
HIL: Hybrid Imitation Learning for Dynamic Athletic Control
Jiashun Wang, Yifeng Jiang, Haotian Zhang, Chen Tessler, Davis Rempe, Jessica Hodgins, Xue Bin Peng
ACM Transactions on Graphics (TOG 2026)
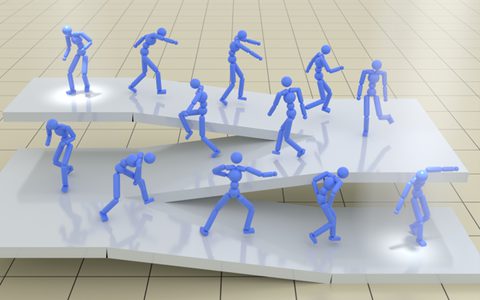
SMP: Reusable Score-Matching Motion Priors for Physics-Based Character Control
Yuxuan Mu, Ziyu Zhang, Yi Shi, Dun Yang, Minami Matsumoto, Kotaro Imamura, Guy Tevet, Chuan Guo, Michael Taylor, Chang Shu, Pengcheng Xi, Xue Bin Peng
ACM Transactions on Graphics (Proc. SIGGRAPH 2026)
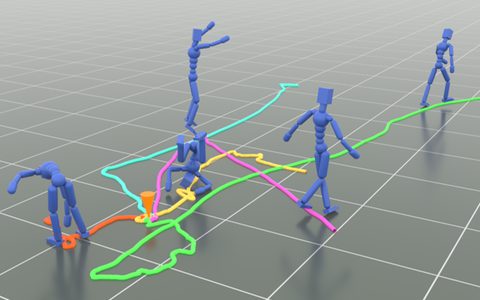
GPC: Large-Scale Generative Pretraining for Transferable Motor Control
Yi Shi, Yifeng Jiang, Chen Tessler, Xue Bin Peng
ACM SIGGRAPH 2026
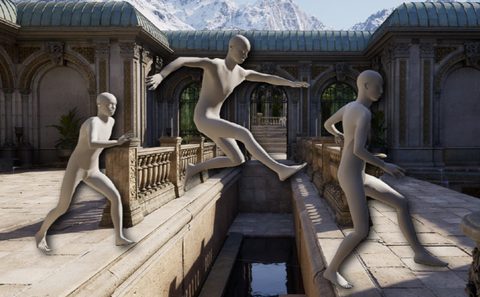
MotionBricks: Scalable Real-Time Motions with Modular Latent Generative Model and Smart Primitives
Tingwu Wang, Olivier Dionne, Michael de Ruyter, David Minor, Davis Rempe, Kaifeng Zhao, Mathis Petrovich, Ye Yuan, Chenran Li, Zhengyi Luo, Brian Robison, Xavier Blackwell, Bernardo Antoniazzi, Xue Bin Peng, Yuke Zhu, Simon Yuen
ACM Transactions on Graphics (Proc. SIGGRAPH 2026)

Robo-Saber: Generating and Simulating Virtual Reality Players
Nam Hee Kim, Jingjing May Liu, Jaakko Lehtinen, Perttu Hämäläinen, James F. O'Brien, Xue Bin Peng
Conference of the European Association for Computer Graphics (Eurographics 2026)
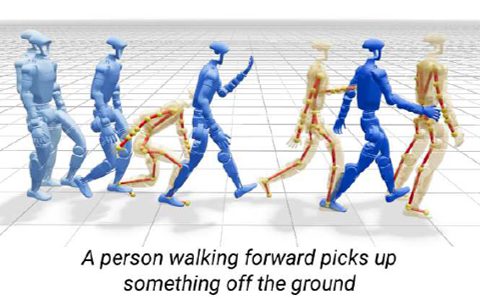
Kimodo: Scaling Controllable Human Motion Generation
Davis Rempe, Mathis Petrovich, Ye Yuan, Haotian Zhang, Xue Bin Peng, Yifeng Jiang, Tingwu Wang, Umar Iqbal, David Minor, Michael de Ruyter, Jiefeng Li, Chen Tessler, Edy Lim, Eugene Jeong, Sam Wu, Ehsan Hassani, Michael Huang, Jin-Bey Yu, Chaeyeon Chung, Lina Song, Olivier Dionne, Jan Kautz, Simon Yuen, Sanja Fidler
arXiv Preprint 2026
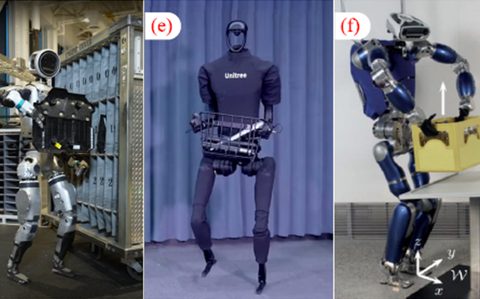
Humanoid Locomotion and Manipulation: Current Progress and Challenges in Control, Planning, and Learning
Zhaoyuan Gu, Junheng Li, Wenlan Shen, Wenhao Yu, Zhaoming Xie, Stephen McCrory, Xianyi Cheng, Abdulaziz Shamsah, Robert Griffin, C. Karen Liu, Abderrahmane Kheddar, Xue Bin Peng, Yuke Zhu, Guanya Shi, Quan Nguyen, Gordon Cheng, Huijun Gao, Ye Zhao
IEEE/ASME Transactions on Mechatronics (TMECH 2026)
2025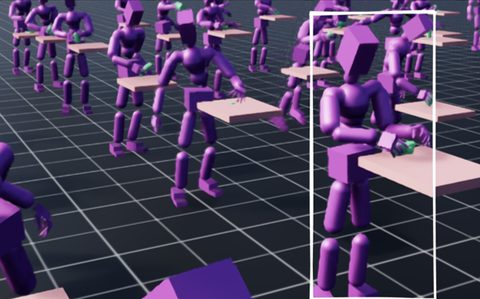
MaskedManipulator: Versatile Whole-Body Manipulation
Chen Tessler, Yifeng Jiang, Erwin Coumans, Zhengyi Luo, Gal Chechik, Xue Bin Peng
ACM SIGGRAPH Asia 2025
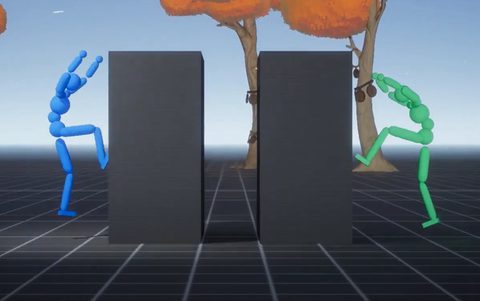
Physics-Based Motion Imitation with Adversarial Differential Discriminators
Ziyu Zhang, Sergey Bashkirov, Dun Yang, Yi Shi, Michael Taylor, Xue Bin Peng
ACM SIGGRAPH Asia 2025
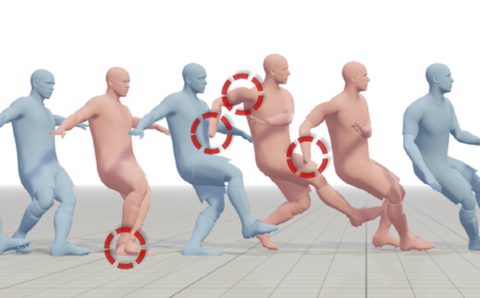
StableMotion: Training Motion Cleanup Models with Unpaired Corrupted Data
Yuxuan Mu, Hung Yu Ling, Yi Shi, Ismael Baira Ojeda, Pengcheng Xi, Chang Shu, Fabio Zinno, Xue Bin Peng
ACM SIGGRAPH Asia 2025
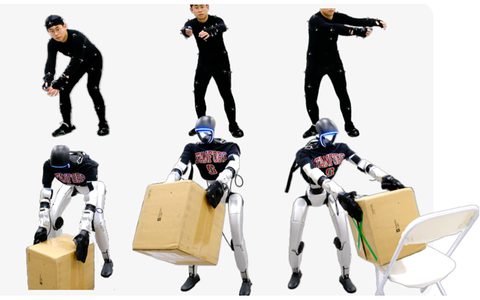
TWIST: Teleoperated Whole-Body Imitation System
Yanjie Ze, Zixuan Chen, João Pedro Araújo, Zi-ang Cao, Xue Bin Peng, Jiajun Wu, C. Karen Liu
Conference on Robot Learning (CoRL 2025)
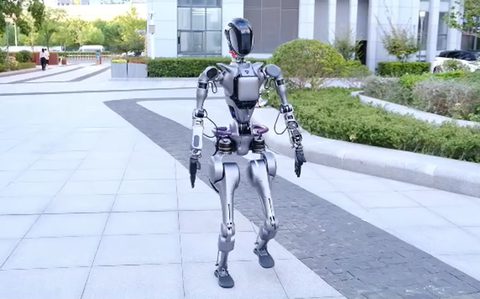
Learning Smooth Humanoid Locomotion through Lipschitz-Constrained Policies
Zixuan Chen, Xialin He, Yen-Jen Wang, Qiayuan Liao, Yanjie Ze, Zhongyu Li, S. Shankar Sastry, Jiajun Wu, Koushil Sreenath, Saurabh Gupta, Xue Bin Peng
IEEE International Conference on Intelligent Robots and Systems (IROS 2025)

Generalizable Humanoid Manipulation with 3D Diffusion Policies
Yanjie Ze, Zixuan Chen, Wenhao Wang, Tianyi Chen, Xialin He, Ying Yuan, Xue Bin Peng, Jiajun Wu
IEEE International Conference on Intelligent Robots and Systems (IROS 2025)
PARC: Physics-based Augmentation with Reinforcement Learning for Character Controllers
Michael Xu, Yi Shi, KangKang Yin, Xue Bin Peng
ACM SIGGRAPH 2025
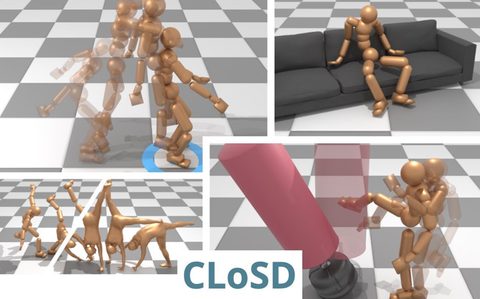
CLoSD: Closing the Loop Between Simulation and Diffusion for Multi-Task Character Control
Guy Tevet, Sigal Raab, Setareh Cohan, Daniele Reda, Zhengyi Luo, Xue Bin Peng, Amit H. Bermano, Michiel van de Panne
International Conference on Learning Representations (ICLR 2025)
Spotlight
2024
Reinforcement Learning for Versatile, Dynamic, and Robust Bipedal Locomotion Control
Zhongyu Li, Xue Bin Peng, Pieter Abbeel, Sergey Levine, Glen Berseth, Koushil Sreenath
The International Journal of Robotics Research (IJRR 2024)
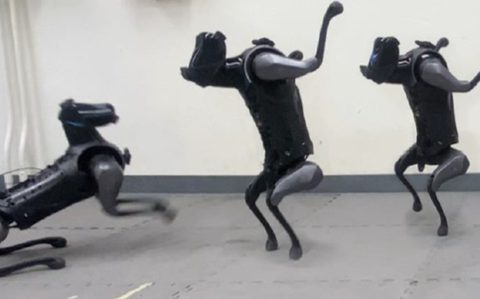
DiffuseLoco: Real-Time Legged Locomotion Control with Diffusion from Offline Datasets
Xiaoyu Huang, Yufeng Chi, Ruofeng Wang, Zhongyu Li, Xue Bin Peng, Sophia Shao, Borivoje Nikolic, Koushil Sreenath
Conference on Robot Learning (CoRL 2024)
HiLMa-Res: A General Hierarchical Framework via Residual RL for Combining Quadrupedal Locomotion and Manipulation
Xiaoyu Huang, Qiayuan Liao, Yiming Ni, Zhongyu Li, Laura Smith, Sergey Levine, Xue Bin Peng, Koushil Sreenath
IEEE International Conference on Intelligent Robots and Systems (IROS 2024)
MaskedMimic: Unified Physics-Based Character Control Through Masked Motion Inpainting
Chen Tessler, Yunrong Guo, Ofir Nabati, Gal Chechik, Xue Bin Peng
ACM Transactions on Graphics (Proc. SIGGRAPH Asia 2024)
Interactive Character Control with Auto-Regressive Motion Diffusion Models
Yi Shi, Jingbo Wang, Xuekun Jiang, Bingkun Lin, Bo Dai, Xue Bin Peng
ACM Transactions on Graphics (Proc. SIGGRAPH 2024)

SuperPADL: Scaling Language-Directed Physics-Based Control with Progressive Supervised Distillation
Jordan Juravsky, Yunrong Guo, Sanja Fidler, Xue Bin Peng
ACM SIGGRAPH 2024
Flexible Motion In-betweening with Diffusion Models
Setareh Cohan, Guy Tevet, Daniele Reda, Xue Bin Peng, Michiel van de Panne
ACM SIGGRAPH 2024
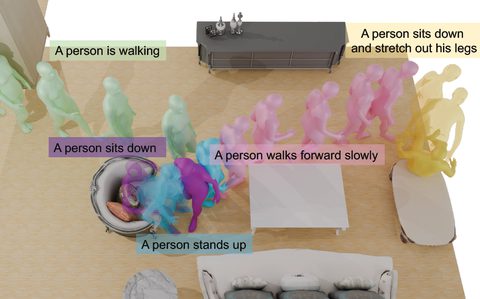
Generating Human Interaction Motions in Scenes with Text Control
Hongwei Yi, Justus Thies, Michael J. Black, Xue Bin Peng, Davis Rempe
European Conference on Computer Vision (ECCV 2024)
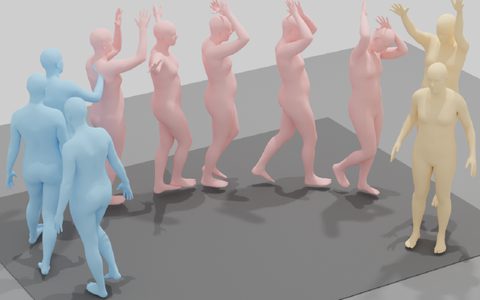
Multi-Track Timeline Control for Text-Driven 3D Human Motion Generation
Mathis Petrovich, Or Litany, Umar Iqbal, Michael J. Black, Gül Varol, Xue Bin Peng, Davis Rempe
CVPR Workshop on Human Motion Generation (CVPR Workshop 2024)

Trajeglish: Traffic Modeling as Next-Token Prediction
Jonah Philion, Xue Bin Peng, Sanja Fidler
International Conference on Learning Representations (ICLR 2024)
2023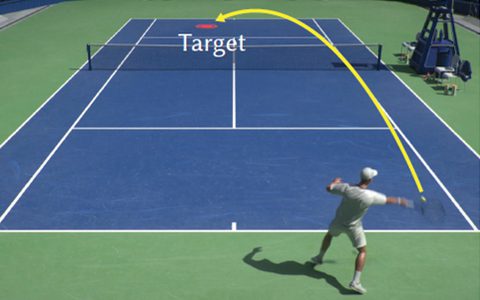
Learning Physically Simulated Tennis Skills from Broadcast Videos
Haotian Zhang, Ye Yuan, Viktor Makoviychuk, Yunrong Guo, Sanja Fidler, Xue Bin Peng, Kayvon Fatahalian
ACM Transactions on Graphics (Proc. SIGGRAPH 2023)
Best Paper Honourable Mention
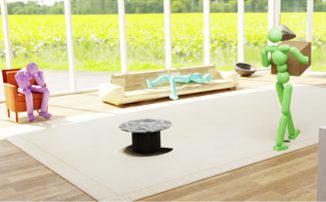
Synthesizing Physical Character-Scene Interactions
Mohamed Hassan, Yunrong Guo, Tingwu Wang, Michael J. Black, Sanja Fidler, Xue Bin Peng
ACM SIGGRAPH 2023
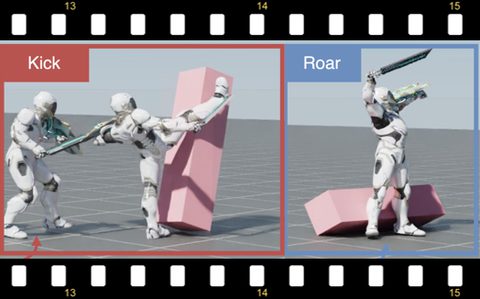
CALM: Conditional Adversarial Latent Models for Directable Virtual Characters
Chen Tessler, Yoni Kasten, Yunrong Guo, Shie Mannor, Gal Chechik, Xue Bin Peng
ACM SIGGRAPH 2023
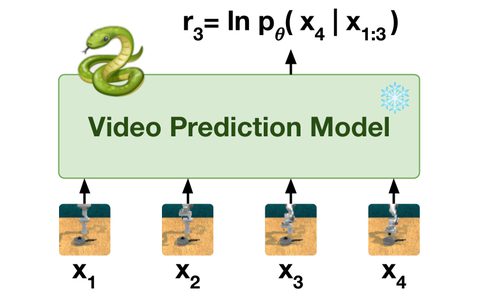
Video Prediction Models as Rewards for Reinforcement Learning
Alejandro Escontrela, Ademi Adeniji, Wilson Yan, Ajay Jain, Xue Bin Peng, Ken Goldberg, Youngwoon Lee, Danijar Hafner, Pieter Abbeel
Neural Information Processing Systems (NeurIPS 2023)
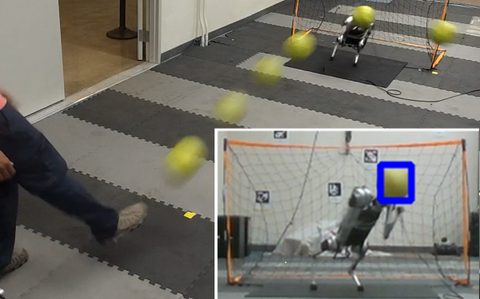
Creating a Dynamic Quadrupedal Robotic Goalkeeper with Reinforcement Learning
Xiaoyu Huang, Zhongyu Li, Yanzhen Xiang, Yiming Ni, Yufeng Chi, Yunhao Li, Lizhi Yang, Xue Bin Peng, Koushil Sreenath
IEEE International Conference on Intelligent Robots and Systems (IROS 2023)
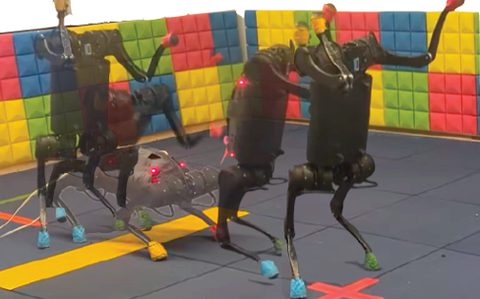
Learning and Adapting Agile Locomotion Skills by Transferring Experience
Laura Smith, J. Chase Kew, Tianyu Li, Linda Luu, Xue Bin Peng, Sehoon Ha, Jie Tan, Sergey Levine
Robotics: Science and Systems (RSS 2023)

RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning
Kevin Zakka, Philipp Wu, Laura Smith, Nimrod Gileadi, Taylor Howell, Xue Bin Peng, Sumeet Singh, Yuval Tassa, Pete Florence, Andy Zeng, Pieter Abbeel
Conference on Robot Learning (CoRL 2023)
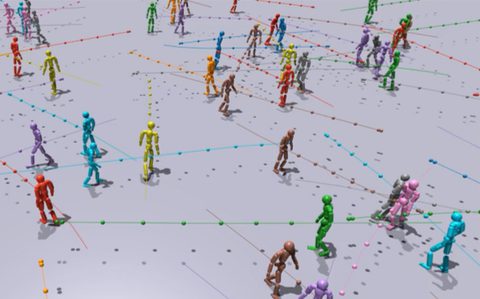
Trace and Pace: Controllable Pedestrian Animation via Guided Trajectory Diffusion
Davis Rempe, Zhengyi Luo, Xue Bin Peng, Ye Yuan, Kris Kitani, Karsten Kreis, Sanja Fidler, Or Litany
Conference on Computer Vision and Pattern Recognition (CVPR 2023)

Robust and Versatile Bipedal Jumping Control through Reinforcement Learning
Zhongyu Li, Xue Bin Peng, Pieter Abbeel, Sergey Levine, Glen Berseth, Koushil Sreenath
Robotics: Science and Systems (RSS 2023)
2022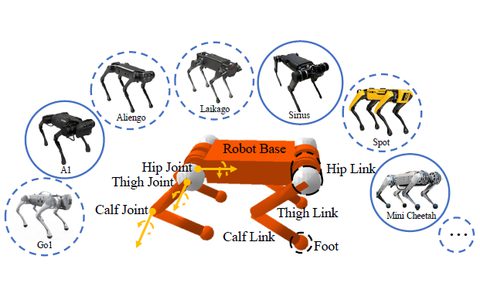
GenLoco: Generalized Locomotion Controllers for Quadrupedal Robots
Gilbert Feng, Hongbo Zhang, Zhongyu Li, Xue Bin Peng, Bhuvan Basireddy, Linzhu Yue, Zhitao Song, Lizhi Yang, Yunhui Liu, Koushil Sreenath, Sergey Levine
Conference on Robot Learning (CoRL 2022)
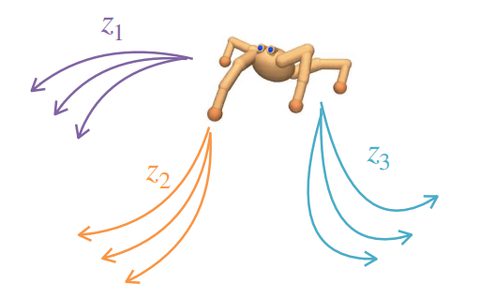
Unsupervised Reinforcement Learning with Contrastive Intrinsic Control
Michael Laskin, Hao Liu, Xue Bin Peng, Denis Yarats, Aravind Rajeswaran, Pieter Abbeel
Neural Information Processing Systems (NeurIPS 2022)
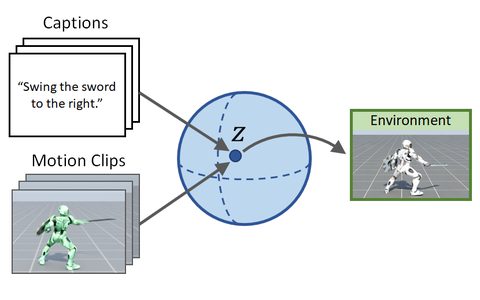
PADL: Language-Directed Physics-Based Character Control
Jordan Juravsky, Yunrong Guo, Sanja Fidler, Xue Bin Peng
ACM SIGGRAPH Asia 2022
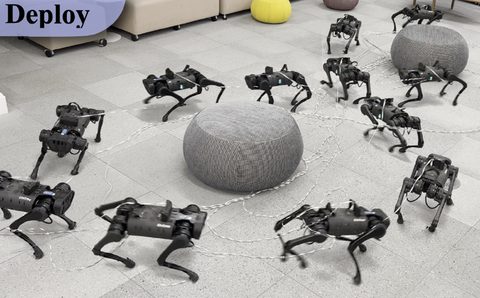
Adversarial Motion Priors Make Good Substitutes for Complex Reward Functions
Alejandro Escontrela, Xue Bin Peng, Wenhao Yu, Tingnan Zhang, Atil Iscen, Ken Goldberg, Pieter Abbeel
IEEE International Conference on Intelligent Robots and Systems (IROS 2022)

Hierarchical Reinforcement Learning for Precise Soccer Shooting Skills using a Quadrupedal Robot
Yandong Ji, Zhongyu Li, Yinan Sun, Xue Bin Peng, Sergey Levine, Glen Berseth, Koushil Sreenath
IEEE International Conference on Intelligent Robots and Systems (IROS 2022)
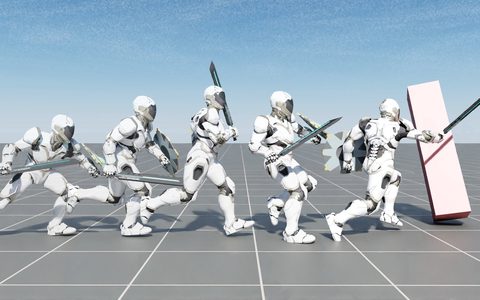
ASE: Large-Scale Reusable Adversarial Skill Embeddings for Physically Simulated Characters
Xue Bin Peng, Yunrong Guo, Lina Halper, Sergey Levine, Sanja Fidler
ACM Transactions on Graphics (Proc. SIGGRAPH 2022)
Legged Robots that Keep on Learning: Fine-Tuning Locomotion Policies in the Real World
Laura Smith, J. Chase Kew, Xue Bin Peng, Sehoon Ha, Jie Tan, Sergey Levine
IEEE International Conference on Robotics and Automation (ICRA 2022)
2021
Deep Reinforcement Learning for Modeling Human Locomotion Control in Neuromechanical Simulation
Seungmoon Song, Łukasz Kidziński, Xue Bin Peng, Carmichael Ong, Jennifer Hicks, Sergey Levine, Christopher G. Atkeson, Scott L. Delp
Journal of NeuroEngineering and Rehabilitation 2021
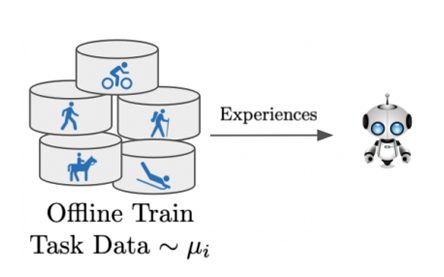
Offline Meta-Reinforcement Learning with Advantage Weighting
Eric Mitchell, Rafael Rafailov, Xue Bin Peng, Sergey Levine, Chelsea Finn
International Conference on Machine Learning (ICML 2021)
AMP: Adversarial Motion Priors for Stylized Physics-Based Character Control
Xue Bin Peng, Ze Ma, Pieter Abbeel, Sergey Levine, Angjoo Kanazawa
ACM Transactions on Graphics (Proc. SIGGRAPH 2021)

Reinforcement Learning for Robust Parameterized Locomotion Control of Bipedal Robots
Zhongyu Li, Xuxin Cheng, Xue Bin Peng, Pieter Abbeel, Sergey Levine, Glen Berseth, Koushil Sreenath
IEEE International Conference on Robotics and Automation (ICRA 2021)
2020
Learning Agile Robotic Locomotion Skills by Imitating Animals
Xue Bin Peng, Erwin Coumans, Tingnan Zhang, Tsang-Wei Edward Lee, Jie Tan, Sergey Levine
Robotics: Science and Systems (RSS 2020)
Best Paper Award
Reinforcement Learning with Competitive Ensembles of Information-Constrained Primitives
Anirudh Goyal, Shagun Sodhani, Jonathan Binas, Xue Bin Peng, Sergey Levine, Yoshua Bengio
International Conference on Learning Representations (ICLR 2020)
2019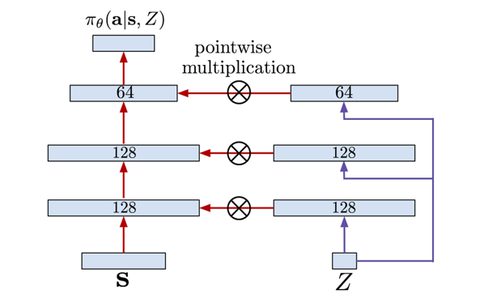
On Learning Symmetric Locomotion
Farzad Abdolhosseini, Hung Yu Ling, Zhaoming Xie, Xue Bin Peng, Michiel van de Panne
ACM SIGGRAPH Conference on Motion, Interaction, and Games (MIG 2019)
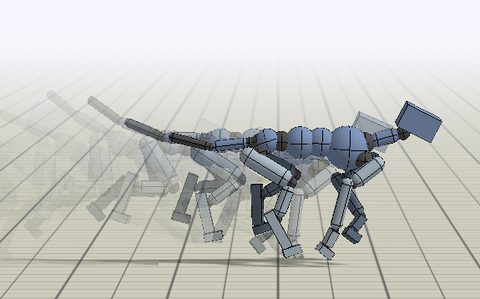
Advantage-Weighted Regression: Simple and Scalable Off-Policy Reinforcement Learning
Xue Bin Peng, Aviral Kumar, Grace Zhang, Sergey Levine
arXiv Preprint 2019
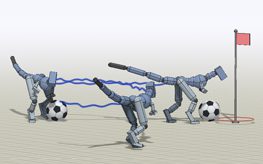
MCP: Learning Composable Hierarchical Control with Multiplicative Compositional Policies
Xue Bin Peng, Michael Chang, Grace Zhang, Pieter Abbeel, Sergey Levine
Neural Information Processing Systems (NeurIPS 2019)
Variational Discriminator Bottleneck: Improving Imitation Learning, Inverse RL, and GANs by Constraining Information Flow
Xue Bin Peng, Angjoo Kanazawa, Sam Toyer, Pieter Abbeel, Sergey Levine
International Conference on Learning Representations (ICLR 2019)
2018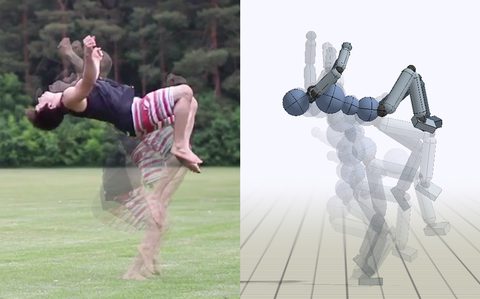
SFV: Reinforcement Learning of Physical Skills from Videos
Xue Bin Peng, Angjoo Kanazawa, Jitendra Malik, Pieter Abbeel, Sergey Levine
ACM Transactions on Graphics (Proc. SIGGRAPH Asia 2018)
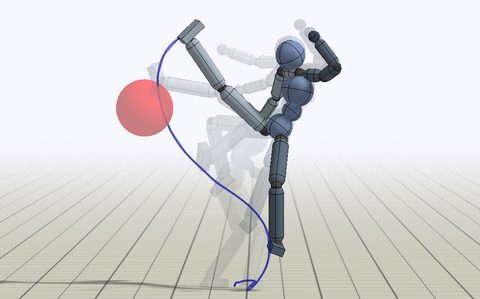
DeepMimic: Example-Guided Deep Reinforcement Learning of Physics-Based Character Skills
Xue Bin Peng, Pieter Abbeel, Sergey Levine, Michiel van de Panne
ACM Transactions on Graphics (Proc. SIGGRAPH 2018)
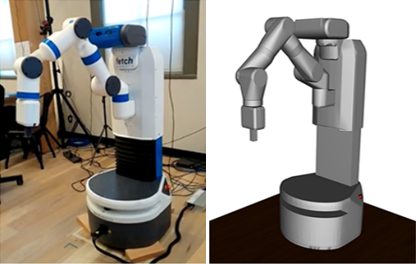
Sim-to-Real Transfer of Robotic Control with Dynamics Randomization
Xue Bin Peng, Marcin Andrychowicz, Wojciech Zaremba, Pieter Abbeel
IEEE International Conference on Robotics and Automation (ICRA 2018)
2017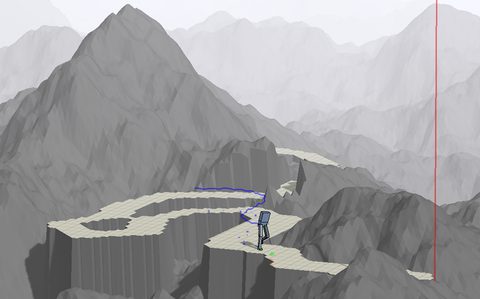
DeepLoco: Dynamic Locomotion Skills Using Hierarchical Deep Reinforcement Learning
Xue Bin Peng, Glen Berseth, KangKang Yin, Michiel van de Panne
ACM Transactions on Graphics (Proc. SIGGRAPH 2017)
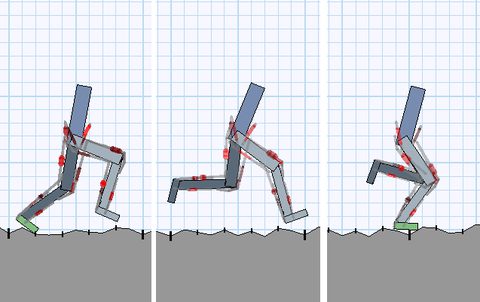
Learning Locomotion Skills Using DeepRL: Does the Choice of Action Space Matter?
Xue Bin Peng, Michiel van de Panne
ACM SIGGRAPH / Eurographics Symposium on Computer Animation 2017
Best Student Paper Award
2016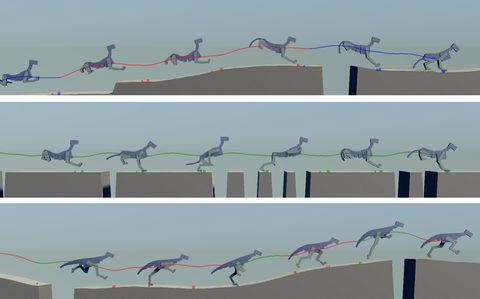
Terrain-Adaptive Locomotion Skills Using Deep Reinforcement Learning
Xue Bin Peng, Glen Berseth, Michiel van de Panne
ACM Transactions on Graphics (Proc. SIGGRAPH 2016)
2015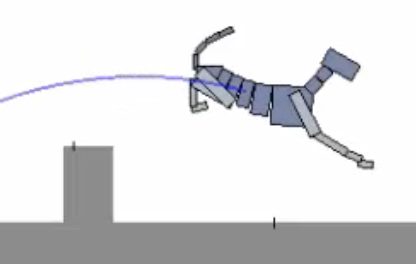
Dynamic Terrain Traversal Skills Using Reinforcement Learning
Xue Bin Peng, Glen Berseth, Michiel van de Panne
ACM Transactions on Graphics (Proc. SIGGRAPH 2015)
Thesis
Acquiring Motor Skills Through Motion Imitation and Reinforcement Learning
Ph.D. Thesis
University of California, Berkeley 2021

Developing Locomotion Skills with Deep Reinforcement Learning
M.Sc. Thesis
University of British Columbia 2017
|
| You are visitor 01402503 — GeezerVison does not store the pages you look up. Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required. |