GeezerVison is showing xukechun.github.io — Kechun Xu
|
Kechun Xu
I receive my PhD (2021 - 2026) in Control Science and Engineering department at Zhejiang University. I belong to Robotics Lab, advised by Prof. Rong Xiong and Yue Wang. I was a visiting student at MSC Lab in UC Berkeley, advised by Prof. Masayoshi Tomizuka. I also spent time in Alibaba Cloud and ZJ Humanoid as a research intern.
I obtained my B.Eng (2017 - 2021) in Control Science and Engineering and Mechanical and Electronic Engineering from Zhejiang University with an honor degree at Chu Kochen Honor College.
My current research interests lie in robotic manipulation, robot learning, and embodied AI. My research goal is to develop human-level intelligence in robotic manipulation, including behavior dexterity, learning efficiency, and open-world generalization.
Email /
Google Scholar /
Github /
Twitter /
LinkedIn
|
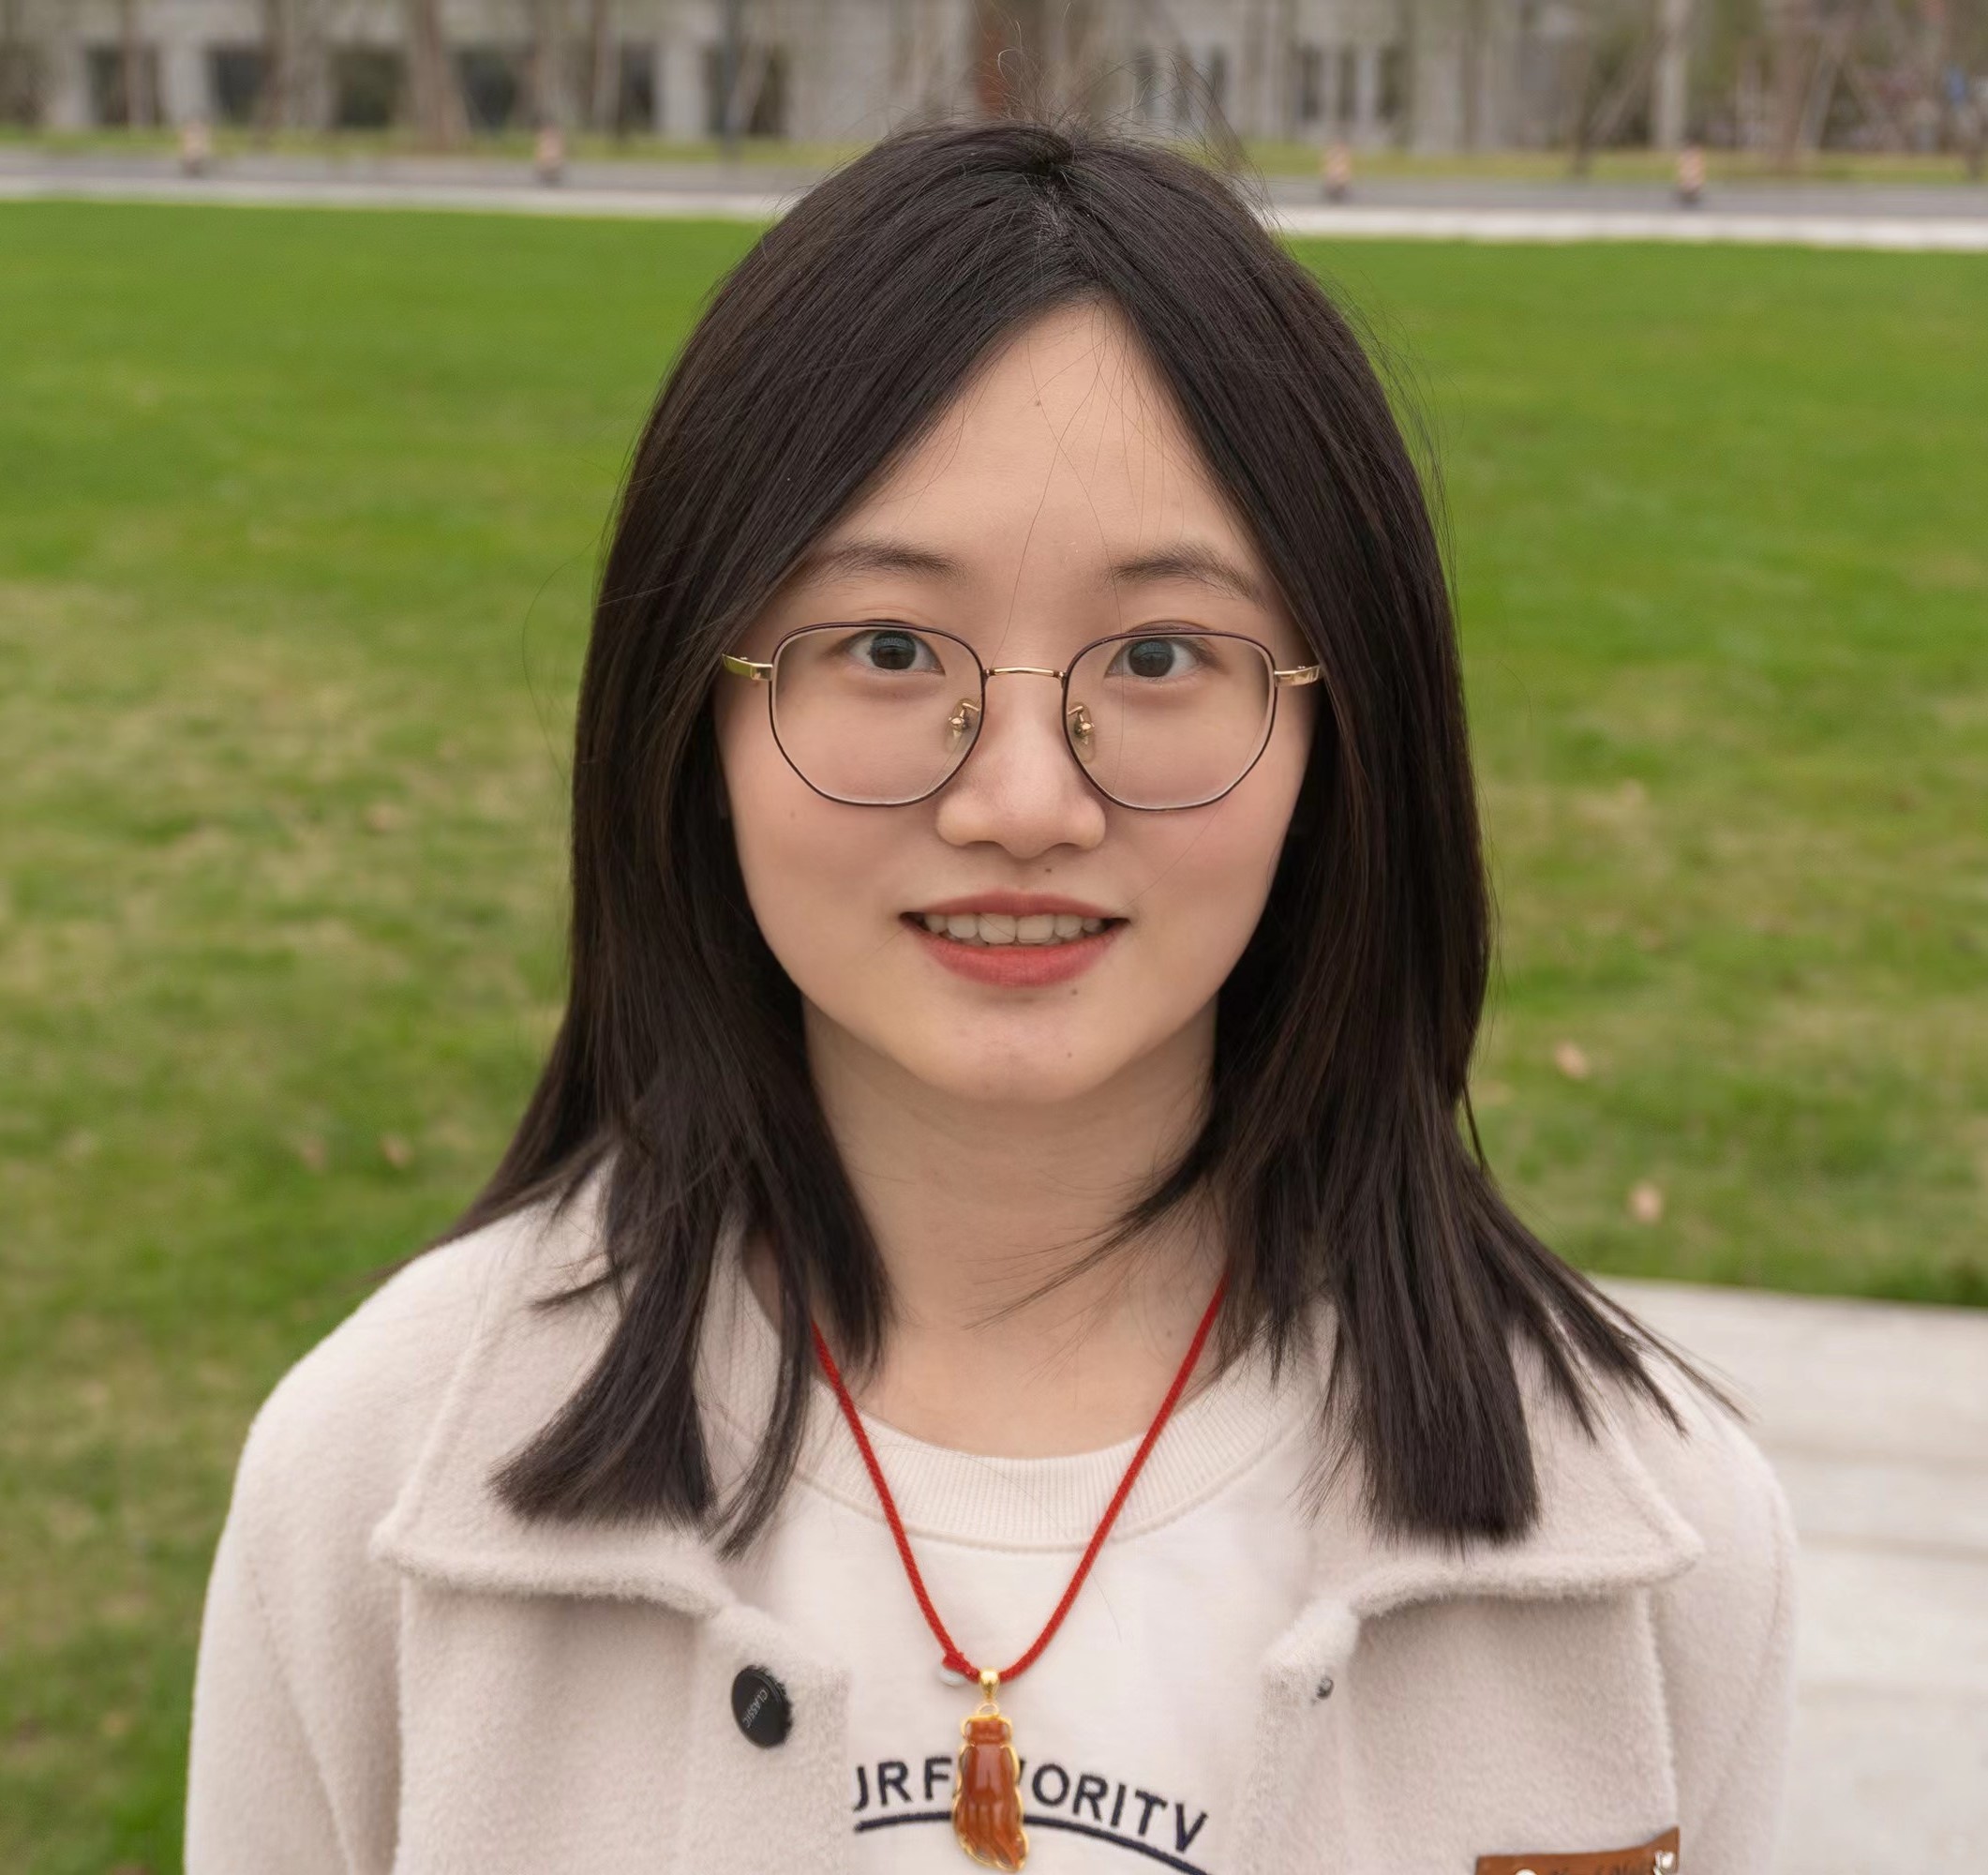
Photo taken by Zizhang Li.
|
- [09/2026] Two papers APT and TDC accepted to CoRL 2026.
- [06/2026] One paper APT is released on arXiv.
- [05/2026] One paper UniMM accepted to T-PAMI 2026.
- [03/2026] Honored to receive EAI-100 Next 20 Award.
- [02/2026] Invited talk at CAA Qingfan-series Talk.
- [02/2026] Invited talk on BayesVLA at Lumina Talk.
- [01/2026] A2 and E2VLA accepted to ICRA 2026.
- [01/2026] One paper PolyFold accepted to T-ASE 2026.
- [08/2025] One paper A2 accepted to T-ASE 2025.
- [05/2025] Invited talk at 3D视觉工坊.
- [04/2025] Invited talk at Autonomous Robotic Technology Seminar (ARTS).
- [12/2024] Invited talk at TEA Lab, Tsinghua University.
- [11/2024] Honored to receive ARTS Scholarship (Top 5 in China).
- [10/2024] One paper GSP accepted to T-RO 2024.
- [02/2023] Two papers VLG and FMP accepted to ICRA 2023.
- [02/2022] One paper EOM accepted to ICRA 2022.
- [06/2021] One paper EPG accepted to RA-L 2021.
|
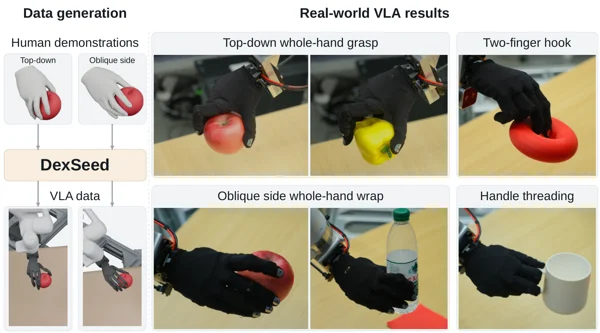
DexSeed: Expanding Human Hand–Object Interactions into Robot Demonstrations for Dexterous Policy Learning
Huaijin Pi,
Zehong Shen,
Yong Wang,
Kechun Xu,
Changpeng Wang,
Dingkun Wei,
Xueyang Wang,
Wenjia Wang,
Yujun Shen,
Xing Zhu,
Taku Komura
Under Review
|

|
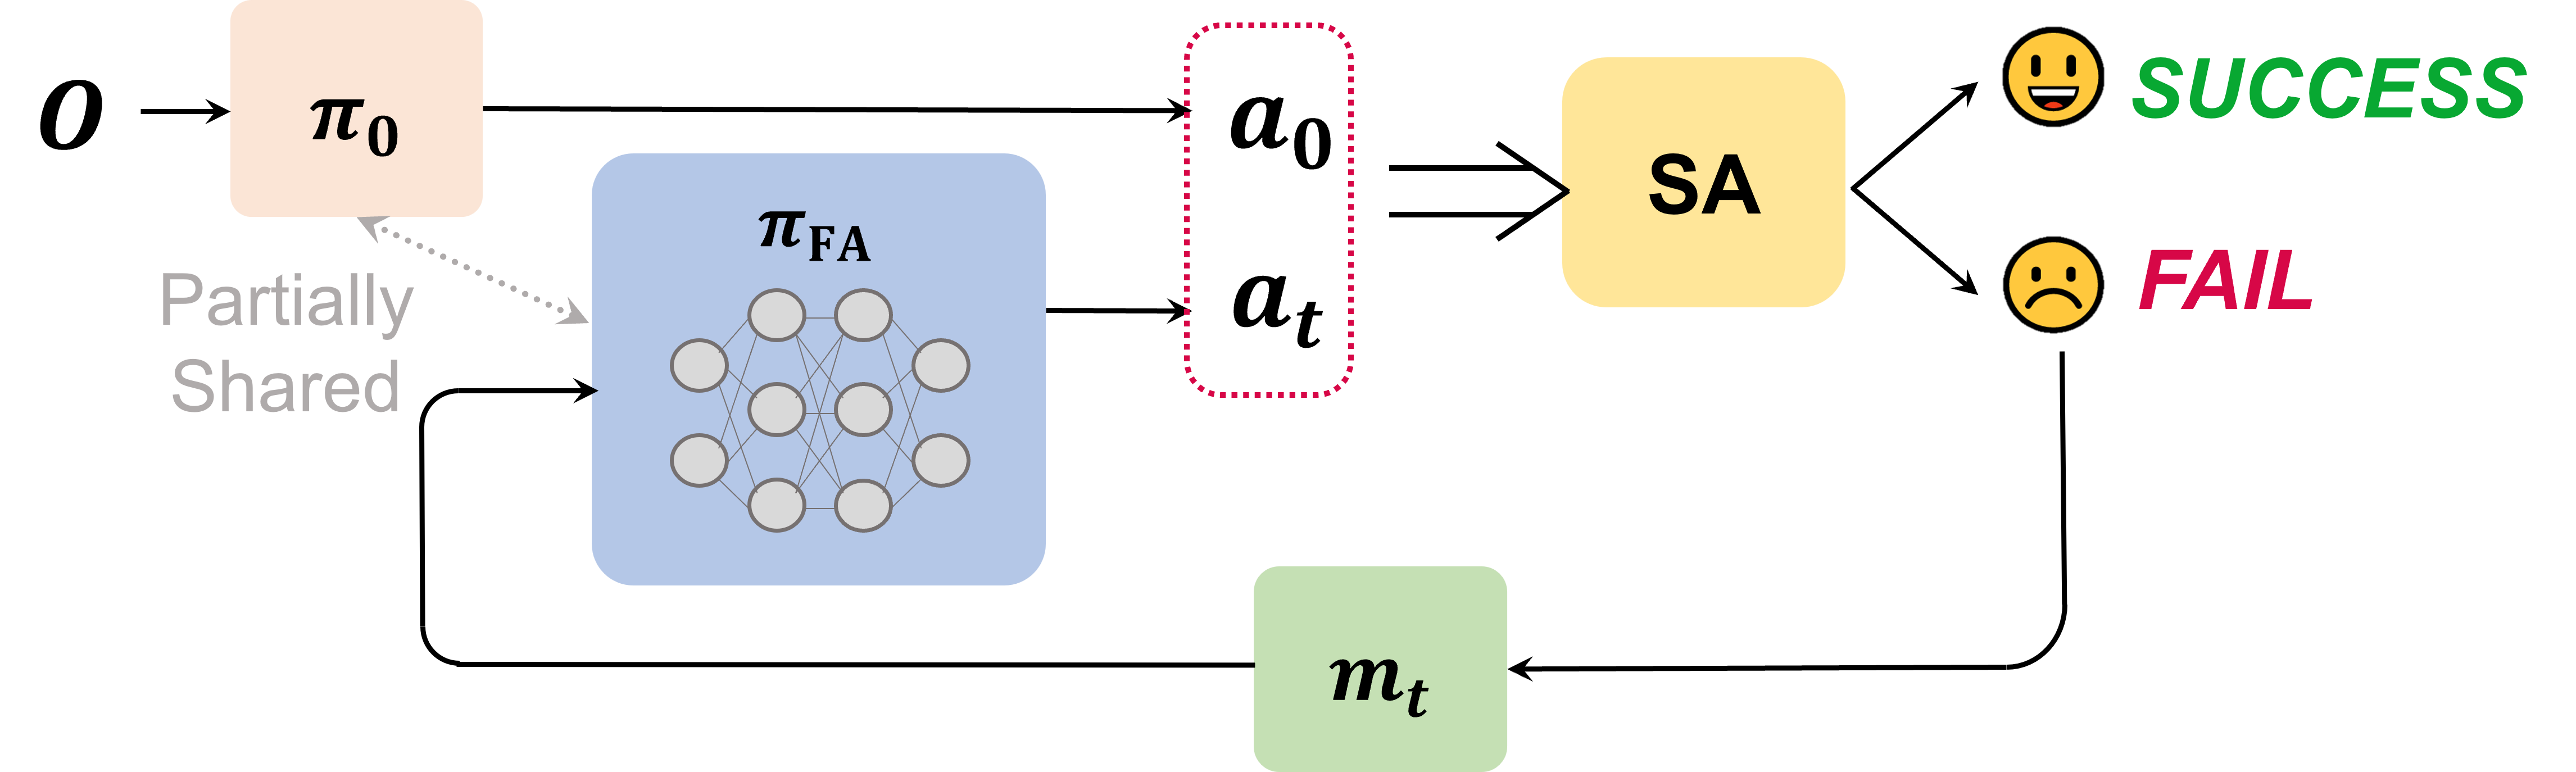
APT: Action Expert Pretraining Improves Instruction Generalization of Vision-Language-Action Policies
Kechun Xu,
Zhenjie Zhu,
Anzhe Chen,
Rong Xiong,
Yue Wang
Conference on Robot Learning (CoRL 2026)
|

|
Direction Matters: Learning Force Direction Enables Sim-to-Real Contact-Rich Manipulation
Yifei Yang,
Anzhe Chen,
Zhenjie Zhu,
Kechun Xu,
Yunxuan Mao,
Yufei Wei,
Lu Chen,
Rong Xiong,
Yue Wang
Conference on Robot Learning (CoRL 2026)
|

|
Seeing to Act, Prompting to Specify: A Bayesian Factorization of Vision Language Action Policy
Kechun Xu,
Zhenjie Zhu,
Anzhe Chen,
Shuqi Zhao,
Qing Huang,
Yifei Yang,
Haojian Lu,
Rong Xiong,
Masayoshi Tomizuka,
Yue Wang
Under Review
|

|
Toward Embodiment Equivariant Vision-Language-Action Policy
Anzhe Chen,
Yifei Yang,
Zhenjie Zhu,
Kechun Xu,
Zhongxiang Zhou,
Rong Xiong,
Yue Wang
IEEE International Conference on Robotics and Automation (ICRA 2026)
|

|
Efficient Alignment of Unconditioned Action Prior for Language-conditioned Pick and Place in Clutter
Kechun Xu,
Xunlong Xia,
Kaixuan Wang,
Yifei Yang,
Yunxuan Mao,
Bing Deng,
Jieping Ye,
Rong Xiong,
Yue Wang
IEEE Transactions on Automation Science and Engineering (T-ASE 2025)
Conference on Robot Learning (CoRL 2025), GenPriors Workshop
IEEE International Conference on Robotics and Automation (ICRA 2026)
|
|
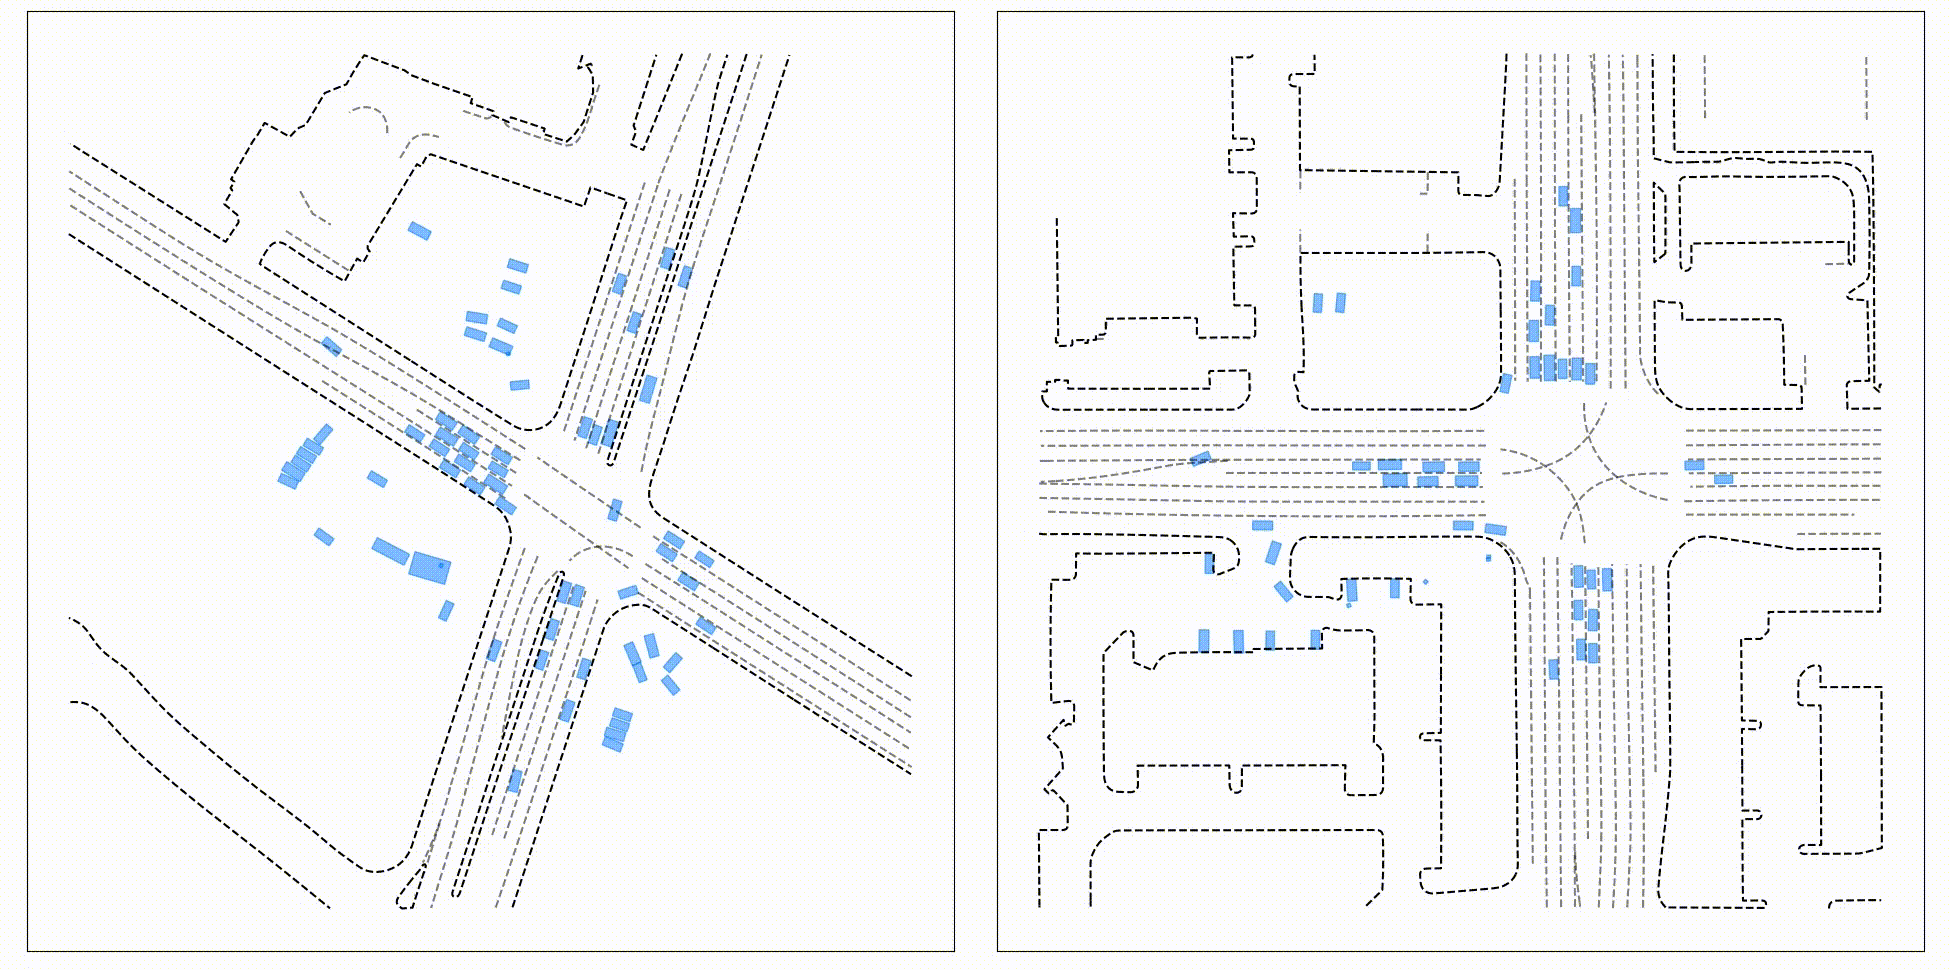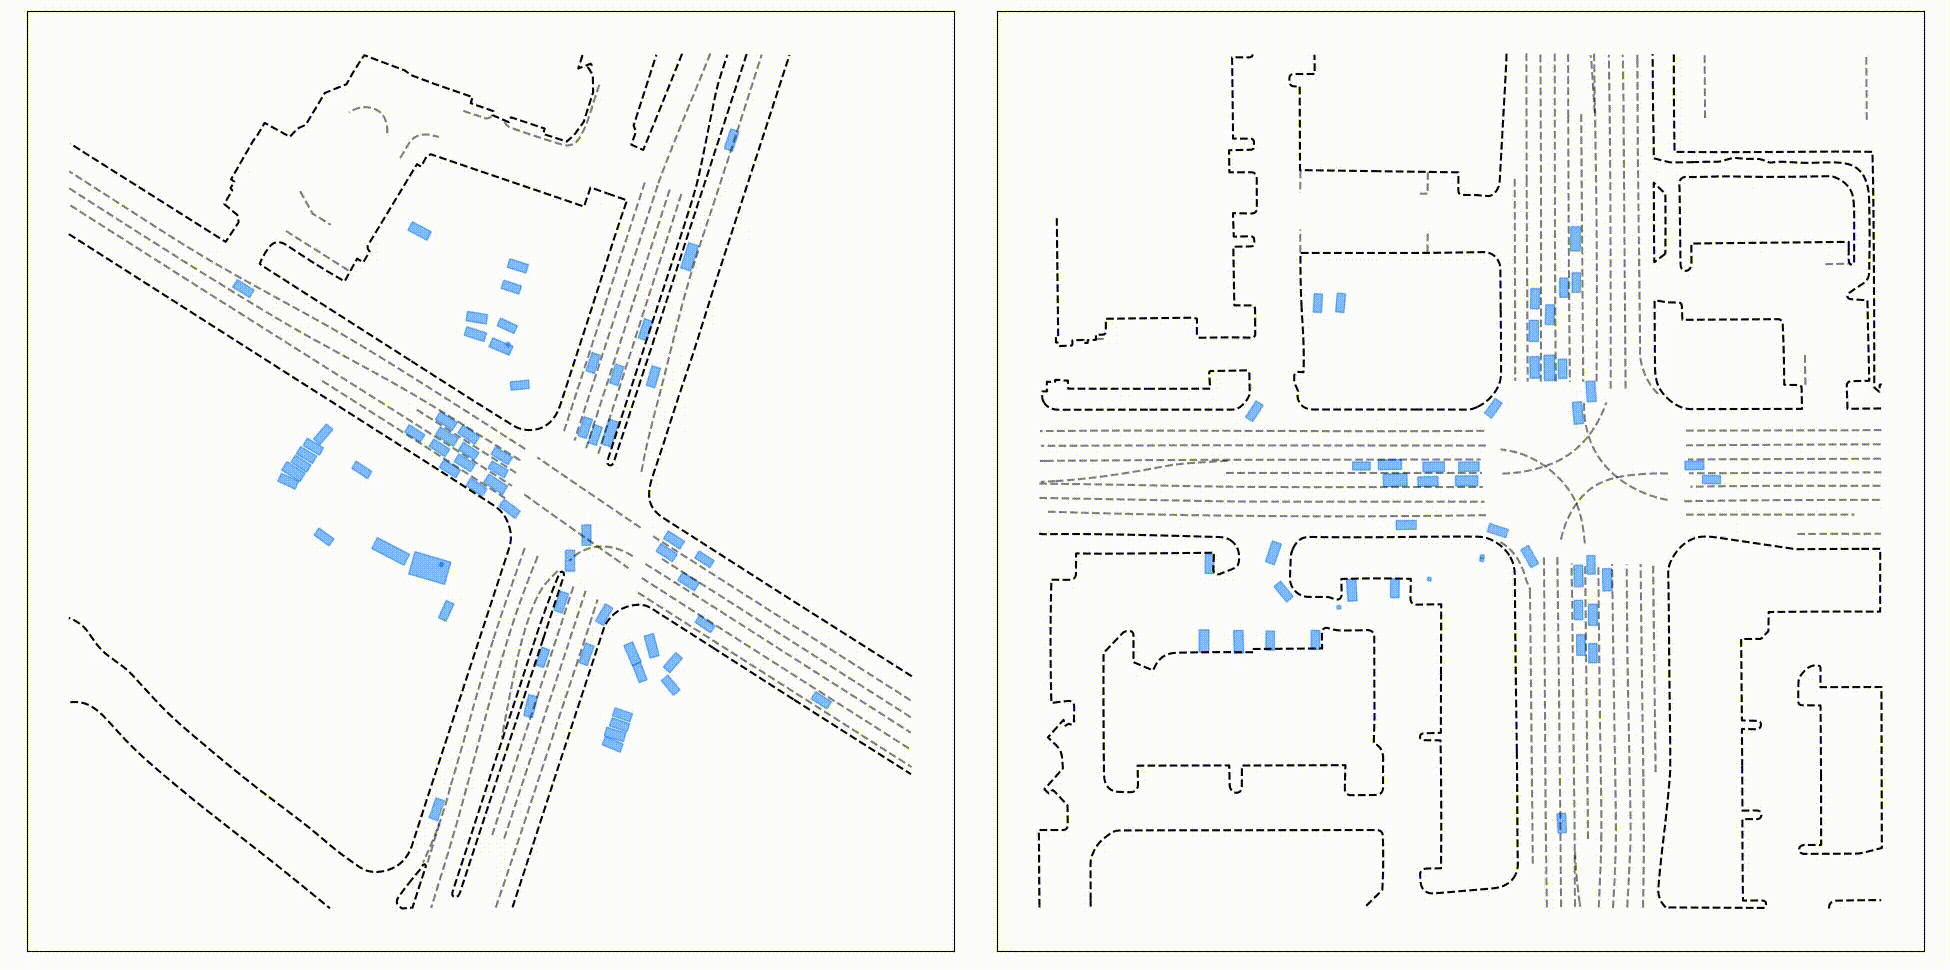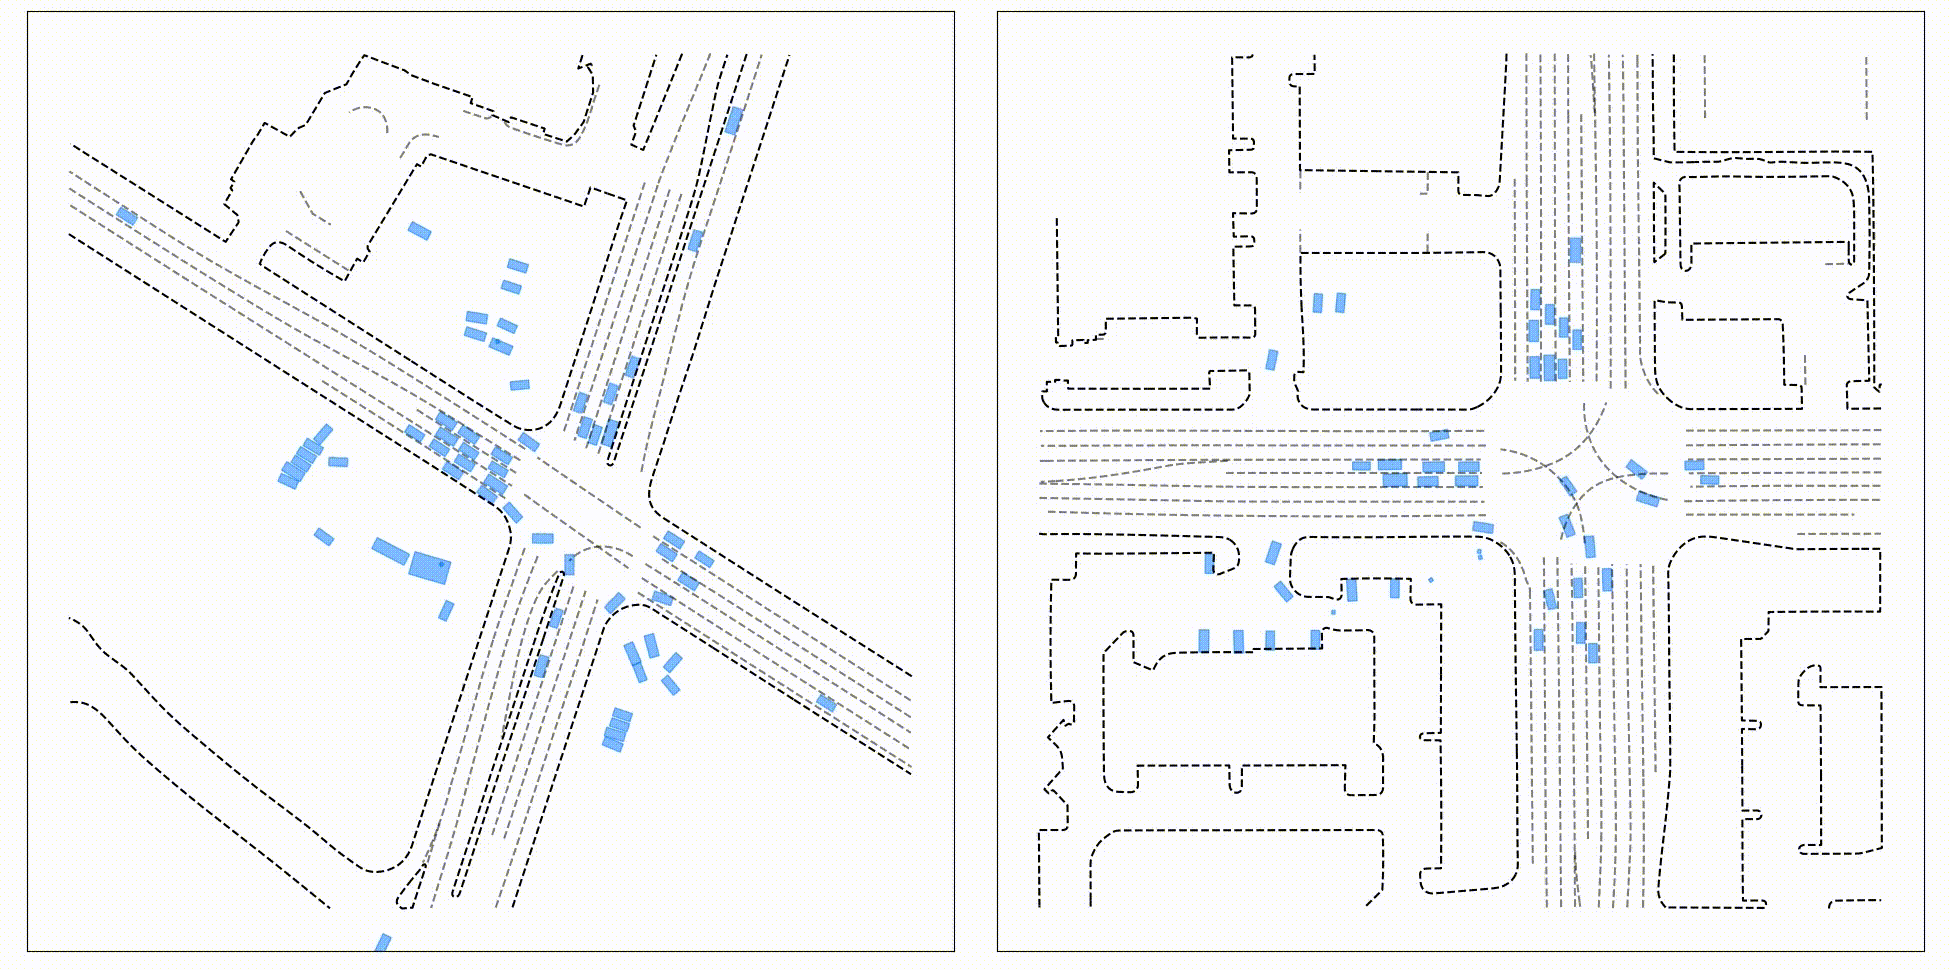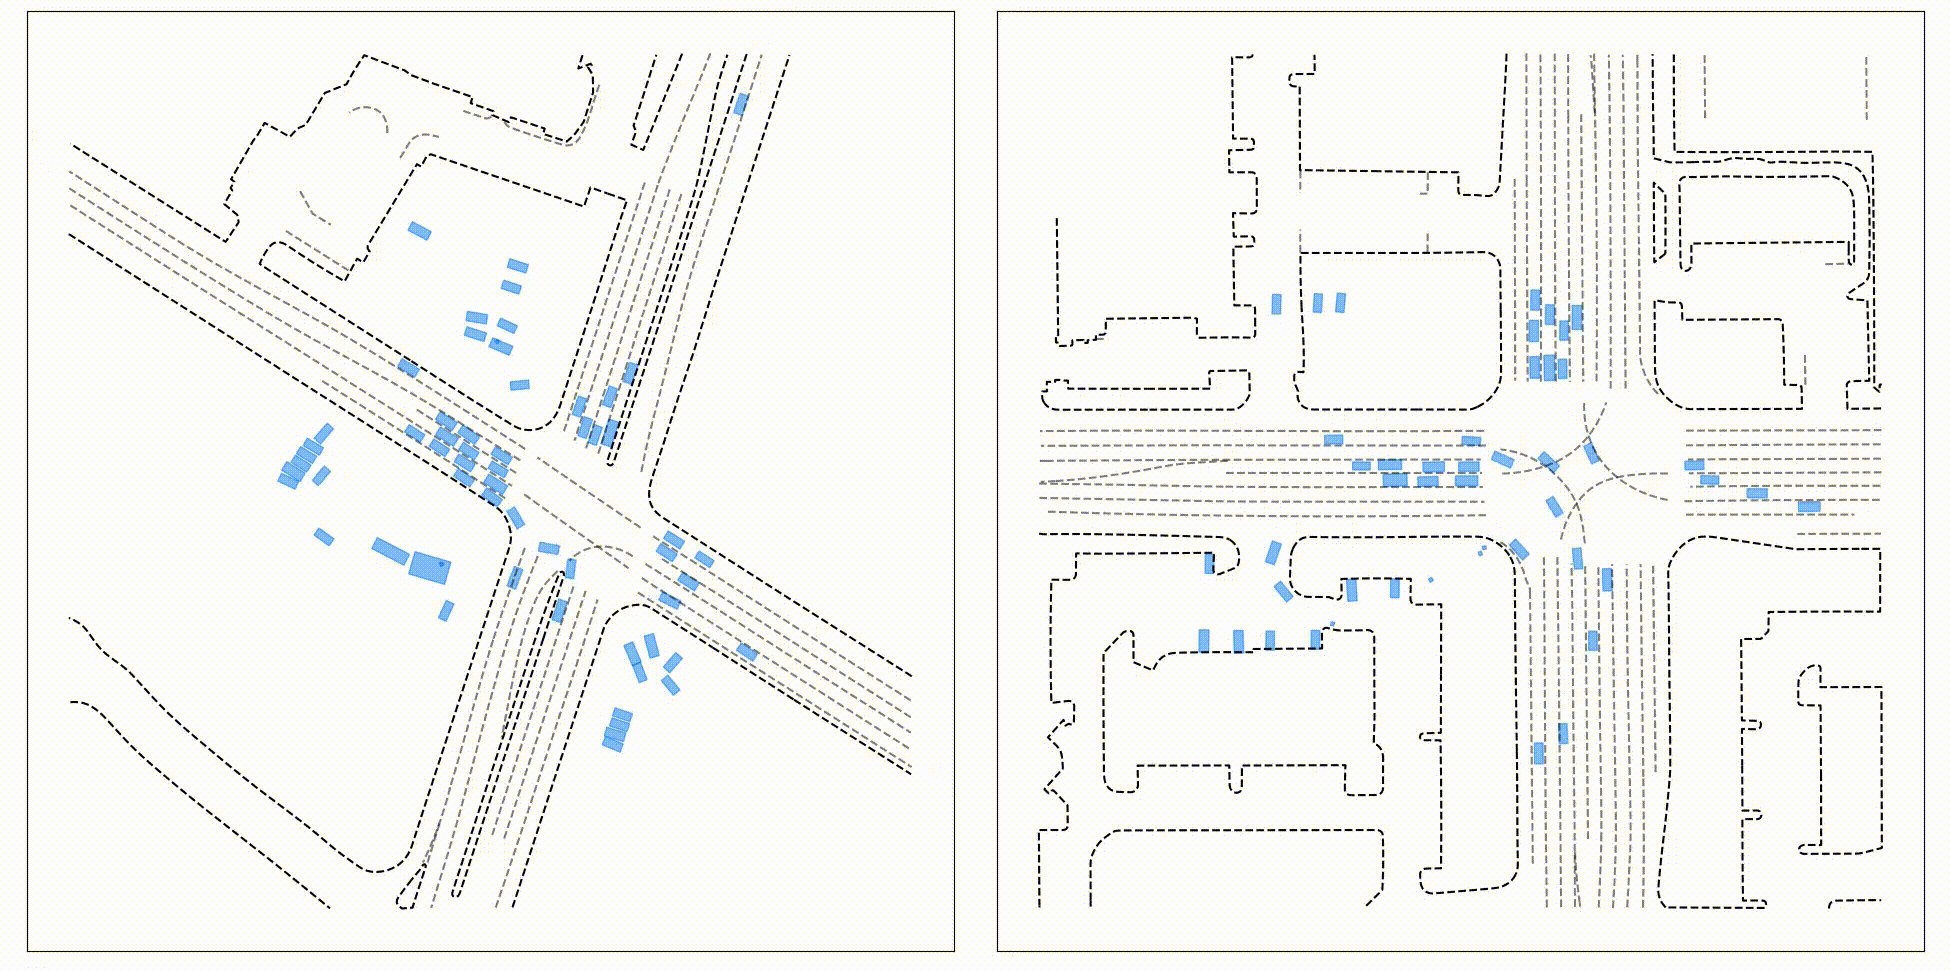
UniMM: A Unified Mixture Model Framework for Multi-Agent Simulation
Longzhong Lin,
Xuewu Lin,
Kechun Xu,
Haojian Lu,
Lichao Huang,
Rong Xiong,
Yue Wang
IEEE Transactions on Pattern Analysis and Machine Intelligence (T-PAMI 2026)
|
|
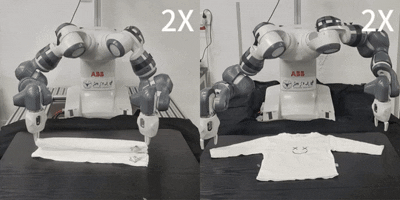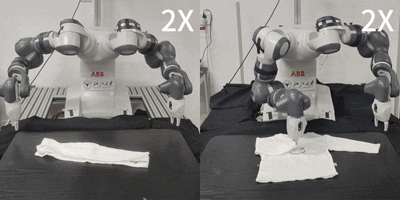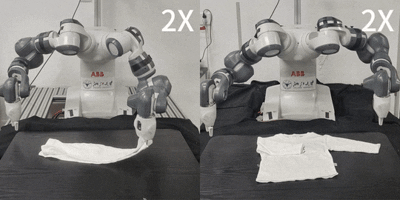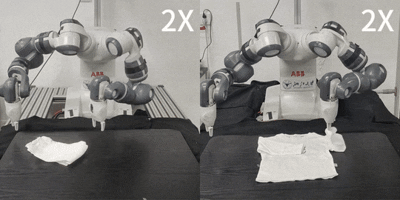
PolyFold: A Generalizable Framework for Language-Conditioned Bimanual Cloth Folding
Haozhe Du,
Kechun Xu,
Rong Xiong,
Yue Wang
IEEE Transactions on Automation Science and Engineering (T-ASE 2026)
|
|
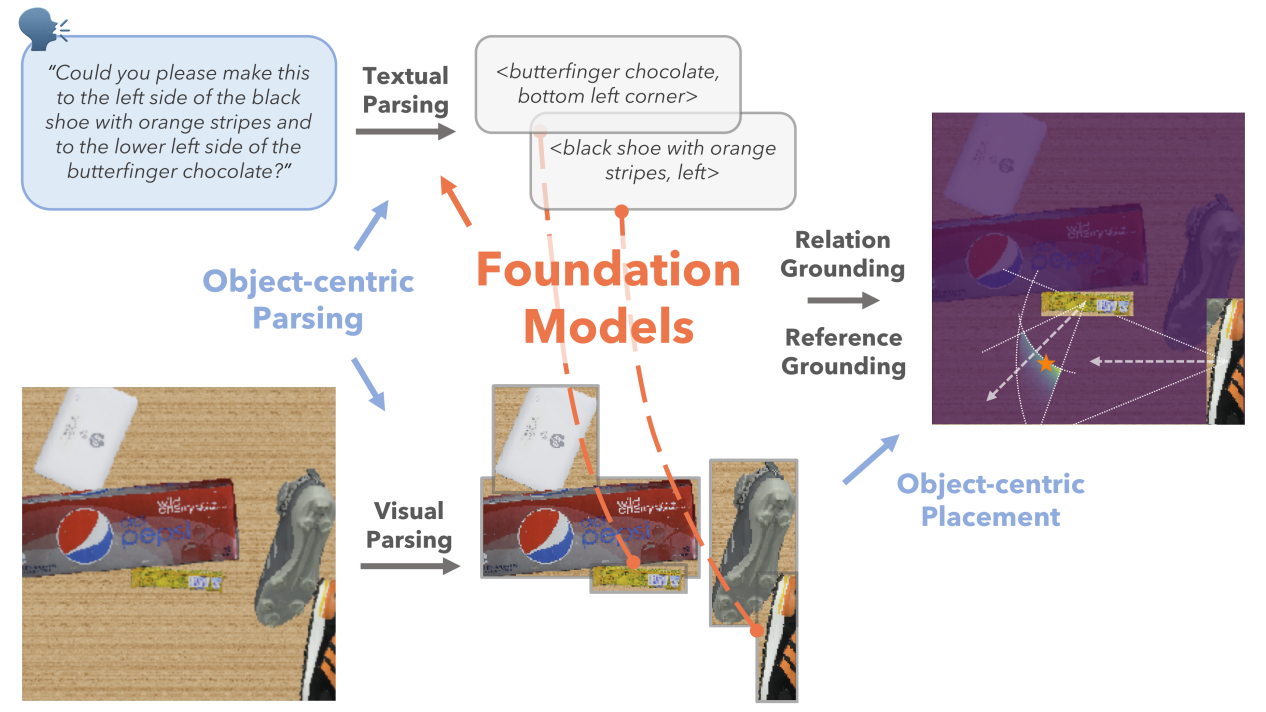
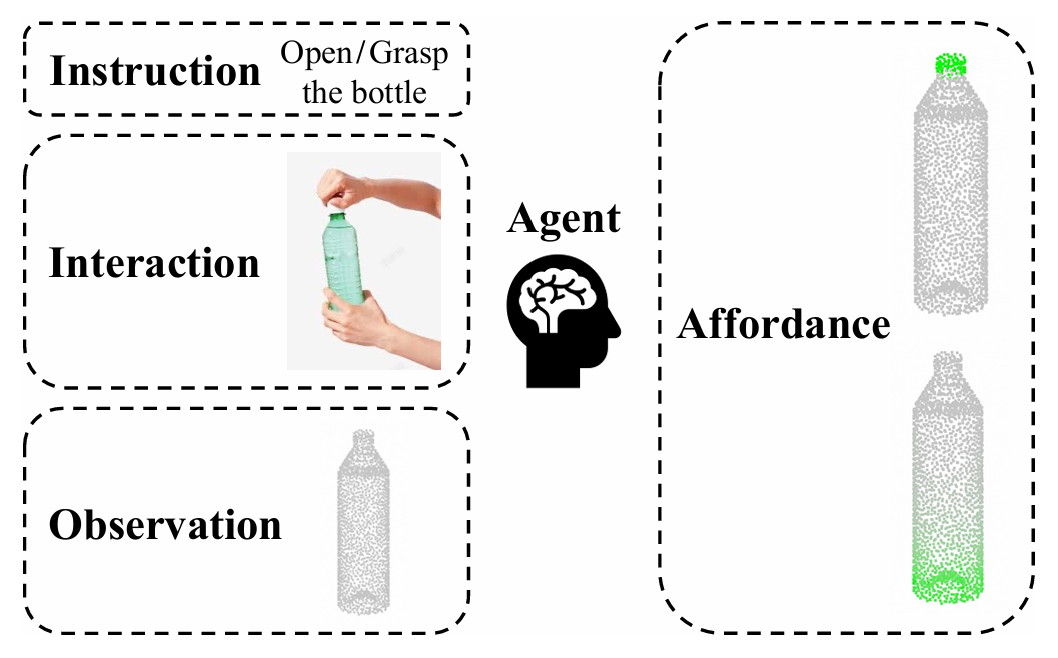
Grounding 3D Object Affordance with Language Instructions, Visual Observations and Interactions
He Zhu,
Quyu Kong,
Kechun Xu,
Xunlong Xia,
Bing Deng,
Jieping Ye,
Rong Xiong,
Yue Wang
IEEE Conference on Computer Vision and Pattern Recognition (CVPR 2025)
|

|
Grasp, See, and Place: Efficient Unknown Object Rearrangement with Policy Structure Prior
Kechun Xu,
Zhongxiang Zhou,
Jun Wu,
Haojian Lu,
Rong Xiong,
Yue Wang
IEEE Transactions on Robotics (T-RO 2024)
IEEE International Conference on Robotics and Automation (ICRA 2025)
|
- Reviewer of T-RO, T-MECH, T-ASE, RA-L, T-CDS, RSS, CoRL, ICRA, IROS, Humanoids.
- Executive Committee Member of ARTS 2025.
|
Selected Honors and Awards
|
|
|
|
|