GV

GeezerVison

The World Wide Web, restored to 800 pixels of glory.

Home|About|Gaming cabinet|Archives|How it works|Starter sites

On this site

  • Yao He (current)

This view

  • Original page
  • New address

GeezerVison is showing shockwavehe.github.io — Yao He

yaohe2025.jpg

I am currently a second-year Master’s student and an incoming CS PhD student, both at Stanford. I work on computer vision and robotics. I work with Prof. Ehsan Adeli as part of the Stanford Translation AI Lab (STAI) and Stanford Vision and Learning (SVL). I also work closely with Prof. Youngjoong Kwon. I was also a member of the Toddlerbot team, advised by Prof. Shuran Song and Prof. Karen Liu.

Previously, I served as a research associate and one of the main engineers at AirLab, CMU Robotics Institute, advised by Prof. Sebastian Scherer. During my time at CMU, I was focusing on building effecient and versatile mobile robot systems that can robustly perceive and safely navigate in unstructured environments. I was also a 2021 CMU Robotics Institute Summer Scholar.

I received my Bachelor’s degree in Electronic Information Engineering from The Chinese University of Hong Kong, Shenzhen.

Research

  1. shapeatlas.gif
    Repurposing 2D Diffusion Models for 3D Shape Completion
    Yao He, Youngjoong Kwon, Tiange Xiang, and 2 more authors
    In Submission, 2026
    Code Website
  2. livefusion.gif
    Feed-forward Monocular Human Performance Capture
    YoungJoong Kwon, Yao He, Hee Jung Choi, and 4 more authors
    In The Fourteenth International Conference on Learning Representations (ICLR), 2026
    PDF Code Website
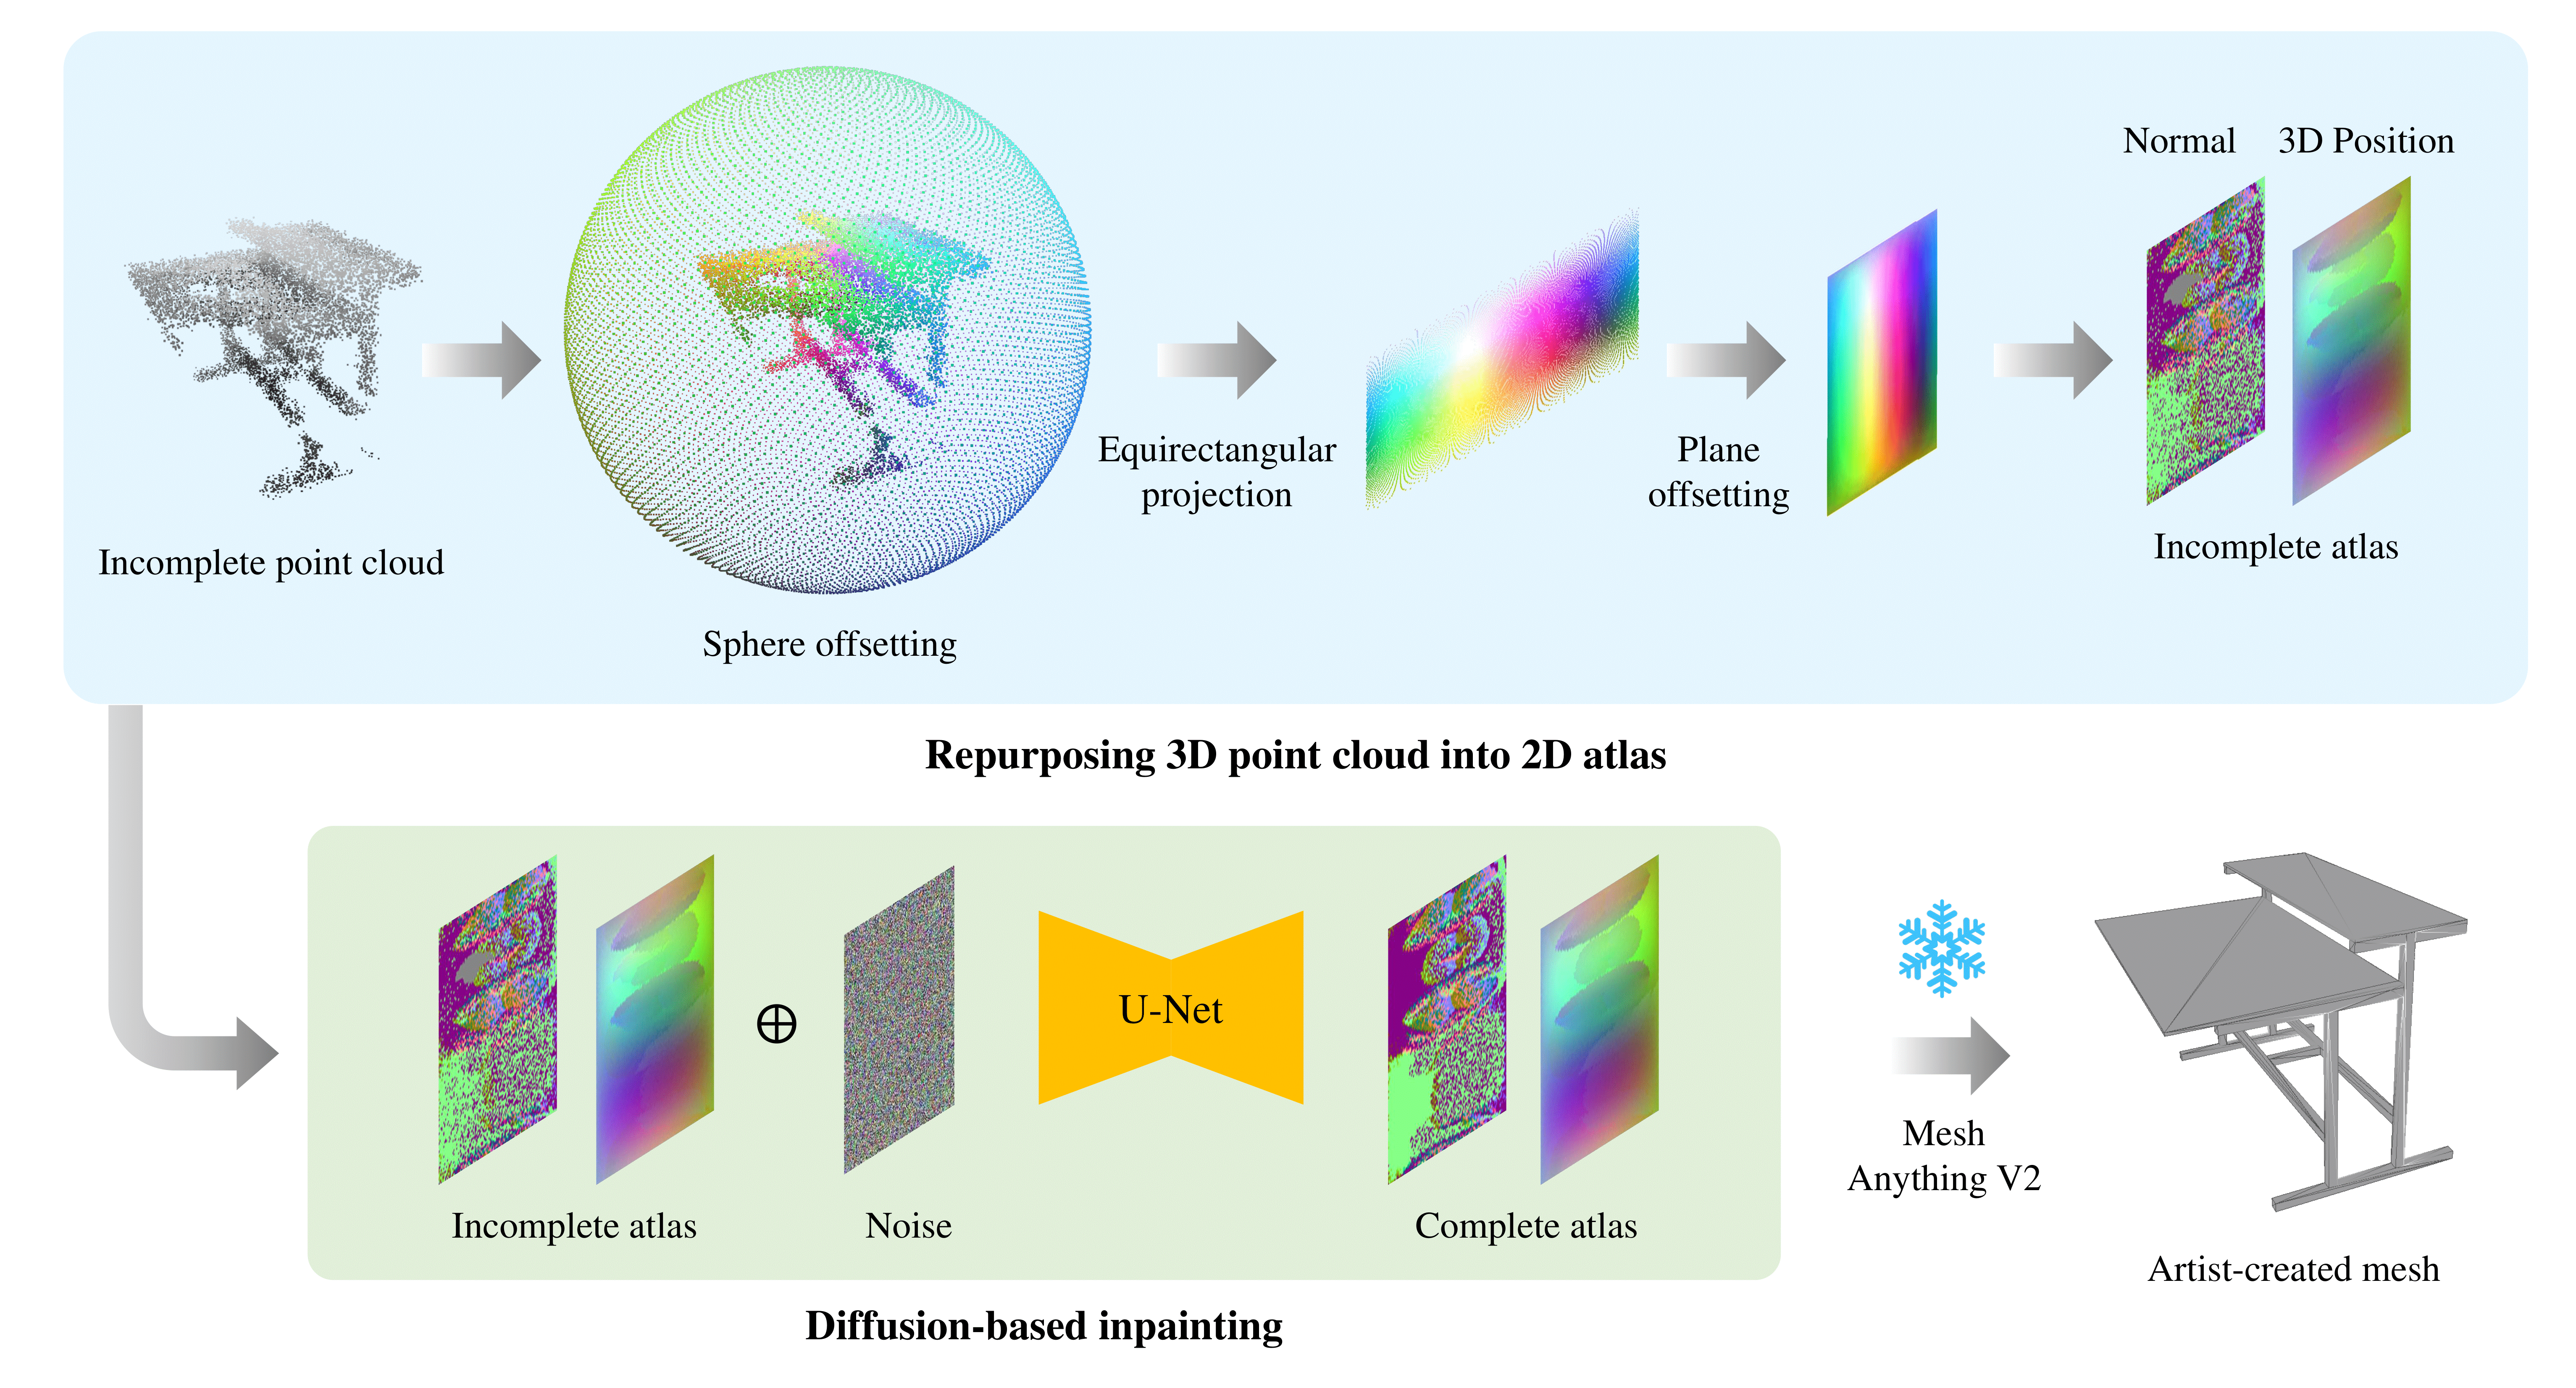
  3. mesh.png
    Artist-Created Mesh Generation from Raw Observation
    Yao He, Youngjoong Kwon, Wenxiao Cai, and 1 more author
    In International Conference on Computer Vision (ICCV) End-to-End 3D Learning workshop, 2025
    PDF
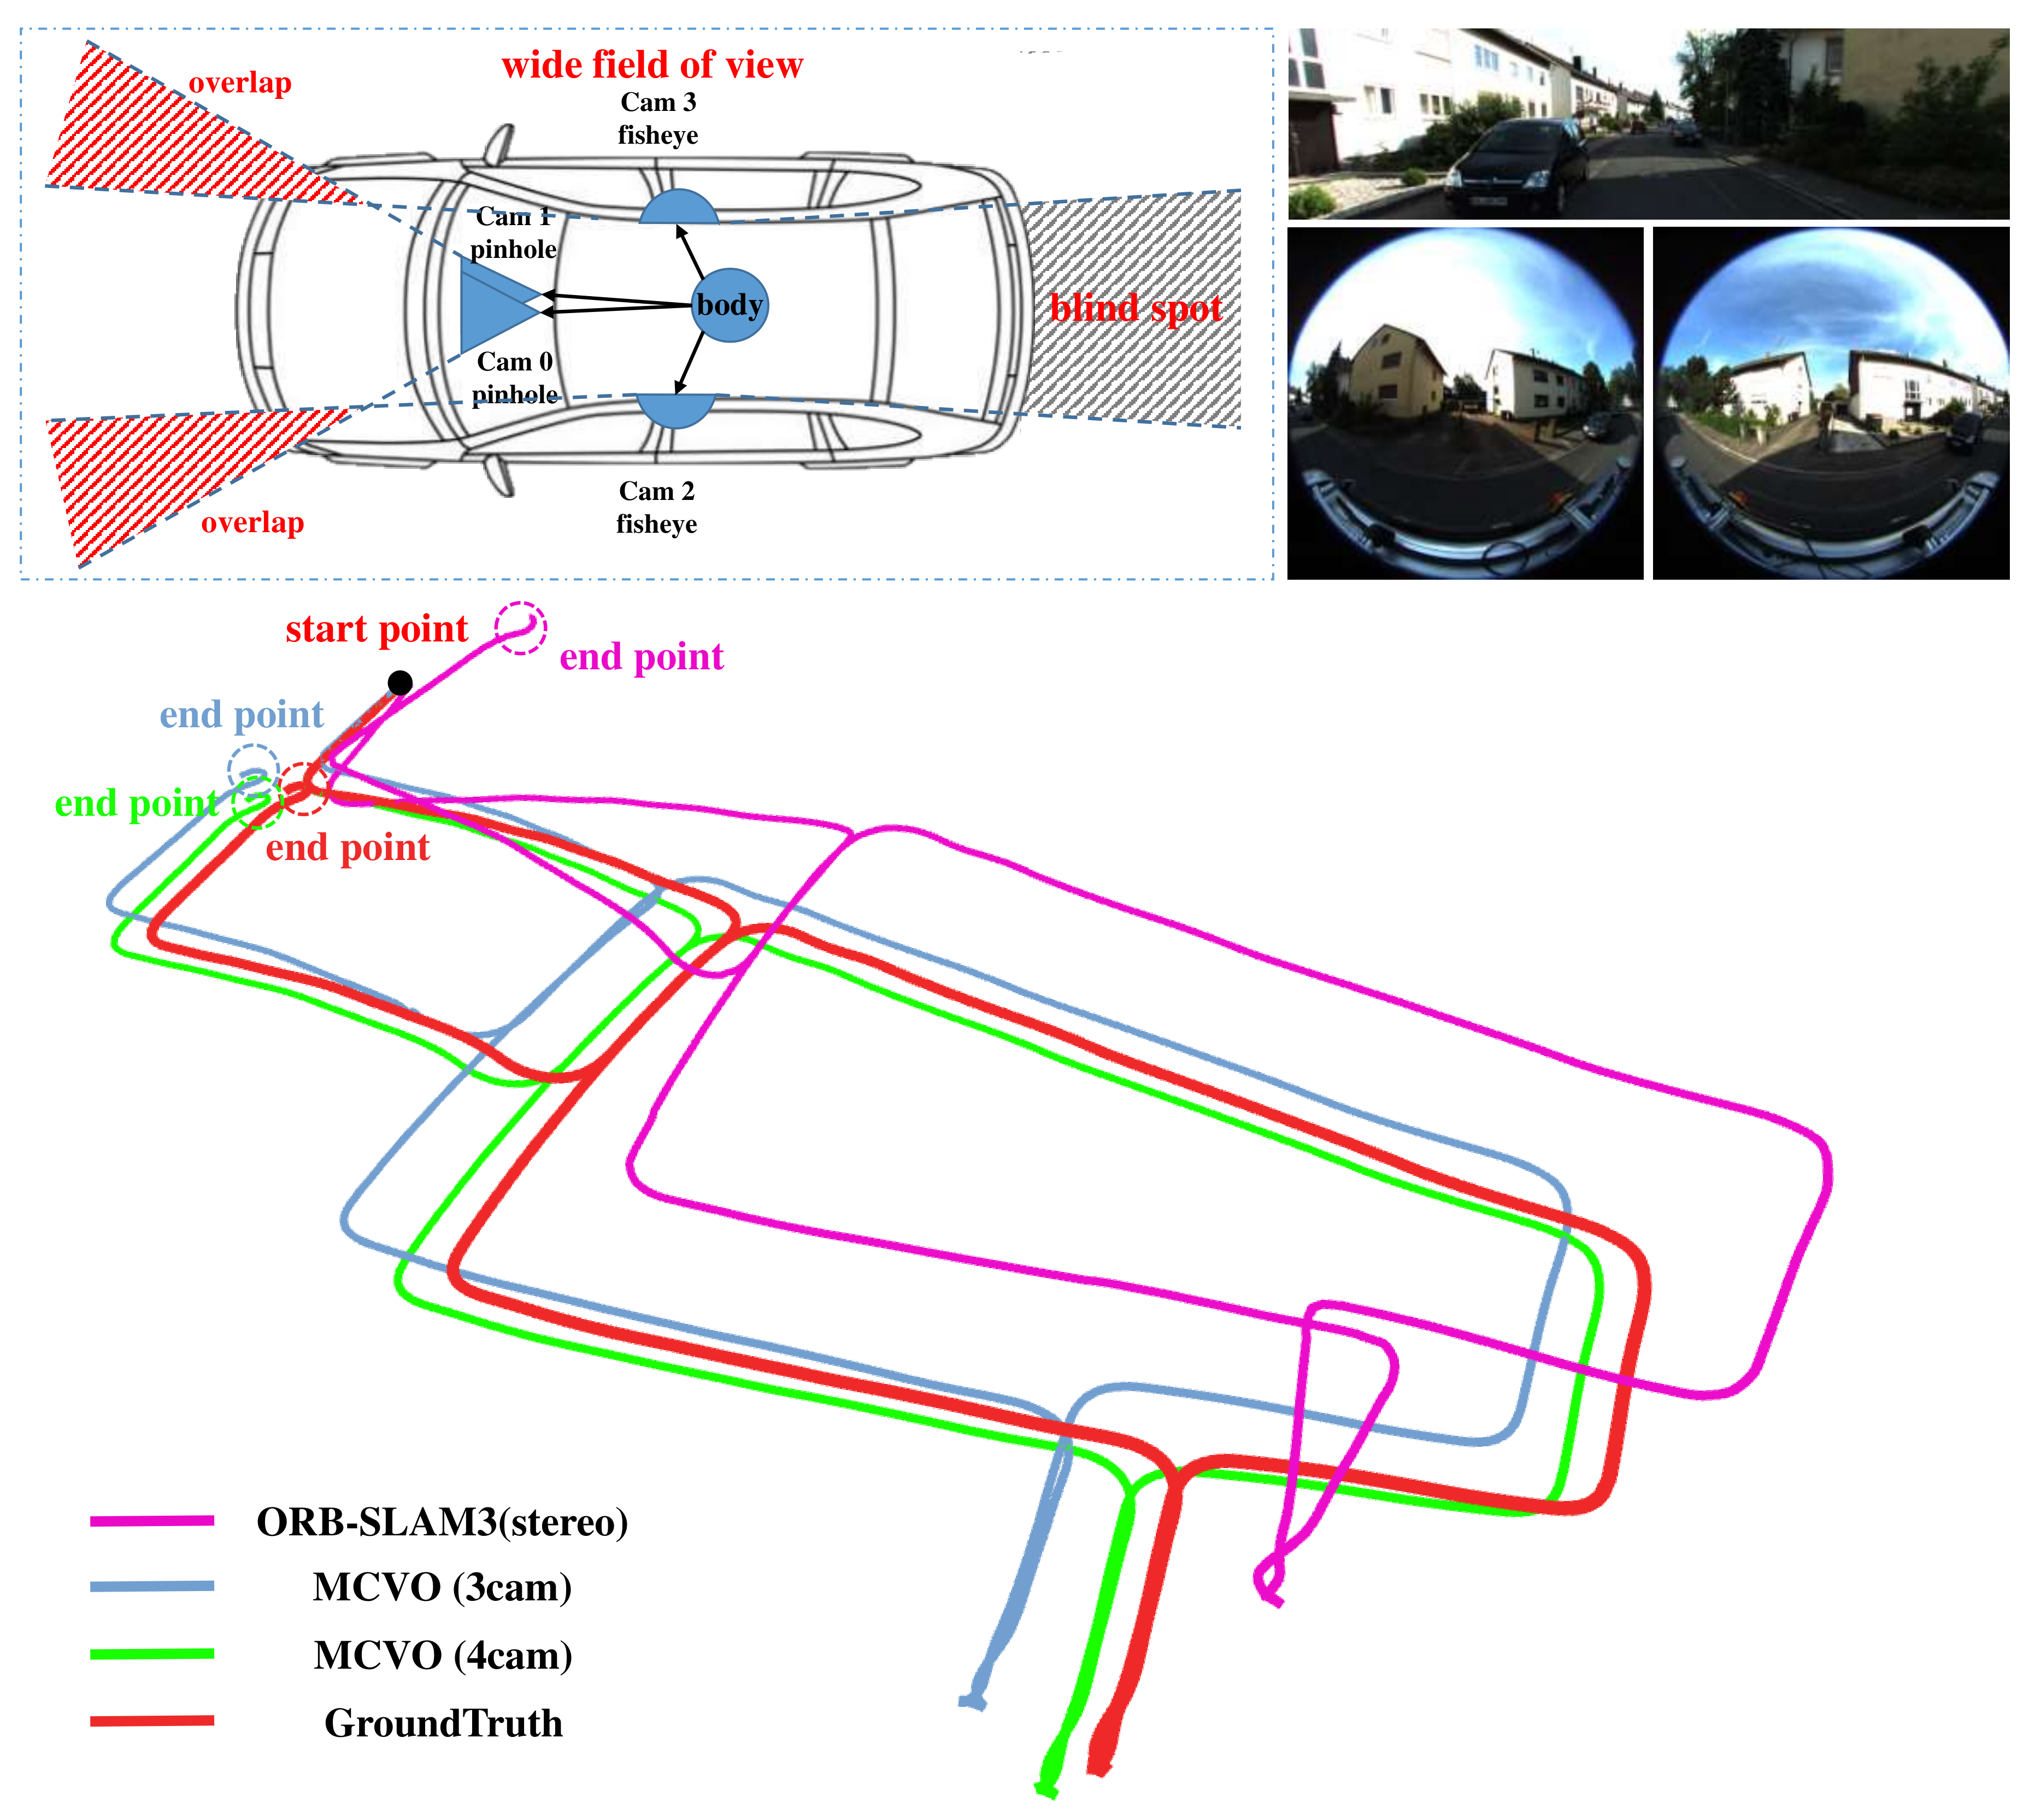
  4. mcvo-1.png
    Robust Visual Odometry using Rigidly-Bundled Arbitrarily-Arranged Multi-Cameras
    Huai Yu, Junhao Wang, Yao He, and 2 more authors
    In IEEE Robotics and Automation Letters (RA-L), 2025
    PDF Code
  5. rtr.gif
    Robot Trains Robot: Automatic Real-World Policy Adaptation and Learning for Humanoids
    Kaizhe Hu*, Haochen Shi*, Yao He, and 3 more authors
    In Conference on Robot Learning (CoRL), 2025
    PDF Code Website
  6. stem-ob.gif
    Stem-OB: Generalizable Visual Imitation Learning with Stem-Like Convergent Observation through Diffusion Inversion
    Kaizhe Hu*, Zihang Rui*, Yao He, and 3 more authors
    In The Thirteenth International Conference on Learning Representations (ICLR, Spotlight), 2025
    PDF Code Website
  7. visafe.gif
    Demonstrating ViSafe: Vision-enabled Safety for High-speed Detect and Avoid
    Parv Kapoor*, Ian Higgins*, Nikhil Keetha*, and 9 more authors
    In Robotics: Science and Systems (RSS), 2025
    PDF Website
  8. firestereo.gif
    FIReStereo: Forest InfraRed Stereo Dataset for UAS Depth Perception in Visually Degraded Environments
    Devansh Dhrafani*, Yifei Liu*, Andrew Jong, and 6 more authors
    In IEEE Robotics and Automation Letters (RA-L), 2025
    DOI PDF Code Website
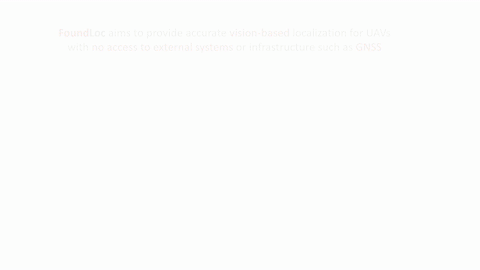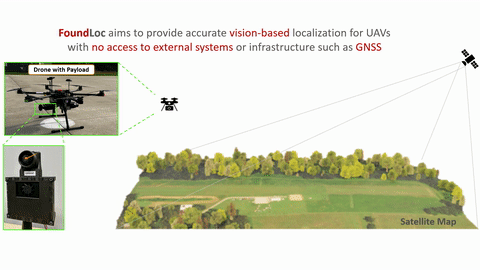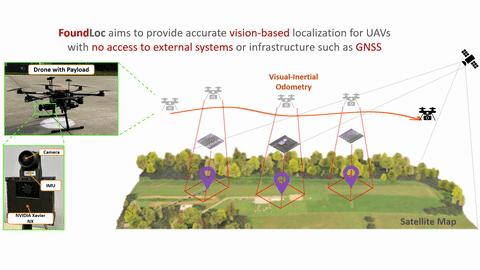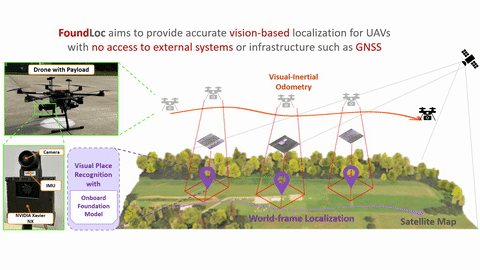
  9. FoundLoc.gif
    FoundLoc: Vision-based Onboard Aerial Localization in the Wild
    Yao He*, Ivan Cisneros*, Nikhil Keetha, and 6 more authors
    In arXiv preprint arXiv:2310.16299 , 2023
    DOI PDF Website
  10. mulcam.gif
    Towards Robust Visual-Inertial Odometry with Multiple Non-Overlapping Monocular Cameras
    Yao He, Huai Yu, Wen Yang, and 1 more author
    In 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
    PDF Video Code
  11. 2m-1.png
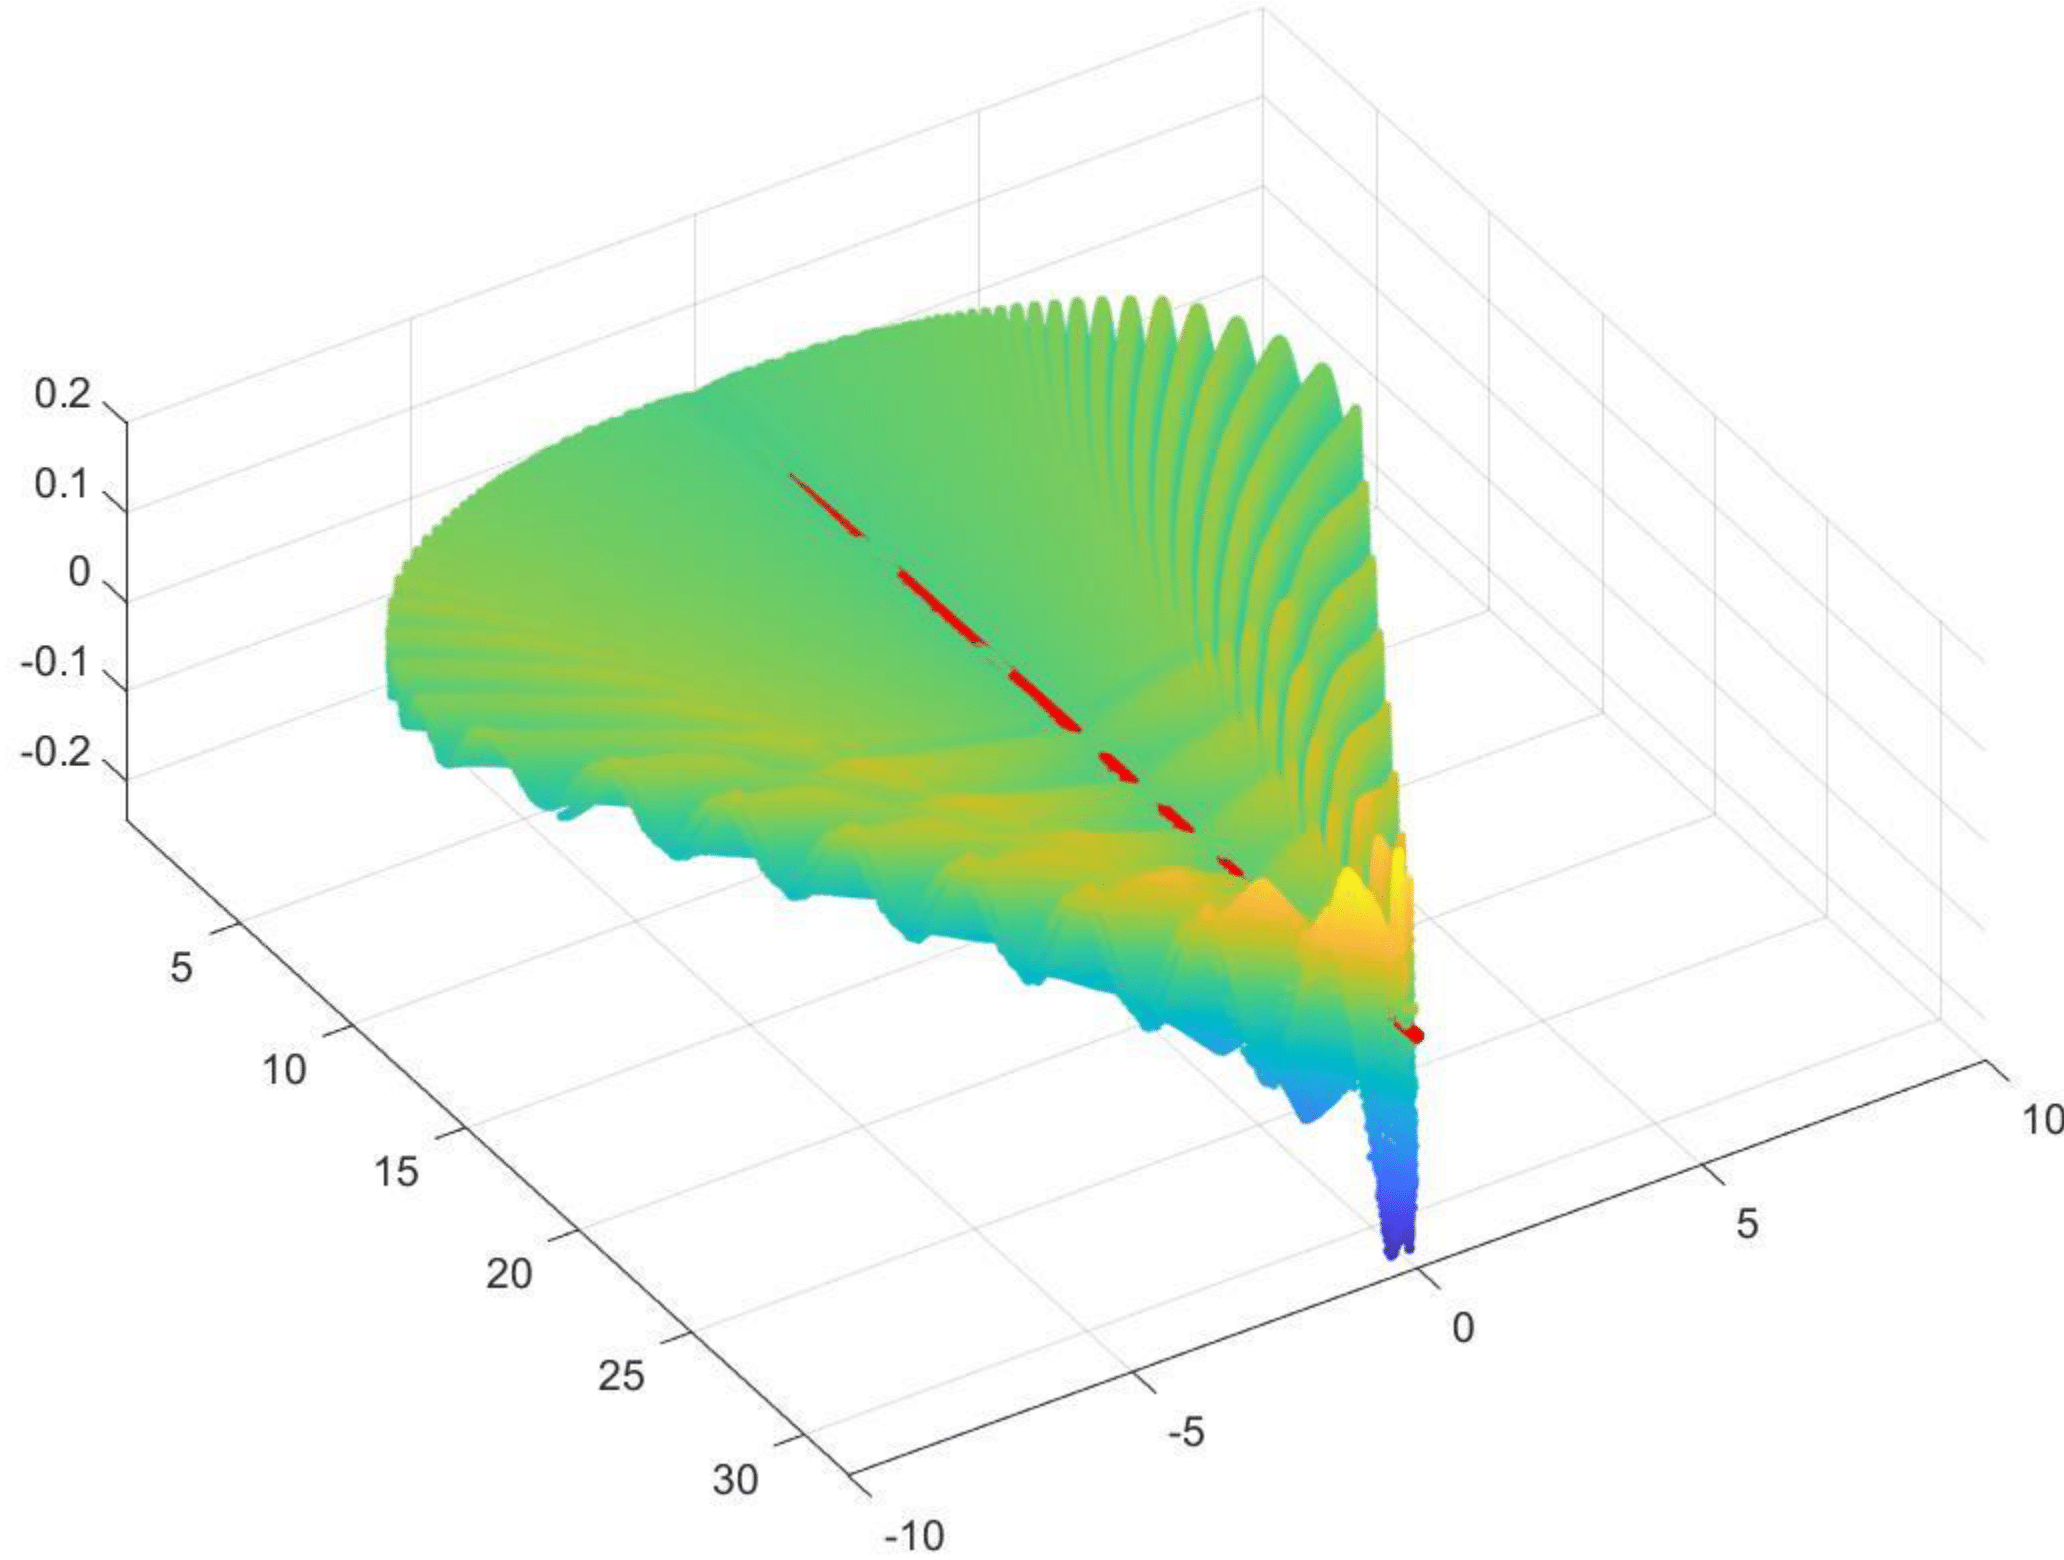
    Computational Efficient Simulation of Kelvin Wake for Unmanned Surface Vehicles
    Yao He, Qinbo Sun, Weimin Qi, and 2 more authors
    In 2021 IEEE International Conference on Real-time Computing and Robotics (RCAR), 2021
    DOI PDF Code

Teaching and Professional Service

Teaching Assistant:

  • EE/CS 227 Robot Perception (Fall 2025) - Stanford
  • MAT2002 Ordinary Differential Equations (Spring 2022) - CUHK-Shenzhen
  • CSC3002 Introduction to Computer Science: Programming Paradigms (Spring 2021) - CUHK-Shenzhen
  • MAT1002 Calculus II (Spring 2020) - CUHK-Shenzhen
  • PHY1001 Mechanics (Fall 2019) - CUHK-Shenzhen

CMU MRSD Mentor: Resilient Subcanopy UAS Navigation Through Smoke for Wildfire Application (EmberEye)

Co-organized Events:

  • Tartan Planning Series - Spring 2023 interactive series of talks, tutorials, and learning on Robot Planning
  • ICCV 2023 SLAM Challenge - Multi-Robot, Multi-Degraded SLAM Challenge with TartanAir and SubT-MRS datasets

Reviewer: IJRR, RA-L, IROS, ICRA, CVPR

Projects

Research Projects

project thumbnail

Toddlerbot 2.0

Advanced Humanoid Robot Learning Platform

project thumbnail

Shared Airspace

Safe and Seamless Operation of Crewed and Uncrewed Aircraft in Shared Airspace

project thumbnail

Wildfire UAS

Wildland Fire Safety Monitoring

project thumbnail

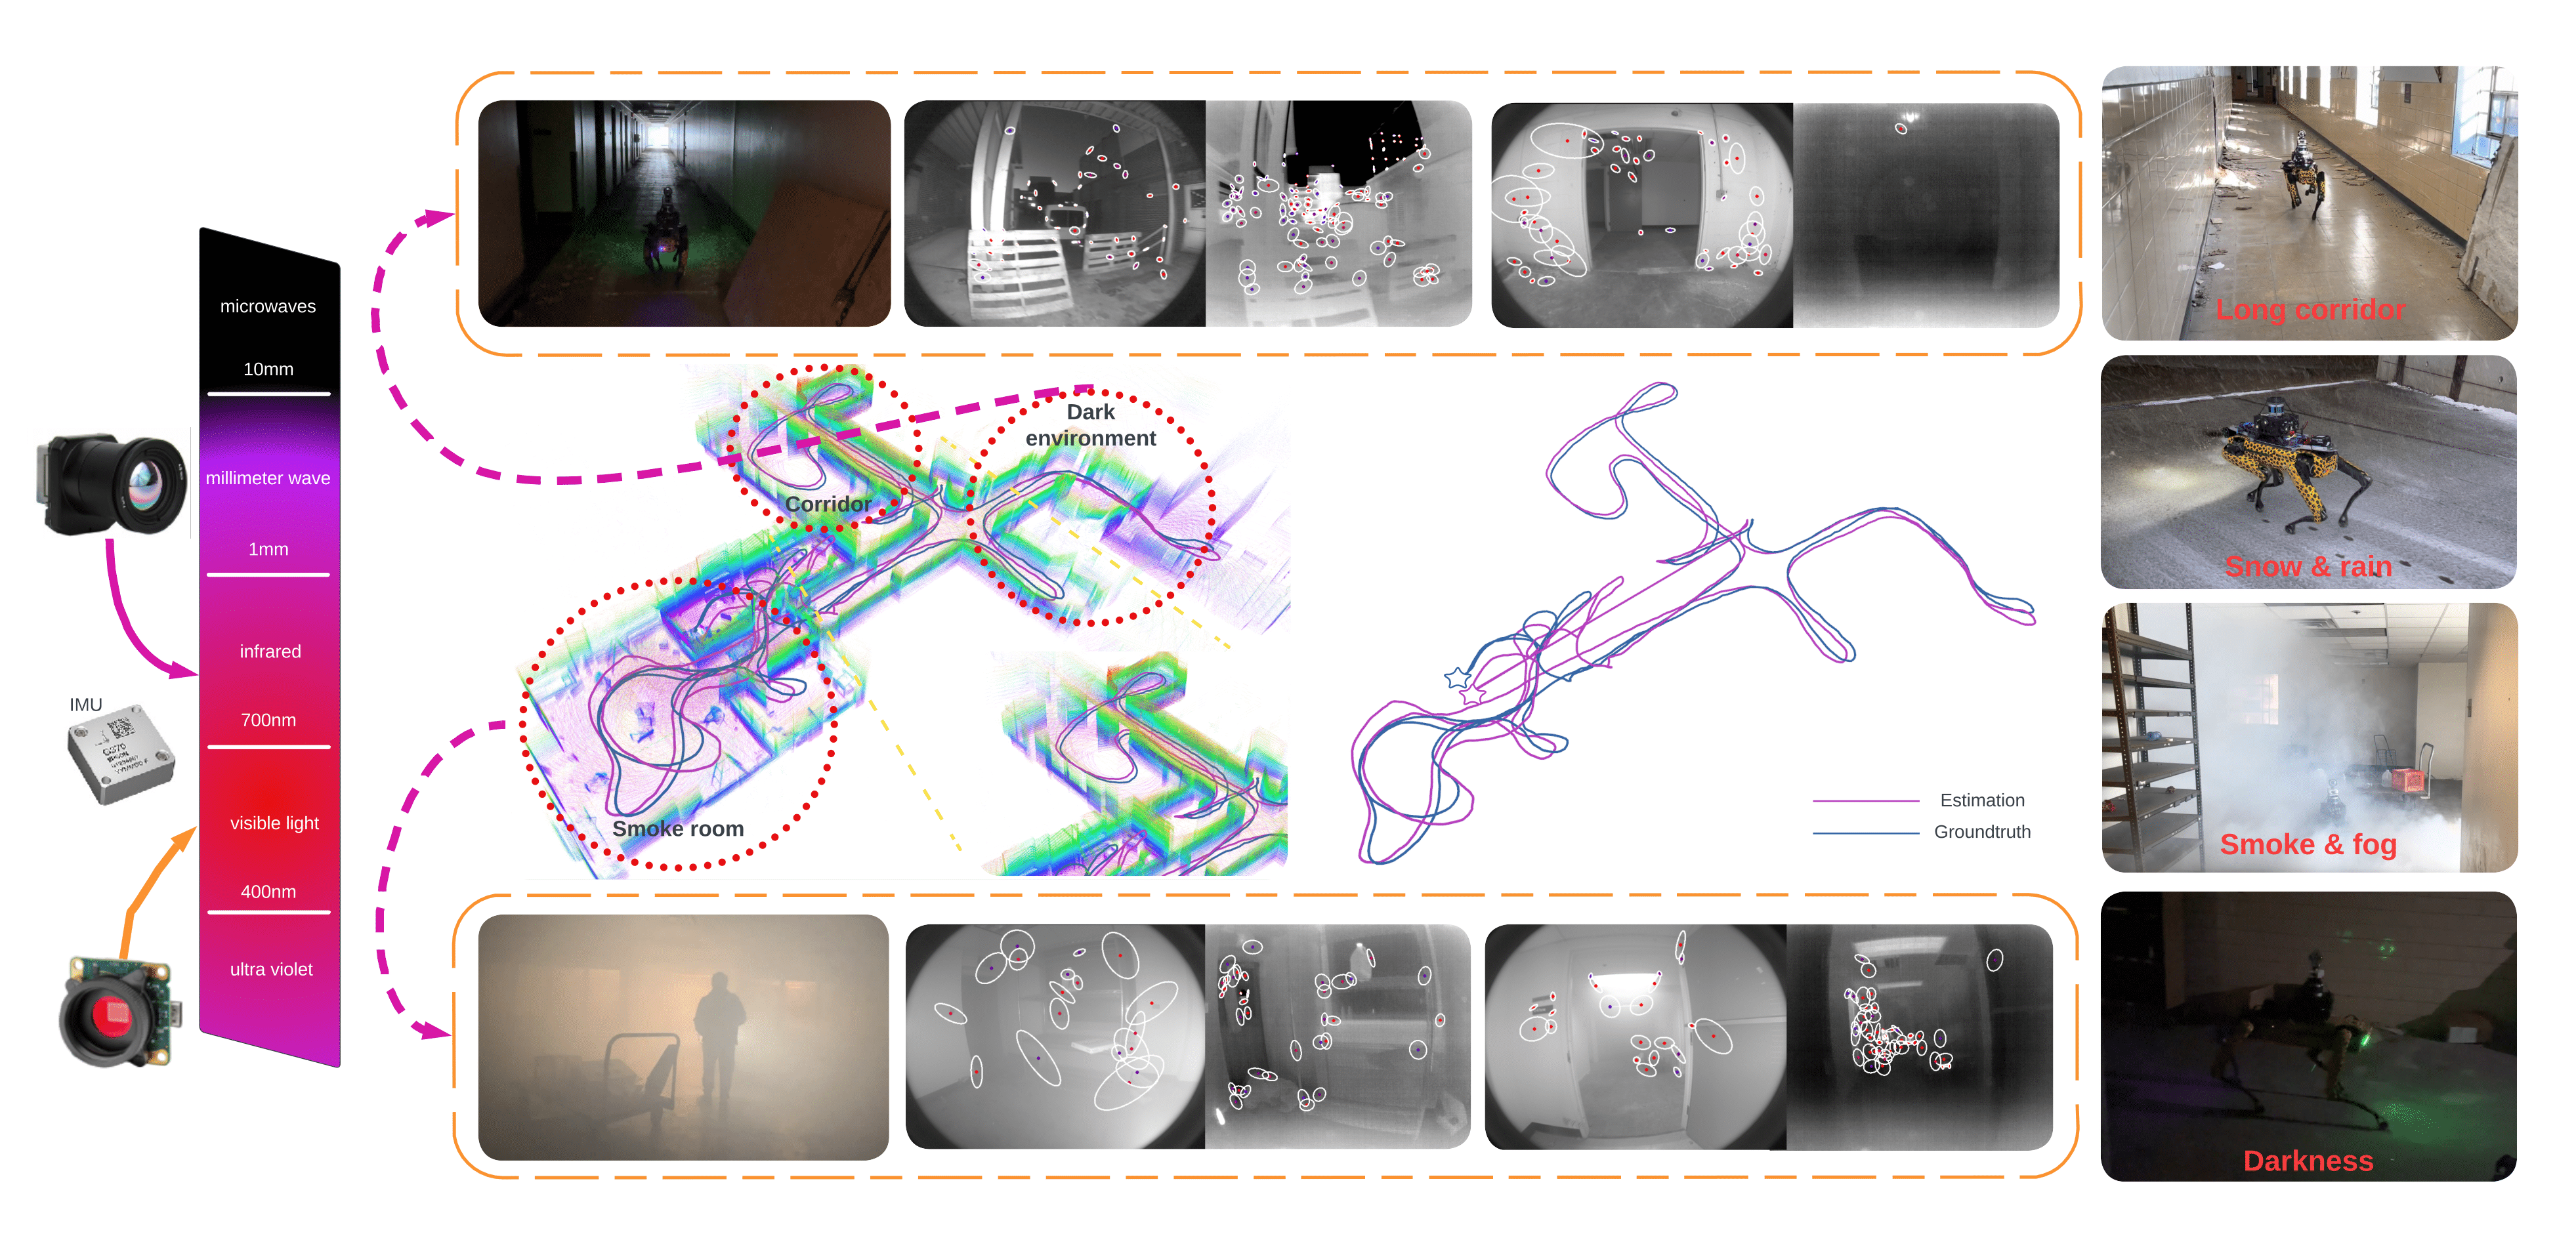
MultiSpectral Inertial Odometry

Course Projects

project thumbnail

Service Robot

Service Robot of cource ECE4310 at CUHK-Shenzhen

project thumbnail

AirSim Project

UAV-Vehicle Interaction Simulation Platform for course ERG2810 at CUHK-Shenzhen

You are visitor 01402503 — GeezerVison does not store the pages you look up.
Best viewed with Netscape Navigator 4.7 or Internet Explorer 6 at 800×600. No cookies required.